
Normative Practical Reasoning via Argumentation and Dialogue
Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence. Pages 1244-1249.
Abstract
In a normative environment an agent's actions are not only directed by its goals but also by norms. Here, potential conflicts among the agent's goals and norms makes decision-making challenging. We therefore seek to answer the following questions: (i) how should an agent act in a normative environment? and (ii) how can the agent explain why it acted in a certain way? We propose a solution in which a normative planning problem serves as the basis for a practical reasoning approach based on argumentation. The properties of the best plan(s) w.r.t. goal achievement and norm compliance are mapped to arguments that are used to explain why a plan is justified, using a dialogue game.
- [Amgoud and Cayrol, 2002] Leila Amgoud and Claudette Cayrol. A reasoning model based on the production of acceptable arguments. Annals of Mathematics Artificial Intelligence, 34(1-3):197-215, 2002.
- [Amgoud and Prade, 2009] Leila Amgoud and Henri Prade. Using arguments for making and explaining decisions. Ar- tificial Intelligence, 173(3-4):413-436, 2009.
- [Andrighetto et al., 2013] Giulia Andrighetto, Guido Gover- natori, Pablo Noriega, and Leendert van der Torre, editors. Normative Multi-Agent Systems, volume 4 of Dagstuhl Follow-Ups. Schloss Dagstuhl -Leibniz-Zentrum fuer In- formatik, 2013.
- [Atkinson and Bench-Capon, 2007] Katie Atkinson and Trevor J. M. Bench-Capon. Practical reasoning as presumptive argumentation using action based al- ternating transition systems. Artificial Intelligence, 171(10-15):855-874, 2007.
- [Broersen et al., 2001] Jan Broersen, Mehdi Dastani, Joris Hulstijn, Zisheng Huang, and Leendert van der Torre. The boid architecture: Conflicts between beliefs, obligations, intentions and desires. In Proceedings of the Fifth Interna- tional Conference on Autonomous Agents, AGENTS '01, pages 9-16, New York, NY, USA, 2001. ACM.
- [Caminada and Amgoud, 2007] Martin Caminada and Leila Amgoud. On the evaluation of argumentation formalisms. Artificial Intelligence, 171(5-6):286-310, 2007.
- [Caminada and Podlaszewski, 2012] Martin Caminada and Mikolaj Podlaszewski. Grounded semantics as persua- sion dialogue. In Bart Verheij, Stefan Szeider, and Ste- fan Woltran, editors, Computational Models of Argument -Proceedings of COMMA 2012, Vienna, Austria, Septem- ber 10-12, 2012, volume 245 of Frontiers in Artificial In- telligence and Applications, pages 478-485. IOS Press, 2012.
- [Caminada et al., 2014a] Martin Caminada, Wolfgang Dvork, and Srdjan Vesic. Preferred semantics as socratic discussion. Journal of Logic and Computation (JLC), 2014.
- [Caminada et al., 2014b] Martin Caminada, Roman Kutlak, Nir Oren, and Wamberto Weber Vasconcelos. Scrutable plan enactment via argumentation and natural language generation. In Ana L. C. Bazzan, Michael N. Huhns, Alessio Lomuscio, and Paul Scerri, editors, International conference on Autonomous Agents and Multi-Agent Sys- tems, AAMAS '14, Paris, France, May 5-9, 2014, pages 1625-1626. IFAAMAS/ACM, 2014.
- [Caminada, 2006] Martin Caminada. On the issue of rein- statement in argumentation. In Michael Fisher, Wiebe van der Hoek, Boris Konev, and Alexei Lisitsa, editors, Logics in Artificial Intelligence, 10th European Confer- ence, JELIA 2006, Liverpool, UK, September 13-15, 2006, Proceedings, volume 4160 of Lecture Notes in Computer Science, pages 111-123. Springer, 2006.
- [Dung et al., 2009] Phan Minh Dung, Robert Kowalski, and Francesca Toni. Assumption-based argumentation. In Ar- gumentation in Artificial Intelligence. Springer, 2009.
- [Dung, 1995] Phan Minh Dung. On the acceptability of ar- guments and its fundamental role in nonmonotonic rea- soning, logic programming and n-person games. Artificial Intelligence, 77(2):321-358, 1995.
- [Fan and Toni, 2015] Xiuyi Fan and Francesca Toni. On computing explanations in argumentation. In Blai Bonet and Sven Koenig, editors, Proceedings of the Twenty- Ninth AAAI Conference on Artificial Intelligence, Jan- uary 25-30, 2015, Austin, Texas, USA., pages 1496-1502. AAAI Press, 2015.
- [Fikes and Nilsson, 1971] Richard E. Fikes and Nils J. Nils- son. Strips: A new approach to the application of theorem proving to problem solving. In Proceedings of the 2Nd In- ternational Joint Conference on Artificial Intelligence, IJ- CAI'71, pages 608-620, San Francisco, CA, USA, 1971. IJCAI
- [Kollingbaum and Norman, 2003] Martin J. Kollingbaum and Timothy J. Norman. Noa -A normative agent architec- ture. In Georg Gottlob and Toby Walsh, editors, IJCAI-03, Proceedings of the Eighteenth International Joint Confer- ence on Artificial Intelligence, Acapulco, Mexico, August 9-15, 2003, pages 1465-1466. IJCAI
- Morgan Kaufmann, 2003.
- [Oren, 2013] Nir Oren. Argument schemes for normative practical reasoning. In Elizabeth Black, Sanjay Mod- gil, and Nir Oren, editors, TAFA, volume 8306 of Lecture Notes in Computer Science, pages 63-78. Springer, 2013.
- [Prakken, 2006] Henry Prakken. Combining sceptical epis- temic reasoning with credulous practical reasoning. In
- Paul E. Dunne and Trevor J. M. Bench-Capon, edi- tors, Computational Models of Argument: Proceedings of COMMA 2006, September 11-12, 2006, Liverpool, UK, volume 144 of Frontiers in Artificial Intelligence and Ap- plications, pages 311-322. IOS Press, 2006.
- [Prakken, 2012] Henry Prakken. Some reflections on two current trends in formal argumentation. In Alexander Ar- tikis, Robert Craven, Nihan Kesim Cicekli, Babak Sadighi, and Kostas Stathis, editors, Logic Programs, Norms and Action -Essays in Honor of Marek J. Sergot on the Occa- sion of His 60th Birthday, volume 7360 of Lecture Notes in Computer Science, pages 249-272. Springer, 2012.
- [Walton, 1996] Douglas N. Walton. Argumentation Schemes for Presumptive Reasoning. L. Erlbaum Associates, 1996.
- [Zhong et al., 2014] Qiaoting Zhong, Xiuyi Fan, Francesca Toni, and Xudong Luo. Explaining best decisions via ar- gumentation. In Andreas Herzig and Emiliano Lorini, ed- itors, Proceedings of the European Conference on Social Intelligence (ECSI-2014), Barcelona, Spain, November 3- 5, 2014., volume 1283 of CEUR Workshop Proceedings, pages 224-237. CEUR-WS.org, 2014.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Agents in normative systems must be able to reason about actions in pursuit of their goals, but must also consider the regulative norms imposed on them. Such norms define obligations and prohibitions on their behavior, and to avoid punishment, agents must comply with norms while pursuing their goals. However, if norm compliance hinders a more important goal or norm, an agent should consider violating it. To decide how to act, an agent thus needs to generate all plans and weigh up the importance of goal achievement and norm compliance against the cost of goal failure and norm violation in different plans. Although some reasoning frameworks do this [Broersen et al., 2001; Kollingbaum and Norman, 2003], little attention has been paid to explaining the agents' decision making in such frameworks. Such explanation is important in contexts including human-agent teams and agent debugging, and to provide explanation, we propose utilising formal argumentation.
Argumentation has been applied to inconsistency handling and decision-making [Dung, 1995; Amgoud and Prade, 2009], and its dialogical interpretation makes it an appropriate tool to generate explanations for decisions [Fan and Toni, 2015; Caminada et al., 2014b]. Although argumentation has been extensively used in practical reasoning (e.g., [Atkinson and Bench-Capon, 2007]), integrating the reasoning and dialogical aspect of argumentation for decision-making and its explanation has not been addressed by existing approaches.
In this paper we propose an argumentation-based approach to normative practical reasoning using a dialogue game to provide an intuitive overview of agent's reasoning. In achieving this aim, the following contributions are made: (i) we formalise a set of argument schemes and critical questions [Walton, 1996] aimed at checking plan justifiability with respect to goal satisfaction and norm compliance/violation; (ii) we offer a novel decision criterion that identifies the best plan(s) both in the presence and absence of preferences over goals and norms; and (iii) we investigate the properties of the best plan(s). These properties, together with Caminada's Socratic dialogu game [Caminada et al., 2014a], are used to generate an explanation for the justifiability of the best plan(s).
2 Model
This section introduces a model for normative practical reasoning based on STRIPS planning [Fikes and Nilsson, 1971].
Definition 1 (Normative Planning Problem). A normative planning problem is a tuple P = hFL↪ ∆↪A↪G↪Ni where FL is a set of fluents; ∆ ✓ FL is the initial state; A is a finite, non-empty set of durative actions; G is the set of agent goals; and N is a set of action-based norms imposed on the agent.
Fluents FL is a set of domain fluents. A literal l is a fluent or its negation. For a set of literals L, we define L+ = ¶fl s.t. fl 2 L♦ and L- = ¶fl s.t. ≻fl 2 L♦. L is welldefined if L+ \ L- = ;. For a state s ✓ FL, s+ are fluents considered true, and s- = FL∩s+. A state s satisfies literal fl, denoted as s ♣= fl, if fl 2 s, and satisfies literal ≻fl, denoted s ♣= ≻fl, if fl 62 s.
Actions An action a = hpr↪ ps↪ di is composed of welldefined sets of literals pr, ps that represent a's pre- and postconditions respectively, and a number d 2 N representing the action's duration. Given an action a = hpr↪ ps↪ di, we write pr(a), ps(a) and d(a) for pr, ps, and d. Postconditions are divided into add (ps(a)+) and delete (ps(a)-) postcondition sets. An action a can be executed in state s iff the state satisfies its preconditions. The postconditions of a durative action are applied in the state s at which the action ends, by adding the positive postconditions belonging to ps(a)+ and deleting the negative postconditions belonging to ps(a)-.
Goals Achievement goals instantaneously achieve a certain state of affairs. Each g 2 G is a well-defined set of literals g = ¶r1↪ ▷ ▷ ▷ ↪ rn♦, known as goal requirements (denoted as ri), that should be satisfied in the state to satisfy the goal.
Norms An action-based norm is defined as a tuple n = hd o↪ acon↪ asub↪ dli, where d o 2 ¶o↪ f♦ is the deontic operator denoting obligation or prohibition; acon 2 A is the action that activates the norm; asub 2 A is the action that is the subject of the obligation or prohibition; and dl 2 N is the norm deadline relative to the completion of the execution of the action acon, the activation condition of the norm.
2.1 Semantics
Let P = hFL↪ ∆↪ A↪ G↪ Ni be a normative planning problem. Also let ⇡ = h(a0↪ 0)↪ ▷ ▷ ▷ ↪ (an↪ tan )i be a sequence of actions such that @(ai↪ tai )↪ (aj↪ taj ) 2 ⇡ s.t. tai taj < tai + d(ai)↪ (ai↪ aj) 2 cf action, where cf action is defined below.
Definition 2 (Conflicting Actions). Actions ai and aj have a concurrency conflict iff the preconditions or postconditions of ai contradict the preconditions or postconditions of aj.
The duration of a sequence of actions ⇡ is calculated as Makespan(⇡) = max (tai +d(ai)). The execution of ⇡ from a starting state s0 brings about a sequence of states S(⇡) = hs0↪ ▷ ▷ ▷ ↪ smi for every discrete time interval from 0 to m = Makespan(⇡). The transition relation between two states is as follows. Let Ak be the set of action, time pairs such that the actions end at state sk. State sk results from removing all delete postconditions and adding all add postconditions of actions in Ak to state sk-1. I.e., 8 0 < k m :
⇡ satisfies a goal if there is a state that satisfies the goal: ⇡ ♣= g iff 9 sk 2 S(⇡) s.t. sk ♣= g. The set of satisfied goals by ⇡ is denoted G⇡.
⇡ complies with an obligation if the action that is the subject of the obligation, asub, occurs during the compliance period (i.e., between when the condition holds and when the deadline expires):
If asub does not occur during the compliance period, the obligation is violated: ⇡ 6♣= n.
⇡ complies with a prohibition if the prohibition's subject action asub does not occur during the compliance period:
If asub occurs during the compliance period, the prohibition is violated: ⇡ 6♣= n.
We assume that all norm deadlines end before Makespan(⇡). Therefore, all activated norms in ⇡ (denoted as N⇡) are either complied with (denoted Ncmp(⇡)) or violated (denoted Nvol(⇡)) by time m. Another assumption made is deontic detachment [Andrighetto et al., 2013], meaning that norm instances are unique, even if a norm is invoked several times.
2.2 Conflict
In this section we consider several types of conflict, defining which sequences of action within a plan are determined to be in conflict. We consider a running example where an agent has the goals of going on strike; submitting a report; and getting a certificate of some sort. However, if the agent goes on maternity leave, it cannot go to the office and submit the report. Moreover, if it goes on strike, it cannot go to office or attend meetings.
Definition 3 (Conflicting Goals). Goal gi and gj are in conflict if satisfying them requires bringing about conflicting state of affairs.
Example 1. The goal strike, made up of fluents ¶union member↪ ≻at office↪ ≻meeting attended♦ and goal submission, with fluents ¶at office↪ report finalised♦ are in conflict.
Definition 4 (Conflicting Obligations and Goals). Norm n = ho↪ acon↪ asub↪ dli and goal g are in conflict if executing action asub - the subject of the obligation - brings about postconditions that are in conflict with the requirements of g.
Example 2. Goal strike and norm n1 = ho↪ get company funding↪ attend meeting↪ 2i, obliging meeting attendance if company funding is used are in conflict, since postcondition meeting attended of attend meeting is incompatible with the fluents of strike.
Definition 5 (Conflicting Prohibitions and Goals). A prohibition norm n = hf↪ acon↪ asub↪ dli and a goal g are in conflict, if the postconditions of asub contribute to satisfying g via r (and r cannot be brought about by any other action.), but executing action asub is prohibited by norm n.
Example 3. submission = ¶at office↪ report finalised♦ and n2 = hf↪ take maternity leave↪ go to office↪ 6i are in conflict since taking maternity leave prevents the agent from going to the office and hence prevents fulfilling the goal of submission: (submission↪ n2) 2 cf goalpro.
The entire set of conflicting goals and norms is defined as: cf goalnorm = cf goalobl [ cf goalpro.
Definition 6 (Conflicting Obligations). n1 = ho↪ acon↪ asub↪ dli and n2 = ho↪ bcon↪ bsub↪ dl0 i are in conflict in the context of ⇡ if the obliged actions in n1, i.e., asub, and n2, i.e., bsub have a concurrency conflict; and action asub is in progress during the entire period over which the agent is obliged to execute action bsub.
Example 4. Due to the concurrency conflict between actions attend meeting and attend interview, in n1 = ho↪ get company funding↪ attend meeting↪ 2i and n4 = ho↪ take theory test↪ attend interview↪ 2i and depending on the way actions are sequenced in a plan, it is possible that in some ⇡: (n1↪ n4) 2 cf ⇡oblobl .
Definition 7 (Conflicting Obligations and Prohibitions). An obligation n1 = ho↪ acon↪ asub↪ dli and a prohibition n2 = hf↪ bcon↪ asub↪ dl0 i are in conflict in the context of ⇡ if n2 forbids the agent to execute action asub during the entire period over which obligation n1 obliges the agent to take asub.
Example 5. The obligation and prohibition n1 = ho↪ get company funding↪ attend meeting↪ 2i, and n3 = hf↪ take maternity leave↪ attend meeting↪ 6i can be in conflict in some ⇡ as they require and forbid attending a meeting. Thus, for some ⇡, (n1↪ n3) 2 cf ⇡oblpro .
The two sets cf ⇡oblobl and cf ⇡oblpro constitute the set of conflicting norms: cf ⇡norm = cf ⇡oblobl [ cf ⇡oblpro .
Definition 8 (Plan). A sequence of actions ⇡ = h(a0↪ 0)↪ ▷ ▷ ▷ ↪ (an↪ tan )i s.t. @(ai↪ tai )↪ (aj↪ taj ) 2 ⇡ s.t. tai taj < tai + d(ai)↪ (ai↪ aj) 2 cf action is a plan for the normative planning problem P = (FL↪ ∆↪ A↪ G↪ N) iff:
- ÷ Only the fluents in ∆ hold in the initial state: s0 = ∆
- ÷ the preconditions of action ai holds at time tai and throughout the execution of ai:
- ÷ the set of goals satisfied by plan ⇡ is a non-empty (G⇡ 6= ;) consistent subset of goals:
- ÷ there is no conflict between the goals satisfied and norms complied with:
Note that since norms are action-based and there is no possibility of executing conflicting actions, there will be no conflict between the norms complied with in a plan.
We consider a set of plans ⇧, and in the next section deal with the problem of choosing the best plan from this set.
3 Identifying the Best Plan
The conflict between an agent's goals and norms often makes it impossible for the agent to satisfy all its goals while complying with all norms triggered in a plan. We begin by considering how to treat each plan as a proposal of actions and how to use argumentation schemes to check the justifiability of a plan proposal with respect to conflicts and preferences. In Section 3.2, we then identify the best plan from the justified subset.
3.1 Generating Arguments
An argumentation framework (AF) consists of a set of arguments and attacks between them [Dung, 1995]: AF = hArg↪Atti↪Att ✓ Arg ⇥Arg. In scheme-based approaches [Walton, 1996] arguments are expressed in natural language and a set of critical questions is associated with each scheme, identifying how the scheme can be attacked. Below, we introduce a set of argument schemes and critical questions to reason about a plan proposal with respect to the goals it satisfies and norms it complies with or violates.
Definition 9 (Plan Argument Scheme Arg⇡). A plan argument claims that a proposed sequence of actions should be executed because it satisfies a set of goals, and complies with a set of norms while violating some other norms:
- In the initial state ∆
- The agent should execute sequence of actions ⇡
- Which will satisfy set of goals G⇡ and complies with set of norms Ncmp(⇡) and violates set of norms Nvol(⇡)
Definition 10 (Goal Argument Scheme Argg). A goal argument claims that a feasible goal should be satisfied:
- Goal g is feasible 1 for the agent
- Therefore, satisfying g is required.
The set of goal argument is denoted as ArgG.
Definition 11 (Norm Argument Scheme Argn). A norm argument claims that an activated norm should be complied with:
- n is an activated norm imposed on the agent in plan ⇡
- Therefore, complying with n is required in ⇡.
The set of norm argument for a plan is denoted as ArgN⇡ .
Critical Questions for the Plan Argument Scheme
- CQ1: Is there a goal argument which attacks Arg⇡? This CQ results in an undercut attack (asymmetric by nature) from a goal argument to a plan argument, when the goal is not satisfied in the plan:
- CQ2: Is there a norm argument which attacks Arg⇡? This CQ results in an undercut from a norm argument to a plan argument, when the norm is violated in the plan:
Critical Questions for the Goal Argument Scheme
- CQ3: What goal arguments might attack Argg? This CQ results in a rebut attack (symmetric by definition) between arguments for conflicting goals:
CQ4: What norm arguments might attack Argg? This CQ results in a rebut attack between arguments for a goal and a norm that are in conflict:
1 A goal is feasible if there is at least one plan that satisfies it.
Critical Questions for the Norm Argument Scheme
CQ4: What goal arguments might attack the norm presented by Argn? The previous critical question is associated with argument schemes for norms as well as goals, hence the repetition of the critical question.
CQ5: What norm arguments might attack the norm presented by Argn? Conflict between two norms is defined as a contextual conflict that depends upon the context of the plan in which the norms are activated.
Preferences between arguments distinguish an attack from a defeat (i.e., a successful attack [Amgoud and Cayrol, 2002]). The attack from one argument to another is a defeat if the latter argument is not preferred over the former. However, as discussed in [Prakken, 2012], rebuttal attacks are preference-dependent, whereas undercuts are preferenceindependent. Thus, attacks due to CQ3, CQ4 and CQ5 need preferences to be resolved, while attacks caused by CQ1 and CQ2 are preference-independent, always resulting in defeat.
We define ⌫gn as a partial preorder on G[N . ≻gn denotes the strict relation corresponding to ⌫gn . Also, (↵↪ β) 2 ⇠gn iff (↵↪ β) 2 ⌫gn and (β↪ ↵) 2 ⌫gn . The preferences between the goal and norm arguments result from the preference between these entities: (Arg↵↪ Argβ) 2 ⌫ iff (↵↪ β) 2 ⌫gn .
An AF for a plan proposal consists of the argument for the plan itself, a set of arguments for goals and arguments for norms that are activated in that plan. Although the set of goal arguments in AFs for plan proposals remain the same across the AFs, the set of norm arguments differs between AFs depending on the norms that are activated by the plan proposal in each AF.
Definition 12 (Plan Proposal AF). The AF for plan proposal ⇡ is AF⇡ = hArg↪ Def i, where Arg = Arg⇡[ArgG[ArgN⇡ and Def is defined as: 8Arg↵↪Argβ 2 Arg↪ (Arg↵↪Argβ) 2 Def iff (Arg↵↪Argβ) 2 AttCQ1-5 and (Argβ↪Arg↵) 62≻.
The next section explains how an AF for a plan proposal is evaluated and used to identify the best plan(s).
3.2 Evaluating the Argumentation Framework
Argumentation semantics [Dung, 1995] are a means for evaluating arguments in an AF. Among the proposed semantics are the credulous preferred semantics which several authors have suggested [Caminada, 2006; Prakken, 2006; Oren, 2013] are appropriate for reasoning about actions. Caminada [2006] provides an intuitive way to identify the status of arguments w.r.t. various semantics through labellings. An argument is, respectively, labelled in, out and undec, if it is acceptable, rejected and undecided under a certain semantics. In a complete labelling (Lcmp), an argument is labelled in iff all its attackers are labelled out, and is labelled out iff there exists an attacker for it that is labelled in. A complete labelling in which the set of arguments labelled in are maximal (w.r.t. set inclusion) is a preferred labelling (Lpr). An argument is credulously accepted under preferred semantics if it is labelled in by at least one preferred labelling.
Definition 13 (Justified Plans). Plan ⇡ is justified if Arg⇡ is labelled in by at least one preferred labelling for AF⇡: 9 Lpr s.t. Arg⇡ 2 in(L).
Although all justified plans are internally consistent, they can still be disagreed with externally. That is, there might be further criteria to take into account when identifying the best plan among justified plans. We define the criteria for the best plan(s) using an established set ordering principle in argumentation, the Democratic principle: (Si↪ Sj) 2 D iff 8β 2 Sj ∩ Si↪ 9↵ 2 Si ∩ Sj s.t. (↵↪ β) 2 ≻. Since preferences over goals and norms are partial, comparing two plans based on the set of goals and norms is not always possible. Therefore, absent such preference information, the best plan(s) satisfies the most goals while violating the fewest norms. We start by defining the goal-dominant and norm-dominant plans, based on which a better than relation between plans is defined.
Let G⇧ = ¶G⇡1 ↪G⇡2 ↪ ▷ ▷ ▷ ↪G⇡n ♦, where G⇡i is the set of goals satisfied in plan ⇡i .
Definition 14 (Goal-dominance). Plan ⇡i goal-dominates ⇡j denoted as (⇡i↪ ⇡j) 2 ≥G if
- ♣G⇡i ♣ ≥ ♣G⇡j ♣ (i.e., if DG is not a total preorder onG⇧). >G and ⇠G are strictly and equally dominant version of ≥G.
- DG is a total preorder on G⇧ and (G⇡i ↪ G⇡j ) 2 DG; or
Let Nvol(⇧) = ¶Nvol(⇡1)↪Nvol(⇡2)↪ ▷ ▷ ▷ ↪Nvol(⇡n)♦, where Nvol(⇡i) is the set of norms violated in plan ⇡i.
Definition 15 (Norm-dominance). Plan ⇡i norm-dominates ⇡j denoted as (⇡i↪ ⇡j) 2 ≥N if
- ♣Nvol(⇡i)♣ ≥ ♣Nvol(⇡j)♣ (i.e., if DN is not a total preorder on Nvol(⇧)).
- DN is a total preorder on Nvol(⇧) and (Nvol(⇡i)↪ Nvol(⇡j )) 2 DN ; or
>N and ⇠N are strictly and equally dominant version of ≥N .
- ⇡i is justified and ⇡j is not; or
Definition 16 (Plan Comparison). Plan ⇡i is better than ⇡j, denoted (⇡i↪ ⇡j) 2 >⇡, iff:
- ⇡i and ⇡j are both justified and (⇡i↪ ⇡j) 2 >G; or
Plan ⇡i is as good as ⇡j , denoted (⇡i↪ ⇡j) 2 ⇠⇡, iff (⇡i↪ ⇡j) 62 >⇡ and (⇡j↪ ⇡i) 62 >⇡ .
- ⇡i and ⇡j are both justified and (⇡i↪ ⇡j) 2 ⇠G but (⇡j ↪ ⇡i) 2 >N .
The relation >⇡ is irreflexive, asymmetric and transitive, while ⇠⇡ is an equivalence relation on ⇧.
Definition 18 (Best Plan(s)). Plan ⇡i is (one of) the best plan(s) for the agent to execute iff
Definition 17 (Equivalence Classes). Given ⇡ 2 ⇧, let [⇡i] denote the equivalence class to which ⇡i belongs. ([⇡i]↪ [⇡j]) 2 ≥ iff (⇡i↪ ⇡j) 2 >⇡ or (⇡i↪ ⇡j) 2 ⇠⇡.
- ÷ ⇡i is justified, and
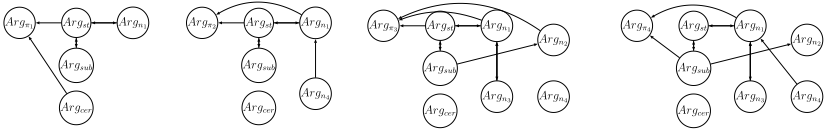
Example 6. Assume an agent with three goals strike↪ submission (c.f., Example 1), and certificate =
- ÷ @⇡j such that ([⇡j]↪ [⇡i]) 2 ≥.
¶course fee paid↪ theory test done↪ interviewed♦ and four norms n1↪ n2↪ n3↪ and n4 (c.f., Examples 2, 3, 4, and 5). Assume that the agent prefers satisfying goal submission to complying with norm n2: submission ⌫ n2, and prefers complying with n4 over n1: n4 ⌫ n1. Let ⇡1↪ ⇡2↪ ⇡3↪ ⇡4 2 ⇧:
- ÷ ⇡2 ♣= submission↪ certificate, N⇡2 = ¶n1↪ n4♦, Ncmp(⇡2) = ¶n4♦, Nvol(⇡2) = ¶n1♦
- ÷ ⇡1 ♣= submission, N⇡1 = ¶n1♦, Ncmp(⇡1) = ¶n1♦
- ÷ ⇡3 ♣= submission↪ certificate, N⇡3 = ¶n1↪ n2↪ n3↪ n4♦ Ncmp(⇡3) = ¶n3↪ n4♦, Nvol(⇡3) = ¶n1↪ n2♦
Figure 1 displays the argumentation graph associated with each of these plans 2 . Plan ⇡1 is not justified, whereas ⇡2↪ ⇡3 and ⇡4 all are. Thus, the first condition in Definition 18 holds for the last three plans. Since the preferences provided over goals and norms is minimal, in this example the number of goals satisfied and norms violated determines the best plans as follows: although ♣G⇡2 ♣ = ♣G⇡3 ♣ = ♣G⇡4 ♣, ♣Nvol(⇡2)♣ = ♣Nvol(⇡4)♣ < ♣Nvol(⇡3)♣. Therefore, ⇡2 ≻ ⇡3, ⇡4 ≻ ⇡3, and ⇡2 ⇠ ⇡4, which makes ⇡2 and ⇡4 the best plans.
- ÷ ⇡4 ♣= strike↪ certificate, N⇡4 = ¶n1↪ n2↪ n3↪ n4♦, Ncmp(⇡4) = ¶n2↪ n3↪ n4♦, Nvol(⇡4) = ¶n1♦
3.3 Properties
We now consider the properties of our system with regards to the rationality postulates [Caminada and Amgoud, 2007], and investigate the properties of the best plan(s) and the preferred extensions that include it.
Property 1. Closure: The conclusions of any extension (in labelled arguments) are closed under strict rules.
Proof. Since all arguments are built on defeasible rules, the property follows immediately.
Property 2. Direct Consistency: The conclusions of any extension are consistent.
Proof. Suppose the conclusions of extension E are inconsistent, i.e., there are arguments Arg↵↪ Argβ 2 E such that:
- Arg↵'s conclusion requires executing plan ⇡ and Argβ's conclusion requires satisfying goal g/complying with norm n, while g is not satisfied/n is violated in ⇡. Thus, Argβ defeats Arg↵; E is not conflict-free and cannot be an extension. - Arg↵'s conclusion requires satisfying goal g/complying with norm n and Argβ's conclusion requires satisfying goal g/complying with norm n0 , while g/n and g0 /n0 are inconsistent. Thus, Arg↵ attacks Argβ and vice versa. Due to the preferences, at least one of these attacks is identified as defeat and therefore E is not conflict-free and not an extension.
Property 3. Indirect Consistency: The closure under strict rules of the conclusions of any extension is consistent.
Proof. Follows immediately from lack of strict rules.
Property 4. If a plan argument is labelled in by preferred labelling L, the arguments representing all the goals that it does not satisfy and norms it violates are labelled out by L and vice versa:
2 st↪ sub and cer stand for strike, submission and certificate.
Proof. Every preferred labelling is a complete labelling. An argument is labelled in by a complete labelling iff all its attackers are labelled out. Therefore, a plan argument is labelled in by a preferred labelling iff all its attackers, namely the arguments for goals that it does not satisfy and norms that it violates, are labelled out by that labelling.
Property 5. If a plan argument is labelled in by preferred labelling L, the arguments representing all the goals that it satisfies and norms it complies with are also labelled in:
Proof. Since Arg⇡ 2 in(L), from Property 4 we know that Argg2G∩G⇡ [ Argn2Nvol(⇡) ✓ out(L). We also know from the definition of a plan that Argg2G⇡ [ Argn2Ncmp(⇡) is conflict free. Since all possible attackers of Argg2G⇡ [ Argn2Ncmp(⇡) belong to Argg2G∩G⇡ [ Argn2Nvol(⇡) and Argg2G∩G⇡ [Argn2Nvol(⇡) are all labelled out, we conclude that Argg2G⇡ [ Argn2Ncmp(⇡) ✓ in(L).
Note that from Argg2G⇡ [ Argn2Ncmp(⇡) ✓ in(L) one cannot conclude that Arg⇡ 2 in(L), as there might be justified goals or norms not satisfied or complied with in the plan.
Property 6. There is no more than one preferred labelling in which Arg⇡ 2 in(L).
Proof. From Properties 4 and 5 we know that if Arg⇡ 2 in(L) then Argg2G∩G⇡ [ Argn2Nvol(⇡) ✓ out(L) and Argg2G⇡ [ Argn2Ncmp(⇡) ✓ in(L). Since every preferred labelling is a complete labelling and the following property holds for complete labellings: if out(Lcmp1) = out(Lcmp2) then Lcmp1 = Lcmp2; we conclude that there is no more than one preferred labelling in which Arg⇡ 2 in(L).
Property 7. If Arg⇡ 2 in(L), L is a stable labelling.
Proof. In Property 4 we showed that if Arg⇡ 2 in(L) then Argg2G∩G⇡ [ Argn2Nvol(⇡) ✓ out(L) and Argg2G⇡ [ Argn2Ncmp(⇡) ✓ in(L), which makes the undec(L) = ;. A preferred labelling with undec(L) = ; is a stable labelling. Therefore, L is a stable labelling.
Property 8. Let ⌫gn be a total preorder on G[N and therefore ⌫ be a total preorder on goal and norm arguments. If Arg⇡ 2 in(L), and the set of arguments for the most preferred goals and norms, Pref (Arg), is conflict free, all arguments belong to Pref (Arg) are labelled in by L.
Proof. Elements of set Pref (Arg) cannot be defeated, since the set is conflict-free and the remaining arguments belong to Arg ∩ Pref (Arg). The latter cannot defeat elements of Pref (Arg), because this would imply an attack from a less preferred argument to a more preferred one has resulted in a defeat, which is contrary to assumption. Assume that 9Arg↵ 2 Pref (Arg) such that Arg↵ 62 in(L). If @Argβ 2 in(L) s.t. (Arg↵↪Argβ) 2 Def then Arg↵ should have been labelled in by L otherwise it is contrary to the assumption of maximality of preferred labellings. If 9Argβ 2 in(L) s.t. (Arg↵↪Argβ) 2 Def then 9Argγ 2 in(L) s.t. (Argγ↪Arg↵) 2 Def , which is contradictory to the fact that Arg↵ cannot be defeated. Therefore, all elements of Pref (Arg) are labelled in by in(L).
4 Explaining the Justifiability of the Best Plan
In this section we exploit an existing dialogue for preferred semantics known as Socratic Discussion [Caminada et al., 2014a] to provide an explanation for the justifiability of the best plan(s). Deciding if an argument is in at least one preferred extension amounts to deciding if it is in at least in one admissible extension (i.e. it is labelled in by at least one admissible labelling). In an admissible labelling if an argument is labelled in, all its attackers are labelled out, and if an argument is labelled out, it has an attacker that is labelled in.
Definition 19 (Socratic Discussion [Caminada et al., 2014a]). Let AF = hArg↪Def i. The sequence of moves [∆1↪∆2↪ ▷ ▷ ▷ ↪∆n] (n ≥ 1) is a Socratic discussion iff: (i) each odd move (M-move) is an argument labelled in; (ii) each even move (S-move) is an argument labelled out; (iii) each argument moved by S attacks an argument moved by M earlier in the dialogue; (iv) each argument moved by M attacks an argument moved by S in the previous step; (v) S-moves cannot be repeated. Player S wins the discussion if there is an M-move and an S-move containing the same argument. Otherwise, the winner is the player that makes the last move.
Given that the agent's best plans(s) ⇡ is labelled in by at least one preferred labelling, player M is guaranteed a winning strategy in a Socratic discussion with ∆1 = in(Arg⇡). The even moves in the rest of dialogue are arguments labelled out, which according to Property 4 are goals not satisfied or norms violated in ⇡. On the other hand, the rest of odd moves in the dialogue are arguments labelled in, which according to Property 5 are goals satisfied or norms complied with in ⇡. Since each odd move attacks the even move in the previous step, during a dialogue the agent is able to dialectically explain why it did not satisfy a goal or violate a norm, which are the two causes of attacks on plan proposals.
Example 7. This example shows a Socratic discussion ∆ = [in(Arg⇡4 )↪ out(Argsub)↪ in(Argst)↪ out(Argn1 )↪ in(Argn4 )] for plan ⇡4.
- M: Plan ⇡4 is (one of) the best plan(s) and is justifiable.
- S: Why does the plan not satisfy goal submission?
- M: As it satisfies goal strike, attacking goal submission.
- S: Why does the plan violate norm n1?
- M: Because the plan satisfies norm n4 that attacks norm n1.
5 RelatedWork
One of the most well-known scheme-based approach in practical reasoning is [Atkinson and Bench-Capon, 2007]. Recently, [Oren, 2013] has proposed a similar scheme-based approach for normative practical reasoning where arguments are constructed for a sequence of actions. Similar to the latter approach, we construct arguments for plans rather than actions. [Oren, 2013] assumes that conflicts within and between goals and norms are inferred from paths, rather than being obtained from the model. Thus, although it is possible to explain why one path is preferred over another, it is not possible to understand why a path does not satisfy a goal or violate a norm. In contrast, we explicitly consider why an agent does not satisfy a goal, or violate a norm. In addition, in this work the explanation of justifiability of why a plan is (one of) the best plan(s) for the agent to execute is formulated using a dialogue game for preferred semantics.
There are several applications where dialogue games are used for explanation purposes [Zhong et al., 2014; Fan and Toni, 2015; Caminada et al., 2014b]. In [Zhong et al., 2014] and [Fan and Toni, 2015] admissible dispute trees developed for Assumption-based Argumentation [Dung et al., 2009] are used to provide explanation for why a certain decision is better than another. In [Caminada et al., 2014b] a dialogical proof based on the grounded semantics [Caminada and Podlaszewski, 2012] is created to justify the actions executed in a plan. Despite the popularity of the preferred semantics, they have not been used for explanation in such contexts, and our work is the first to do so in the practical reasoning domain.
6 Conclusion and FutureWork
In contrast to existing argument based practical reasoning approaches, we propose a framework that integrates both the reasoning and dialogical aspects of argumentation to perform normative practical reasoning. In doing so, we answer the question of how an agent should act in a normative environment under conflicting goals and norms. Moreover, our approach can generate explanation for agent behaviour using an argumentation-based dialogue.
In future work we will investigate temporal solutions to addressing goal-goal and goal-norm conflict, similar to how conflicts between norms are handled. We also intend to empirically evaluate the effectiveness of our explanations, determining how likely a human is to accept the recommendation of a system regarding the best plan(s).
@inproceedings{ijcai2016p180,
  title     = {Normative Practical Reasoning via Argumentation and Dialogue},
  author    = {Shams, Zohreh and De Vos, Marina and Oren, Nir and Padget, Julian A.},
  booktitle = {Proceedings of the Twenty-Fifth International Joint Conference on
               Artificial Intelligence, {IJCAI-16}},
  publisher = {AAAI Press / International Joint Conferences on Artificial Intelligence},
  editor    = {Subbarao Kambhampati},
  pages     = {1244--1249},
  year      = {2016},
  month     = {7},
  url       = {https://ijcai.org/proceedings/2016/180},
}
TY - CPAPER TI - Normative Practical Reasoning via Argumentation and Dialogue AU - Shams, Zohreh AU - De Vos, Marina AU - Oren, Nir AU - Padget, Julian A. T2 - Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-16 PB - AAAI Press / International Joint Conferences on Artificial Intelligence PY - 2016 SP - 1244 EP - 1249 UR - https://ijcai.org/proceedings/2016/180 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





