
Constructing Abstraction Hierarchies Using a Skill-Symbol Loop
Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence. Pages 1648-1653.
Abstract
We describe a framework for building abstraction hierarchies whereby an agent alternates skill- and representation-construction phases to construct a sequence of increasingly abstract Markov decision processes. Our formulation builds on recent results showing that the appropriate abstract representation of a problem is specified by the agent's skills. We describe how such a hierarchy can be used for fast planning, and illustrate the construction of an appropriate hierarchy for the Taxi domain.
- [Bacchus and Yang, 1991] F. Bacchus and Q. Yang. The down- ward refinement property. In Proceedings of the 12th In- ternational Joint Conference on Artificial Intelligence, pages 286-292, 1991. IJCAI
- [Barto and Mahadevan, 2003] A.G. Barto and S. Mahadevan. Recent advances in hierarchical reinforcement learning. Dis- crete Event Dynamic Systems, 13:41-77, 2003.
- [Dietterich, 2000] T.G. Dietterich. Hierarchical reinforcement learning with the MAXQ value function decomposition. Journal of Artificial Intelligence Research, 13:227-303, 2000.
- [Hengst, 2002] B. Hengst. Discovering hierarchy in reinforce- ment learning with HEXQ. In Proceedings of the Nineteenth International Conference on Machine Learning, pages 243- 250, 2002.
- [Hengst, 2012] Bernhard Hengst. Hierarchical approaches. In Marco Wiering and Martijn van Otterlo, editors, Reinforce- ment Learning, volume 12 of Adaptation, Learning, and Optimization, pages 293-323. Springer Berlin Heidelberg, 2012.
- [Jonsson and Barto, 2005] A. Jonsson and A.G. Barto. A causal approach to hierarchical decomposition of factored MDPs. In Proceedings of the Twenty Second International Conference on Machine Learning, pages 401-408, 2005.
- [Konidaris et al., 2014] G.D. Konidaris, L.P. Kaelbling, and T. Lozano-Perez. Constructing symbolic representations for high-level planning. In Proceedings of the Twenty- Eighth Conference on Artificial Intelligence, pages 1932- 1940, 2014.
- [Konidaris et al., 2015] G.D. Konidaris, L.P. Kaelbling, and T. Lozano-Perez. Symbol acquisition for probabilistic high- level planning. In Proceedings of the Twenty Fourth Inter- national Joint Conference on Artificial Intelligence, pages 3619-3627, 2015.
- [McDermott et al., 1998] D. McDermott, M. Ghallab, A. Howe, C. Knoblock, A. Ram, M. Veloso, D. Weld, and D. Wilkins. PDDL-the planning domain definition language. Technical Report CVC TR98003/DCS TR1165, Yale Center for Computational Vision and Control, 1998.
- [Mehta et al., 2008] N. Mehta, S. Ray, P. Tadepalli, and T. Di- etterich. Automatic discovery and transfer of MAXQ hierar- chies. In Proceedings of the Twenty Fifth International Con- ference on Machine Learning, pages 648-655, 2008.
- [Mugan and Kuipers, 2012] J. Mugan and B. Kuipers. Au- tonomous learning of high-level states and actions in con- tinuous environments. IEEE Transactions on Autonomous Mental Development, 4(1):70-86, 2012.
- [Parr and Russell, 1997] R. Parr and S. Russell. Reinforcement learning with hierarchies of machines. In Advances in Neural Information Processing Systems 10, pages 1043-1049, 1997.
- [S ¸ims ¸ek and Barto, 2008] Ö. S ¸ims ¸ek and A.G. Barto. Skill characterization based on betweenness. In Advances in Neu- ral Information Processing Systems 22, pages 1497-1504, 2008.
- [Solway et al., 2014] A. Solway, C. Diuk, N. Cordova, D. Yee, A.G. Barto, Y. Niv, and M.M. Botvinick. Optimal behavioral hierarchy. PLOS Computational Biology, 10(8):e1003779, 2014.
- [Sutton and Barto, 1998] R.S. Sutton and A.G. Barto. Rein- forcement Learning: An Introduction. MIT Press, Cam- bridge, MA, 1998.
- [Sutton et al., 1999] R.S. Sutton, D. Precup, and S.P. Singh. Between MDPs and semi-MDPs: A framework for temporal abstraction in reinforcement learning. Artificial Intelligence, 112(1-2):181-211, 1999.
- [Vigorito and Barto, 2010] C.M. Vigorito and A.G. Barto. In- trinsically motivated hierarchical skill learning in structured environments. IEEE Transactions on Autonomous Mental Development, 2(2), 2010.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
One of the core challenges of artificial intelligence is that of linking abstract decision-making to low-level, real-world action and perception. Hierarchical reinforcement learning methods [Barto and Mahadevan, 2003] approach this problem through the use of high-level temporally extended macroactions, or skills, which can significantly decrease planning times [Sutton et al., 1999]. Skill acquisition (or skill discovery) algorithms (recently surveyed by Hengst [2012]) aim to discover appropriate high-level skills autonomously. However, in most hierarchical reinforcement learning research the state space does not change once skills have been acquired. An agent that has acquired high-level skills must still plan in its original low-level state space-a potentially very difficult task when that space is high-dimensional and continuous. Although some of the earliest formalizations of hierarchical reinforcement learning [Parr and Russell, 1997; Dietterich, 2000] featured hierarchies where both the set of available actions and the state space changed with the level of the hierarchy, there has been almost no work on automating the representational aspects of such hierarchies.
Recently, Konidaris et al. [2014] considered the question of how to construct a symbolic representation suitable for planning in high-dimensional continuous domains, given a set of high-level skills. The key result of that work was that the appropriate abstract representation of the problem was directly determined by characteristics of the skills available to the agent-the skills determine the representation, and adding new high-level skills must result in a new representation.
We show that these two processes can be combined into a skill-symbol loop: the agent acquires a set of high-level skills, then constructs the appropriate representation for planning using them, resulting in a new problem in which the agent can again perform skill acquisition. Repeating this process leads to an abstraction hierarchy where both the available skills and the state space become more abstract at each level of the hierarchy. We describe the properties of the resulting abstraction hierarchies and demonstrate the construction and use of one such hierarchy in the Taxi domain.
2 Background
Reinforcement learning problems are typically formalized as Markov decision processes or MDPs, represented by a tuple M = (S↪A↪R↪ P↪ γ), where S is a set of states, A is a set of actions, R(s↪ a↪ s0 ) is the reward the agent receives when executing action a in state s and transitioning to state s0 , P(s0 ♣s↪ a) is the probability of the agent finding itself in state s0 having executed action a in state s, and γ 2 (0↪ 1] is a discount factor [Sutton and Barto, 1998].
We are interested in the multi-task reinforcement learning setting where, rather than solving a single MDP, the agent is tasked with solving several problems drawn from some task distribution. Each individual problem is obtained by adding a set of start and goal states to a base MDP that specifies the state and action spaces and background reward function. The agent's task is to minimize the average time required to solve new problems drawn from this distribution.
2.1 Hierarchical Reinforcement Learning
Hierarchical reinforcement learning [Barto and Mahadevan, 2003] is a framework for learning and planning using higherlevel actions built out of the primitive actions available to the agent. Although other formalizations exist-mostly notably the MAX-Q [Dietterich, 2000] and Hierarchy of Abstract Machines [Parr and Russell, 1997] approaches-we adopt the options framework [Sutton et al., 1999], which models temporally abstract macro-actions as options.
An option o consists of three components: an option policy, ⇡o, which is executed when the option is invoked; an initiation set, which describes the states in which the option may be executed; and a termination condition, βo(s) ! [0↪ 1], which describes the probability that an option will terminate upon reaching state s.
An MDP where primitive actions are replaced by a set of possibly temporally-extended options (some of which could simply execute a single primitive action) is known as a semi Markov decision process (or SMDP), which generalizes MDPs to handle action executions that may take more than one time step. An SMDP is described by a tuple M = (S↪O↪R↪ P↪ γ), where S is a set of states; O is a set of options; R(s0 ↪ ⌧ ♣s↪ o) is the reward received when executing option o 2 O(s) at state s 2 S, and arriving in state s0 2 S after ⌧ time steps; P(s0 ↪ ⌧ ♣s↪ o) is a PDF describing the probability of arriving in state s0 2 S, ⌧ time steps after executing option o 2 O(s) in state s 2 S; and γ 2 (0↪ 1] is a discount factor, as before.
The problem of deciding which options an agent should acquire is known as the skill discovery problem. A skill discovery algorithm must, through experience (and perhaps additional advice or domain knowledge), acquire new options by specifying their initiation set, Io, and termination condition, βo. The option policy is usually specified indirectly via an option reward function, Ro, which is used to learn ⇡o. Each new skill is added to the set of options available to the agent with the aim of either solving the original or subsequent tasks more efficiently. Our framework is agnostic to the specific skill discovery method used (many exist).
Very few approaches combine temporal abstraction with state abstraction to construct a hierarchy. For example, Mehta et al. [2008] is able to recover a MaxQ hierarchy from demonstration trajectories, but assumes a factored, discrete state space. The most common approach [Hengst, 2002; Jonsson and Barto, 2005; Vigorito and Barto, 2010; Mugan and Kuipers, 2012] assumes a factored (but possibly continuous) state MDP, finds a ranking of state factors from "lowestlevel" to "highest-level", and successively constructs options to change each state factor; these algorithms differ primarily in the method used to order the state factors. The resulting options are hierarchical in the sense that the options for modifying higher-level state variables can execute those for modifying lower-level state variables. However, the agent has access to all options at the same time, and at the same level, when learning to solve the task. Similarly, state abstraction is generally limited to finding option-specific state abstractions for learning each option policy (typically using only state factors at a lower-level than the factor the option is constructed to modify).
2.2 Representation Acquisition
While skill acquisition allows an agent to construct higherlevel actions, it alone is insufficient for constructing truly useful abstraction hierarchies because the agent must still plan in the original state space, no matter how abstract its actions become. A complementary approach is taken by recent work on representation acquisition [Konidaris et al., 2014], which considers the question of constructing a symbolic description of an SMDP suitable for high-level planning. Key to this is the definition of a symbol as a name referring to a set of states:
Definition 1. A propositional symbol σZ is the name of a test ⌧Z, and corresponding set of states Z = ¶s 2 S ♣ ⌧Z(s) = 1♦.
The test, or grounding classifier, is a compact representation of a (potentially uncountably infinite) set of states in which the classifier returns true (the grounding set). Logical operations (e.g., and) using the resulting symbolic names have the semantic meaning of set operations (e.g., \) over the grounding sets, which allows us to reason about which symbols (and corresponding grounding classifiers) an agent should construct in order to be able to determine the feasibility of high-level plans composed of sequences of options. We use the grounding operator G to obtain the grounding set of a symbol or symbolic expression; for example, G(σZ) = Z, G(σA and σB) = A \ B. For convenience we also define G over collections of symbols; for a set of symbols A, we define G(A) = [iG(ai)↪ 8ai 2 A.
Konidaris et al. [2014] showed that defining a symbol for each option's initiation set and the symbols necessary to compute its image (the set of states the agent might be in after executing the option from some set of starting states) are necessary and sufficient for planning using that set of options. The feasibility of a plan is evaluated by computing each successive option's image, and then testing whether it is a subset of the next option's initiation set. Unfortunately, computing the image of an option is intractable in the general case. However, the definition of the image for at least two common classes of options is both natural and computationally very simple.
The first is the subgoal option: the option reaches some set of states and terminates, and the state it terminates in can be considered independent of the state execution began in. In this case we can create a symbol for that set (called the effect set-the set of all possible states the option may terminate in), and use it directly as the option's image. We thus obtain a symbolic vocabulary that contains 2n symbols for n options (a symbol for each option's initiation and effect sets) and is provably sufficient for planning. Building a forward model using this vocabulary leads to a plan graph representation: a graph with n nodes, and an edge from node i to node j if option j's initiation set is a superset of option i's effect set. Planning amounts to finding a path in the plan graph; once this graph has been computed, the grounding classifiers can be discarded.
The second class of options are abstract subgoal options: the low-level state is factored into a vector of state variables, and executing each option sets some variables to a subgoal (again, independently of the starting state) while leaving others unchanged. In this case the image operator can be computed using the intersection of the effect set (as in the subgoal option case) and a modified starting state classifier (where the variables that are changed by the option are projected out). The resulting symbols are again necessary and sufficient for planning, and constructing a forward model using them results in a STRIPS-like factored representation which can be automatically converted to PDDL [McDermott et al., 1998]. After conversion the grounding classifiers can be discarded, and the PDDL model used as input to an off-the-shelf task planner.
Representation acquisition as described above constructs an MDP from a low-level SMDP. The low-level SMDP may be stochastic and have continuous states and continuous primitive actions (though the set of options must be discrete), but the constructed abstract MDP is discrete and deterministic. This occurs because the abstract MDP is constructed for the purposes of finding plans that are guaranteed to succeed. This approach has recently been generalized to enable the agent to instead compute the probability that a plan succeeds [Konidaris et al., 2015], which results in a stochastic (but still discrete) abstract MDP; we leave the construction of probabilistic hierarchies to future work.
3 Constructing Abstraction Hierarchies
The results outlined above show that the two fundamental aspects of hierarchy-skills and representations-can be tightly coupled: skill acquisition drives representational abstraction. An agent that has performed skill acquisition in an MDP to obtain higher-level skills can automatically determine a new abstract state representation suitable for planning in the resulting SMDP. We now show that these two processes can be alternated to construct an abstraction hierarchy.
We assume the following setting: an agent is faced with some base MDP M0, and aims to construct an abstraction hierarchy that enables efficient planning for new problems posed in M0, each of which is specified by a start and goal state set. M0 may be continuous-state and even continuousaction, and the options defined in it may be stochastic, but all subsequent levels of the hierarchy will be constructed to be discrete-state, discrete-action, and deterministic. We adopt the following definition of an abstraction hierarchy:
Definition 2. An n-level hierarchy on base MDP M0 = (S0↪A0↪R0↪ P0↪ γ0) is a collection of MDPs Mi = (Si↪Ai↪Ri↪ Pi↪ γi), i 2 ¶1↪ ▷▷▷↪ n♦, such that each action set Aj, 0 < j n, is a set of options defined over Mj-1 (i.e., Mj-1+ = (Sj-1↪ Aj ↪ Rj-1↪ Pj-1) is an SMDP).
Here, Mj-1+ is the SMDP created by adding options to Mj-1 but leaving the state space unchanged.
This captures the core assumption behind hierarchical reinforcement learning: hierarchies are built through macroactions. Note that this formulation retains the downward refinement property from classical hierarchical planning [Bacchus and Yang, 1991]-meaning that a plan at level j can be refined to a plan at level j - 1 without backtracking to level j or higher-because a policy at any level is also a (not necessarily Markovian [Sutton et al., 1999]) policy at any level lower, including M0. However, while Definition 2 links the action set of each MDP to the action set of its predecessor in the hierarchy, it says nothing about how to link their state spaces. To do so, we must in addition determine how to construct a new state space Sj , transition probability function Pj , and reward function Rj . 1
Fortunately, this is exactly what representation acquisition provides: a method for constructing a new symbolic representation suitable for planning in Mj-1+ using the options in Aj . This provides a new state space Sj, which, combined with Aj, specifies Pj. The only remaining component is the reward function. A representation construction algorithm based on sets [Konidaris et al., 2014]-such as we adopt here-is insufficient for reasoning about expected rewards, which requires a formulation based on distributions [Konidaris et al., 2015]. For simplicity, we can remain consistent and simply set the reward to a uniform transition penalty of -1; alternatively, we can adopt just one aspect of the distribution-based representation and set Rj to the empirical mean of the rewards obtained when executing each option.
1 We generally set γi = 1 for i > 0.
Thus, we have all the components required to build level j of the hierarchy from level j - 1. This procedure can be repeated in a skill-symbol loop-alternating skill acquisition and representation acquisition phases-to construct an abstraction hierarchy. It is important to note that there are no degrees of freedom or design choices in the representation acquisition phase of the skill-symbol loop; the algorithmic questions reside solely in determining which skills to acquire at each level.
This construction results in a specific relationship between MDPs in a hierarchy: every state at level j refers to a set of states at level j - 1. 2 A grounding in M0 can therefore be computed for any state at level j in the hierarchy by applying the grounding operator j times. If we denote this "final grounding" operator as G0, then 8j↪ sj 2 Sj↪ 9Z0 ✓ S0 such that G0(sj) = Z0.
We now illustrate the construction of an abstraction hierarchy via an example-a very simple task that must be solved by a complex agent. Consider a robot in a room with two boxes, one containing an apple (Figure 1a). The robot must occasionally move the apple from one box to the other. Directly accomplishing this involves solving a highdimensional motion planning problem, so instead the robot is given five motor skills: move-gripper-above1 and movegripper-above2 use motion planning to move the robot's gripper above each box; pregrasp controls the gripper so that it cages the apple, and is only executable from above it; grasp can be executed following pregrasp, and runs a gradientdescent based controller to achieve wrench-closure on the apple; and release drops the apple. These form A1, the actions in the first level of the hierarchy, and since they are abstract subgoal options (though release must be split into two cases, one for each box) the robot automatically constructs a factored state space (see Figure 1b) that specifies M1. 3 This enables abstract planning-the state space is independent of the complexity of the robot, although S1 contains some low-level details (e.g., pregrasped).
Next, the robot detects (perhaps by applying a skill discovery algorithm in M1) that pregrasp is always followed by grasp, and therefore replaces these actions with grab-apple, which together with the remaining skills in A1 forms A2. This results in a smaller MDP, M2 (Figure 1c), which is a good abstract model of the task. The robot then creates a skill that picks up the apple in whichever box it is in, and moves it over the other box (perhaps by applying a skill discovery algorithm to M2). A3 now consists of just a single action, swap-apple, requiring just two propositions to define S3:
2 Note that Sj+1 is not necessarily a partition of Sj-the grounding sets of two states in Sj+1 may overlap.
3 The careful reader will notice that there are only 6 symbols, when we were expecting 5 ⇥ 2 = 10. This is because in some cases the precondition set of one option is equal to the effect set of another (e.g., pregrasped is both the effect set of pregrasp action and the precondition of grasp) and because some effect sets are the complement of each other (e.g., the effect sets of release and grasp.)
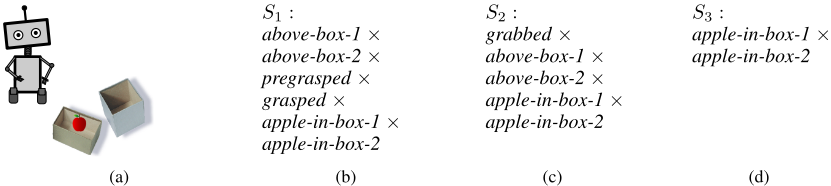
apple-in-box-1, and apple-in-box-2 (Figure 1d). The abstraction hierarchy has abstracted away the details of the robot (in all its complexity) and exposed the (almost trivial) underlying task structure.
4 Planning Using an Abstraction Hierarchy
Once an agent has constructed an abstraction hierarchy, it must be able to use it to rapidly find plans for new problems. We formalize this process as the agent posing a plan query to the hierarchy, which should then be used to generate a plan for solving the problem described by the query. We adopt the following definition of a plan query:
Definition 3. A plan query is a tuple (B↪ G), where B ✓ S0 is the set of base MDP states from which execution may begin, and G ✓ S0 (the goal) is the set of base MDP states in which the agent wishes to find itself following execution.
The critical question is at which level of the hierarchy planning should take place. We first define a useful predicate, planmatch, which determines whether an agent should attempt to plan at level j (see Figure 2):
Definition 4. A pair of abstract state sets b and g match a plan query (B↪G) (denoted planmatch(b↪ g↪B↪G)) when B ✓ G0(b) and G0(g) ✓ G.
Theorem 1. A plan can be found to solve plan query (B↪ G) at level j iff 9b↪ g ✓ Sj such that planmatch(b↪ g↪B↪G), and there is a feasible plan in Mi from every state in b to some state in g.
Proof. The MDP at level j is constructed such that a plan p starting from any state in G(b) (and hence also G0(b)) is guaranteed to leave the agent in a state in G(g) (and hence also G0(g)) iff p is a plan in MDP Mj from b to g [Konidaris et al., 2014].
Plan p is additionally valid from B to G iff B ✓ G0(b) (the start state at level j refers to a set that includes all query start states) and G0(g) ✓ G (the query goal includes all states referred to by the goal at level j).
Note that b and g may not be unique, even within a single level: because Sj is not necessarily a partition of Sj-1, there may be multiple states, or sets of states, at each level whose final groundings are included by G or include B; a solution from any such b to any such g is sufficient. For efficient planning it is better for b to be a small set to reduce the number of start states while remaining large enough to subsume B;
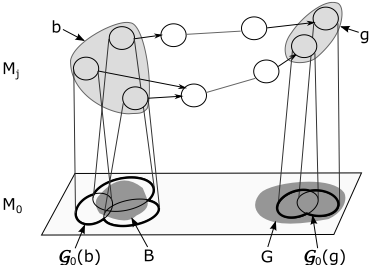
if b = Sj then answering the plan query requires a complete policy for Mj , rather than a plan. However, finding a minimal subset is computationally difficult. One approach is to build the maximal candidate set b = ¶s♣G0(s) \ B 6= ;↪ s 2 Sj♦. This is a superset of any start match, and a suitable one exists at this level if and only if B ✓ [s2bG0(s). Similarly, g should be maximally large (and so easy to reach) while remaining small enough so that its grounding set lies within G. At each level j, we can therefore collect all states that ground out to subsets of G: g = ¶s♣G0(s) ✓ G↪ s 2 Sj♦. These approximations result in a unique pair of sets of states at each level-at the cost of potentially including unnecessary states in each set- and can be computed in time linear in ♣Sj ♣.
It follows from the state abstraction properties of the hierarchy that a planmatch at level j implies the existence of a planmatch at all levels below j.
Theorem 2. Given a hierarchy of state spaces ¶S0↪ ▷▷▷↪ Sn♦ constructed as above and plan query (B↪G), if 9b↪ g ✓ Sj such that planmatch(b↪ g↪B↪G), for some j↪ n ≥ j > 0, then 9b0 ↪ g0 ✓ Sk such that planmatch(b0 ↪ g0 ↪B↪G), 8k 2 ¶0↪ ▷▷▷↪ j - 1♦.
Proof. We first consider k = j - 1. Let b0 = G(b), and g0 = G(g). Both are, by definition, sets of states in Sj-1. By definition of the final grounding operator, G0(b) = G0(b0 ) and G0(g) = G0(g0 ), and hence B ✓ G0(b0 ) and G0(g0 ) ✓ G. This process can be repeated to reach any k < j.
Any plan query therefore has a unique highest level j containing a planmatch. This leads directly to Algorithm 1, which starts looking for a planmatch at the highest level of the hierarchy and proceeds downwards; it is sound and complete by Theorem 1.
Input: MDP hierarchy ¶M0↪ ▷▷▷↪Mn♦, query (B↪ G). for j 2 ¶n↪ ▷▷▷↪ 0♦ do for 8b↪ g ✓ Sj s.t. planmatch(b↪ g↪ B↪ G) do ⇡ findplan(Mj↪ b↪ g) if ⇡ 6= null then return (Mj ↪ ⇡) end end endreturn null
Algorithm 1: A simple hierarchical planning algorithm.
The complexity of Algorithm 1 depends on its two component algorithms: one used to find a planmatch, and another to attempt to find a plan (possibly with multiple start states and goals). We denote the complexity of these algorithms as matching cost m(♣S♣) (linear using the approach described above) and planning cost p(♣S♣), for a problem with ♣S♣ states, respectively. The complexity of finding a plan at level l, where the first match is found at level k ≥ l, is given by h(k↪ l↪ M) = Pna=k+1 m(♣Sa♣)+ Pkb=l [m(♣Sb♣) + p(♣Sb♣)] ↪ for a hierarchy M with n levels. The first term corresponds to the search for the level with the first planmatch; the second term for the repeated planning at levels that contain a match but not a plan (a planmatch does not necessarily mean a plan exists at that level-merely that one could).
5 Discussion
The formula for h highlights the fact that hierarchies make some problems easier to solve and others harder: in the worst case, a problem that should take p(♣S0♣) timeone only solvable via the base MDP-could instead take Pna=0 [m(♣Sa♣) +p(♣Sb♣)] time. A key question is therefore how to balance the depth of the hierarchy, the rate at which the state space size diminishes as the level increases, which specific skills to discover at each level, and how to control false positive plan matches, to reduce planning time.
Recent work has highlighted the idea that skill discovery algorithms should aim to reduce average planning or learning time across a target distribution of tasks [S¸ ims¸ek and Barto, 2008; Solway et al., 2014]. Following this logic, a hierarchy M for some distribution over task set T should be constructed so as to minimize RT h(k(t)↪ l(t)↪M)P(t)dt↪ where k and l now both depend on each task t. Minimizing this quantity over the entire distribution seems infeasible; an acceptable substitute may be to assume that the tasks the agent has already experienced are drawn from the same distribution as those it will experience in the future, and to construct the hierarchy that minimizes h averaged over past tasks.
The form of h suggests two important principles which may aid the more direct design of skill acquisition algorithms. One is that deeper hierarchies are not necessarily better; each level adds potential planning and matching costs, and must be justified by a rapidly diminishing state space size and a high likelihood of solving tasks at that level. Second, false positive plan matches-when a pair of states that match the query is found at some level at which a plan cannot be found-incur a significant time penalty. The hierarchy should therefore ideally be constructed so that every likely goal state at each level is reachable from every likely start state at that level.
An agent that generates its own goals-as a completely autonomous agent would-could do so by selecting an existing state from an MDP at some level (say j) in the hierarchy. In that case it need not search for a matching level, and could instead immediately plan at level j, though it may still need to drop to lower levels if no plan is found in Mj.
6 An Example Domain: Taxi
We now explain the construction and use of an abstraction hierarchy for a common hierarchical reinforcement learning benchmark: the Taxi domain [Dietterich, 2000], depicted in Figure 3a. A taxi must navigate a 5⇥5 grid, which contains a few walls, four depots (labeled red, green, blue, and yellow), and a passenger. The taxi may move one square in each direction (unless impeded by a wall), pick up a passenger (when occupying the same square), or drop off a passenger (when it has previously picked the passenger up). A state at base MDP M0 is described by 5 state variables: the x and y location of the taxi and the passenger, and whether or not the passenger is in the taxi. This results in a total of 650 states (25 ⇥ 25 = 625 states for when the passenger is not in the taxi, plus another 25 for when the passenger is in the taxi and they are constrained to have the same location).
We now describe the construction of a hierarchy for the taxi domain using hand-designed options at each level, and present some results for planning using Algorithm 1 for three example plan queries.
Constructing M1. In this version of taxi, the agent is able to move the taxi to, and drop the passenger at, any square, but it expects to face a distribution of problems generated by placing the taxi and the passenger at a depot at random, and selecting a random target depot at which the passenger must be deposited. Consequently, we create navigation options for driving the taxi to each depot, and retain the existing putdown and pick-up options. 4 These options over M0 form the action set for level 1 of the hierarchy: A1 = ¶drive-to-red, drive-to-green, drive-to-blue, drive-to-yellow, pick-up, putdown♦.
Consider the drive-to-blue-depot option. It is executable in all states (i.e., its initiation set is S0), and terminates with the taxi's x and y position set to the position of the blue depot; if the passenger is in the taxi, their location is also set to that of the blue depot; otherwise, their location (and the fact that they are not in the taxi) remains unchanged. It can therefore be partitioned into two abstract subgoal options: one, when the passenger is in the taxi, sets the x and y positions of the taxi and passenger to those of the blue depot; another, when the passenger is not in the taxi, sets the taxi x and y coordinates and leaves those of the passenger unchanged. Both leave the in-taxi state variable unmodified. Similarly, the put-down and pick-up options are executable everywhere and when the taxi and passenger are in the same square, respectively, and modify the in-taxi variable while leaving the remaining variables the same. Partitioning all options in A1 into abstract subgoal options results in a factored state space consisting of 20 reachable states where the taxi or passenger are at the depot locations (4 ⇥ 4 states for when the passenger is not in the taxi, plus 4 for when they are).
4 These roughly correspond to the hand-designed hierarchical actions used in Dietterich [2000].
| Hierarchical Planning | ||||||
|---|---|---|---|---|---|---|
| Query | Level | Matching | Planning | Total | Base + Options | Base MDP |
| 1 | 2 | <1 | <1 | <1 | 770.42 | 1423.36 |
| 2 | 1 | <1 | 10.55 | 11.1 | 1010.85 | 1767.45 |
| 3 | 0 | 12.36 | 1330.38 | 1342.74 | 1174.35 | 1314.94 |
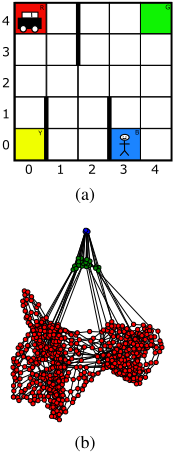
Constructing M2. Given M1, we now build the second level of the hierarchy by constructing options that pick up the passenger (wherever they are), move them to each of the four depots, and drop them off. These options become A2 = ¶passenger-to-blue, passenger-to-red, passenger-togreen, passenger-to-yellow♦. Each option is executable whenever the passenger is not already at the relevant depot, and it leaves the passenger and taxi at the depot, with the passenger outside the taxi. Since these are subgoal (as opposed to abstract subgoal) options, the resulting MDP, M1, consists of only 4 states (one for each location of the passenger) and is a simple (and coincidentally fully connected) graph. The resulting hierarchy is depicted in Figure 3b.
We used the above hierarchy to compute plans for three example queries, using dynamic programming and decision trees for planning and grounding classifiers, respectively. The results are given in Table 1; we next present each query, and step through the matching process in detail.
Example Query 1. Query Q1 has the passenger start at the blue depot (with the taxi at an unknown depot) and request to be moved to the red depot. In this case B1 refers to all states where the passenger is at the blue depot and the taxi is located at one of four depots, and G1 similarly refers to the red depot. The agent must first determine the appropriate level to plan at, starting fromM2, the highest level of the hierarchy. It finds state sb where G0(sb) = B1 (and therefore B1 ✓ G0(sb) holds), and sr where G0(sr) = G1 (and therefore G0(sr) ✓ G1), where sb and sr are the states in M2 referring to the passenger being located at the blue and red depots, respectively. Planning therefore consists of finding a plan from sb to sr at level M2; this is virtually trivial (there are only four states in M2 and the state space is fully connected).
Example Query 2. Query Q2 has the start state set as before, but now specifies a goal depot (the yellow depot) for the taxi. B2 refers to all states where the passenger is at the blue depot and the taxi is at an unknown depot, but G2 refers to a single state. M2 contains a state that has the same grounding set as B2, but no state in M2 is a subset of G2 because no state in M2 specifies the location of the taxi. The agent therefore cannot find a planmatch for Q2 at level M2.
At M1 no single state is a superset of B2, but the agent finds a collection of states sj, such that G0([jsj) = B2. It also finds a single state with the same grounding as G2. Therefore, it builds a plan at level M1 for each state in sj.
Example Query 3. In query Q3, the taxi begins at the red depot and the passenger at the blue depot, and its goal is to leave the passenger at grid location (1↪ 4), with the taxi goal location left unspecified. The start set, B3, refers to a single state, and the goal set, G3, refers to the set of states where the passenger is located at (1↪ 4).
Again the agent starts at M2. B3 is a subset of the grounding of the single state in M2 where the passenger is at the blue depot but the taxi is at an unknown depot. However, G3 is not a superset of any of the states in M2, since none contain any state where the passenger is not at a depot. Therefore the agent cannot plan for Q3 at level M2.
At level M1, it again find a state that is a superset of B3, but no state that is a subset of G3-all states in M1 now additionally specify the position of the taxi and passenger, but like the states in M2 they all fix the location of the passenger at a depot. All state groundings are in fact disjoint from the grounding of G3. The agent must therefore resort to planning in M0, and the hierarchy does not help (indeed, it results in a performance penalty due to the compute time required to rule out M1 and M2).
7 Summary
We have introduced a framework for building abstraction hierarchies by alternating skill- and representation-acquisition phases. The framework is completely automatic except for the choice of skill acquisition algorithm, to which our formulation is agnostic but upon which the usefulness of the hierarchy entirely depends. The resulting hierarchies combine temporal and state abstraction to realize efficient planning and learning in the multi-task setting.
Acknowledgments
The author would like to thank Michael Littman and Philip Thomas, as well as the reviewers, for their helpful thoughts on earlier drafts of this paper. This research was supported in part by DARPA under agreement number D15AP00104, and by the National Institutes of Health under award number R01MH109177. The U.S. Government is authorized to reproduce and distribute reprints for Governmental purposes notwithstanding any copyright notation thereon. The content is solely the responsibility of the authors and does not necessarily represent the official views of the National Institutes of Health or DARPA.
@inproceedings{ijcai2016p236,
  title     = {Constructing Abstraction Hierarchies Using a Skill-Symbol Loop},
  author    = {Konidaris, George Dimitri},
  booktitle = {Proceedings of the Twenty-Fifth International Joint Conference on
               Artificial Intelligence, {IJCAI-16}},
  publisher = {AAAI Press / International Joint Conferences on Artificial Intelligence},
  editor    = {Subbarao Kambhampati},
  pages     = {1648--1653},
  year      = {2016},
  month     = {7},
  url       = {https://ijcai.org/proceedings/2016/236},
}
TY - CPAPER TI - Constructing Abstraction Hierarchies Using a Skill-Symbol Loop AU - Konidaris, George Dimitri T2 - Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-16 PB - AAAI Press / International Joint Conferences on Artificial Intelligence PY - 2016 SP - 1648 EP - 1653 UR - https://ijcai.org/proceedings/2016/236 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





