
Proactivity in Robots
Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence. Pages 3994-3994.
Abstract
In order to be proactive, robots should be capable of generating and selecting their own goals, and pursuing activities towards their achievement. Goal reasoning has focused on the former set of cognitive abilities, and automated planning on the latter. Despite the existence of robots that possess both capabilities, we lack a general understanding of how to combine goal generation and goal achievement. In my work I introduce the notion of equilibrium maintenance as a contribution to this understanding. Formal evidence is provided that equilibrium maintenance is conducive to proactive robots, and I demonstrate my approach in a closed loop with a real robot in a smart home.
- [Beaudoin, 1994] Luc Beaudoin. Goal processing in au- tonomous agents. PhD thesis, Univ. of Birmingham, 1994.
- [Ghallab et al., 2014] Malik Ghallab, Dana Nau, and Paolo Traverso. The actor's view of automated planning and act- ing: A position paper. Artif Intell, 208:1-17, 2014.
- [Grosinger et al., 2014a] Jasmin Grosinger, Federico Pec- ora, and Alessandro Saffiotti. Find out why reading this paper is an opportunity of type opp0. In Cognitive Robotics Worksop at the Twenty-First ECAI, 2014.
- [Grosinger et al., 2014b] Jasmin Grosinger, Federico Pec- ora, and Alessandro Saffiotti. Find out why reading this paper is an opportunity of type opp0 -extended version. Presented at PhD Symposium, 2nd Örebro Winter School on AI & Robotics, 2014.
- [Grosinger et al., 2016] Jasmin Grosinger, Federico Pecora, and Alessandro Saffiotti. Making robots proactive through equilibrium maintenance. In Proc. of IJCAI, 2016. IJCAI
- [Hawes, 2011] Nick Hawes. A survey of motivation frame- works for intelligent systems. Artif Intell, 175(5):1020- 1036, 2011.
- [Kaelbling et al., 1998] Leslie Pack Kaelbling, Michael L. Littman, and Anthony R. Cassandra. Planning and act- ing in partially observable stochastic domains. Artificial Intelligence, 101(1 -2):99 -134, 1998.
- [Karlsson, 2001] Lars Karlsson. Conditional progressive planning under uncertainty. In Proc. of IJCAI, pages 431- 438, 2001. IJCAI
- [Pollack and Horty, 1999] Martha E Pollack and John F Horty. There's more to life than making plans: plan man- agement in dynamic, multiagent environments. AI Maga- zine, 20(4):71, 1999.
- [Vattam et al., 2013] Swaroop Vattam, Matthew Klenk, Matthew Molineaux, and David W Aha. Breadth of ap- proaches to goal reasoning: A research survey. In Goal Reasoning: Papers from the ACS Workshop, page 111, 2013.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Research Problem
My research is on proactiveness in robots. By the term proactive I understand a robot that is able to generate and select among its own goals and pursue activities towards their achievement.
Consider the following example: Anna, who owns a personal robot, has instructions from her physician to take pills daily at meal times. Not taking the pills can result in Anna being unwell. Throughout the day, there are moments in which it would be beneficial for the robot to proactively prompt Anna to take her pills, and moments in which it would not be. For instance, it would be pedantic to remind her of the pills at breakfast, but it may be adequate at lunch and really needed at dinner. If Anna goes to bed and has not taken her pills yet, the robot may become more invasive and bring the pills to her. The robot should also bring the pills at breakfast, if it knows that Anna will be out for the rest of the day. The decision on when to act and what to do must consider, in general, a multitude of aspects related to the current and future state of the whole system, including the robot, the user, and the pills.
In my work, I propose a predictive model of opportunity informing the decision of how to act to satisfy certain goals. This is reminiscent of the subject of planning. However, my aim is to not only enable the robot to autonomously select actions to achieve given goals, as done in planning, but also to infer the goals themselves. In line with [Hawes, 2011; Beaudoin, 1994; Ghallab et al., 2014; Pollack and Horty, 1999] I identify the need for a deliberative process independent from planning to realize this and refer to it as goal autonomy here.
My aim is to provide a general solution to the problem of proactiveness in robots. To this means, I introduce the following concepts. Opportunity relates current and future states, courses of action and desirable states: an action is an opportunity if it keeps the system in desired states, and if the robot has the ability to enact it. Equilibrium is defined as the absence of opportunities. The claim of my thesis is that a proactive robot should have the persistent meta-goal to maintain equilibrium. Hence, an equilibrium maintenance algorithm closes the loop between desirable states and plan execution by continuously evaluating potential opportunities and deciding which ones to act upon.
Proactivity in Robots
Jasmin Grosinger
Center for Applied Autonomous Systems (AASS), ¨Orebro University, 70182 ¨Orebro, Sweden, jngr@aass.oru.se
2 Contributions
My contributions include a framework that aims at making robots proactive by providing them with the ability to generate their own goals and act upon them. Many current approaches to integrate planning and goal autonomy, provide specific case-by-case solutions (see, e.g., the survey paper [Vattam et al., 2013]) but lack a general understanding of how these problems are related. Towards this aim, I have proposed a general formalization and computational framework that enables an agent to infer whether to act (condition), how (what action) and when (in which current or future state).
A first formal predictive model of opportunities has been reported in [Grosinger et al., 2014a]. This model allows to decouple the factors that determine conditions for acting - state changes, what is desirable, and robot capabilities. In my model, free-run F captures state transitions from changes in the environment; desirability is modeled by a sub-set of states, Des, which forms a partition with Undes (undesirable states) of all possible states; robot capabilities are captured by action schemes ↵ allowing for active state transition at any abstraction level, from individual or sequences of actions to action plans or policies. I characterize action schemes that bring the state into desirability as beneficial, denoted Bnf. The definition of different types of opportunity sets into relation all of these factors that influence the inference of conditions for acting (note that k models a time horizon).
For k = 0 all above properties collapse to the following:
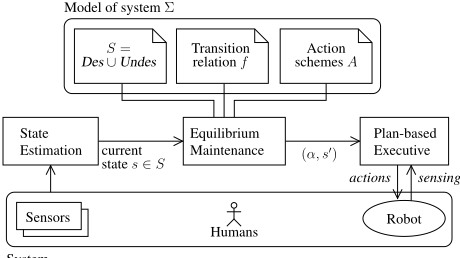
To make the formal model of opportunity operational, I developed an equilibrium maintenance algorithm. It closes the loop between desirable states and plan execution by continuously evaluating whether the system is in equilibrium and deciding which opportunities to act upon (see Figure 1). I
System
Figure 1: The Equilibrium Maintenance loop (realized by the EqM(K) algorithm) for a system ⌃ = hS↪ U↪ fi, where action schemes A are defined in terms of the robot's actions U.
have deployed the model in a real robotic system including a Scitos G5 mobile robot with a Kinova Jaco robotic arm, a smart home with Xbee sensors, a simple state estimation component, the open source planning system JSHOP and a plan-based executive module. Formal evidence is provided that the equilibrium maintenance framework is conducive to proactive robots [Grosinger et al., 2016].
3 Directions
I have started my PhD two and a half years ago in which I have accomplished the following: developed first versions of a formal model and an operational algorithm towards achieving proactiveness in autonomous robots as described in the previous section 2; investigated the relation of my approach to existing work; analyzed properties of the formal model; deployed my formal framework in a real robotic system [Grosinger et al., 2014a; 2016].
In the remaining one or one and a half years of my PhD I plan to consolidate the analysis of the relation between my approach and others, in particular in the fields of planning and goal reasoning, to obtain a crisp specification of my contributions. Additional robotic experiments are necessary for a stronger empirical validation. Furthermore, the formal properties of the existing framework need to be studied more in depth. After these steps, I plan to work on the extension of the current framework. Currently, the equilibrium maintenance framework captures uncertainty by non-determinism: multiple alternative states can be undesirable, the free-run dynamics of the system may be non-deterministic, and action schemes may have non-deterministic effects. It might be useful to quantify this uncertainty by associating degrees of desirability to states and probabilities to state transitions. For this extension, I plan to explore the use of decisiontheoretic planning [Karlsson, 2001] or POMDPs [Kaelbling et al., 1998]. Degrees of desirability might not only reflect state uncertainty. Multiple actors in the environment - objects, robotic actuators, human users - might influence what classifies as desirable on a global state level. This will allow to achieve different definitions of beneficial, e.g., partial, weak, etc.
In my work, I have formalized different types of opportunities for acting. If time allows, I aim to extend this notion by introducing definitions of durative and future opportunity. A tentative formulation of future opportunity was presented at [Grosinger et al., 2014b].
I believe that the proposed equilibrium maintenance approach unveils many challenging directions for future research, and I hope to have a chance to explore them after the end of my PhD. These include how to select among multiple opportunities of varying type and how to address the problem of interleaving equilibrium maintenance, planning and execution.
@inproceedings{ijcai2016p571,
  title     = {Proactivity in Robots},
  author    = {Grosinger, Jasmin},
  booktitle = {Proceedings of the Twenty-Fifth International Joint Conference on
               Artificial Intelligence, {IJCAI-16}},
  publisher = {AAAI Press / International Joint Conferences on Artificial Intelligence},
  editor    = {Subbarao Kambhampati},
  pages     = {3994--3994},
  year      = {2016},
  month     = {7},
  url       = {https://ijcai.org/proceedings/2016/571},
}
TY - CPAPER TI - Proactivity in Robots AU - Grosinger, Jasmin T2 - Proceedings of the Twenty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-16 PB - AAAI Press / International Joint Conferences on Artificial Intelligence PY - 2016 SP - 3994 EP - 3994 UR - https://ijcai.org/proceedings/2016/571 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





