
A Comprehensive Survey and Taxonomy on Point Cloud Registration Based on Deep Learning
Proceedings of the Thirty-Third International Joint Conference on Artificial Intelligence. Survey Track. Pages 8344-8353.
https://doi.org/10.24963/ijcai.2024/922
Keywords
- Computer Vision: General
- Computer Vision: CV: 3D computer vision
Abstract
Point cloud registration (PCR) involves determining a rigid transformation that aligns one point cloud to another. Despite the plethora of outstanding deep learning (DL)-based registration methods proposed, comprehensive and systematic studies on DL-based PCR techniques are still lacking. In this paper, we present a comprehensive survey and taxonomy of recently proposed PCR methods. Firstly, we conduct a taxonomy of commonly utilized datasets and evaluation metrics. Secondly, we classify the existing research into two main categories: supervised and unsupervised registration, providing insights into the core concepts of various influential PCR models. Finally, we highlight open challenges and potential directions for future research. A curated collection of valuable resources is made available at https://github.com/yxzhang15/PCR.
- [Ao et al., 2021] S. Ao, Q.g Hu, B. Yang, A. Markham, and Y. Guo. Spinnet: Learning a general surface descriptor for 3d point cloud registration. In CVPR, 2021.
- [Ao et al., 2023] S. Ao, Q. Hu, H. Wang, K. Xu, and Y. Guo. Buffer: Balancing accuracy, efficiency, and generalizabil- ity in point cloud registration. In CVPR, 2023.
- [Aoki et al., 2019] Y. Aoki, H. Goforth, R. Srivatsan, and L. Simon. Pointnetlk: Robust & efficient point cloud reg- istration using pointnet. In CVPR, 2019.
- [Arun et al., 1987] K. Arun, T. Huang, and S. Blostein. Least-squares fitting of two 3-d point sets. IEEE TPAMI, (5), 1987.
- [Bai et al., 2021] X. Bai, Z. Luo, L. Zhou, H. Chen, L. Li, Z. Hu, H. Fu, and C. Tai. Pointdsc: Robust point cloud registration using deep spatial consistency. In CVPR, 2021.
- [Cao et al., 2021] A. Cao, G. Puy, A. Boulch, and R. Mar- let. Pcam: Product of cross-attention matrices for rigid registration of point clouds. In ICCV, 2021.
- [Chang et al., 2015] A. Chang, T. Funkhouser, L. Guibas, P. Hanrahan, Q. Huang, Z. Li, S. Savarese, M. Savva, S. Song, H. Su, Xiao. J, Yi L., and Yu F. Shapenet: An information-rich 3d model repository. arXiv preprint arXiv:1512.03012, 2015.
- [Chen et al., 2022a] H. Chen, Z. Wei, Y. Xu, M. Wei, and J. Wang. Imlovenet: Misaligned image-supported regis- tration network for low-overlap point cloud pairs. In SIG- GRAPH, pages 1-9, 2022.
- [Chen et al., 2022b] Z. Chen, K. Sun, F. Yang, and W. Tao. Sc 2 -pcr: A second order spatial compatibility for efficient and robust point cloud registration. In CVPR, 2022.
- [Chen et al., 2022c] Z. Chen, F. Yang, and W. Tao. Detarnet: Decoupling translation and rotation by siamese network for point cloud registration. In AAAI, 2022.
- [Chen et al., 2023a] H. Chen, B. Chen, Z. Zhao, and B. Song. Point cloud registration based on learning gaussian mixture models with global-weighted local representations. IEEE Geosci. Remote Sens. Lett., 20:1-5, 2023.
- [Chen et al., 2023b] S. Chen, H. Xu, R. Li, G. Liu, C. Fu, and S. Liu. Sira-pcr: Sim-to-real adaptation for 3d point cloud registration. In ICCV, 2023.
- [Chen et al., 2023c] Z. Chen, Y. Ren, T. Zhang, Z. Dang, W. Tao, S. Süsstrunk, and M. Salzmann. Diffusionpcr: Diffusion models for robust multi-step point cloud regis- tration. arXiv preprint arXiv:2312.03053, 2023.
- [Chen et al., 2023d] Z. Chen, K. Sun, F. Yang, L. Guo, and W. Tao. Sc 2 -pcr++: Rethinking the generation and selec- tion for efficient and robust boint cloud registration. IEEE TPAMI, 2023.
- [Choi et al., 2015] S. Choi, Q. Zhou, and V. Koltun. Robust reconstruction of indoor scenes. In CVPR, 2015.
- [Curless and Levoy, 1996] B. Curless and M. Levoy. A vol- umetric method for building complex models from range images. In SIGGRAPH, 1996.
- [Deng et al., 2018] H. Deng, T. Birdal, and S. Ilic. Ppf- foldnet: Unsupervised learning of rotation invariant 3d local descriptors. In ECCV, 2018.
- [Deng et al., 2019] H. Deng, T. Birdal, and S. Ilic. 3d local features for direct pairwise registration. In CVPR, 2019.
- [Dong et al., 2020] Z. Dong, F. Liang, B. Yang, Yu. Xu, Y. Zang, J. Li, Y. Wang, W. Dai, H. Fan, J. Hyyppä, and Stilla U. Registration of large-scale terrestrial laser scanner point clouds: A review and benchmark. ISPRS J. Photogramm. Remote Sens., 163:327-342, 2020.
- [Eckart et al., 2018] B. Eckart, K. Kim, and J. Kautz. Hgmr: Hierarchical gaussian mixtures for adaptive 3d registration. In ECCV, 2018.
- [Fischer et al., 2021] K. Fischer, M. Simon, F. Olsner, S. Milz, H. Gross, and P. Mader. Stickypillars: Robust and efficient feature matching on point clouds using graph neural networks. In CVPR, 2021.
- [Fischler and Bolles, 1981] M. Fischler and R. Bolles. Ran- dom sample consensus: a paradigm for model fitting with applications to image analysis and automated cartography. Communications of the ACM, 24(6):381-395, 1981.
- [Geiger et al., 2012] A. Geiger, P. Lenz, and R. Urtasun. Are we ready for autonomous driving? the kitti vision bench- mark suite. In CVPR, 2012.
- [Gojcic et al., 2019] Z. Gojcic, C. Zhou, J. Wegner, and A. Wieser. The perfect match: 3d point cloud matching with smoothed densities. In CVPR, 2019.
- [Gojcic et al., 2020] Z. Gojcic, C. Zhou, J. D Wegner, L. Guibas, and T. Birdal. Learning multiview 3d point cloud registration. In CVPR, 2020.
- [Gu et al., 2020] X. Gu, X. Wang, and Y. Guo. A review of research on point cloud registration methods. In IOP Conf. Ser.: Mater. Sci. Eng., volume 782, page 022070. IOP Publishing, 2020.
- [Huang et al., 2021a] S. Huang, Z. Gojcic, M. Usvyatsov, A. Wieser, and K. Schindler. Predator: Registration of 3d point clouds with low overlap. In CVPR, 2021.
- [Huang et al., 2021b] X. Huang, G. Mei, J. Zhang, and R. Ab- bas. A comprehensive survey on point cloud registration. arXiv preprint arXiv:2103.02690, 2021.
- [Huang et al., 2022a] X. Huang, S. Li, Y. Zuo, Y. Fang, J. Zhang, and X. Zhao. Unsupervised point cloud regis- tration by learning unified gaussian mixture models. IEEE Robotics Autom. Lett., 7(3):7028-7035, 2022.
- [Huang et al., 2022b] X. Huang, W. Qu, Y. Zuo, Y. Fang, and X. Zhao. Gmf: General multimodal fusion framework for correspondence outlier rejection. IEEE Robotics Autom. Lett., 7(4):12585-12592, 2022.
- [Huang et al., 2022c] X. Huang, W. Qu, Y. Zuo, Y. Fang, and X. Zhao. Imfnet: Interpretable multimodal fusion for point cloud registration. IEEE Robotics Autom. Lett., 7(4):12323-12330, 2022.
- [Jiang et al., 2021] H. Jiang, Y. Shen, J. Xie, J. Li, Ji. Qian, and J. Yang. Sampling network guided cross-entropy method for unsupervised point cloud registration. In ICCV, 2021.
- [Jiang et al., 2023] H. Jiang, Z. Dang, Z. Wei, J. Xie, J. Yang, and M. Salzmann. Robust outlier rejection for 3d registra- tion with variational bayes. In CVPR, 2023.
- [Lee et al., 2021] J. Lee, S. Kim, M. Cho, and J. Park. Deep hough voting for robust global registration. In ICCV, 2021.
- [Li et al., 2020a] J. Li, C. Zhang, Z. Xu, H. Zhou, and C. Zhang. Iterative distance-aware similarity matrix con- volution with mutual-supervised point elimination for effi- cient point cloud registration. In ECCV, 2020.
- [Li et al., 2020b] L. Li, S. Zhu, H. Fu, P. Tan, and C. Tai. End-to-end learning local multi-view descriptors for 3d point clouds. In CVPR, 2020.
- [Li et al., 2021] X. Li, J. Pontes, and S. Lucey. Pointnetlk revisited. In CVPR, 2021.
- [Liu et al., 2023] J. Liu, G. Wang, Z. Liu, C. Jiang, M. Polle- feys, and H. Wang. Regformer: An efficient projection- aware transformer network for large-scale point cloud reg- istration. In ICCV, 2023.
- [Lu et al., 2019a] W. Lu, G. Wan, Y. Zhou, X. Fu, P. Yuan, and S. Song. Deepvcp: An end-to-end deep neural network for point cloud registration. In CVPR, 2019.
- [Lu et al., 2019b] W. Lu, Y. Zhou, G. Wan, S. Hou, and S. Song. L3-net: Towards learning based lidar localiza- tion for autonomous driving. In CVPR, 2019.
- [Lu et al., 2021] F. Lu, G. Chen, Y. Liu, L. Zhang, S. Qu, S. Liu, and R. Gu. Hregnet: A hierarchical network for large-scale outdoor lidar point cloud registration. In ICCV, 2021.
- [Lucas and Kanade, 1981] B. Lucas and T. Kanade. An it- erative image registration technique with an application to stereo vision. In IJCAI, 1981. IJCAI
- [Mei et al., 2023a] G. Mei, F. Poiesi, C. Saltori, J. Zhang, E. Ricci, and N. Sebe. Overlap-guided gaussian mixture models for point cloud registration. In WACV, 2023.
- [Mei et al., 2023b] G. Mei, H. Tang, X. Huang, W. Wang, J. Liu, J. Zhang, Van G., and Q. Wu. Unsupervised deep probabilistic approach for partial point cloud registration. In CVPR, 2023.
- [Pais et al., 2020] G. Pais, S. Ramalingam, V. Govindu, J. Nascimento, R. Chellappa, and P. Miraldo. 3dregnet: A deep neural network for 3d point registration. In CVPR, 2020.
- [Poiesi and Boscaini, 2022] F. Poiesi and D. Boscaini. Learn- ing general and distinctive 3d local deep descriptors for point cloud registration. IEEE TPAMI, 45(3), 2022.
- [Pomerleau et al., 2012] F. Pomerleau, M. Liu, F. Colas, and R. Siegwart. Challenging data sets for point cloud regis- tration algorithms. The International Journal of Robotics Research, 31(14):1705-1711, 2012.
- [Qi et al., 2017] C. Qi, H. Su, K. Mo, and L. Guibas. Point- net: Deep learning on point sets for 3d classification and segmentation. In CVPR, 2017.
- [Qin et al., 2023] Z. Qin, H. Yu, C. Wang, Y. Guo, Y. Peng, S. Ilic, D. Hu, and K. Xu. Geotransformer: Fast and robust point cloud registration with geometric transformer. IEEE TPAMI, 45(8):9806-9821, 2023.
- [Sarode et al., 2019] V. Sarode, X. Li, H. Goforth, Y. Aoki, R. Srivatsan, and S. Lucey. Pcrnet: Point cloud regis- tration network using pointnet encoding. arXiv preprint arXiv:1908.07906, 2019.
- [Shen et al., 2022] Y. Shen, L. Hui, H. Jiang, J. Xie, and J. Yang. Reliable inlier evaluation for unsupervised point cloud registration. In AAAI, 2022.
- [Sun et al., 2023] X. Sun, W. Li, J. Huang, D. Chen, and T. Jia. Research and application on cross-source point cloud registration method based on unsupervised learning. In CYBER, 2023.
- [Uy et al., 2019] M. Uy, Q. Pham, B. Hua, T. Nguyen, and S. Yeung. Revisiting point cloud classification: A new benchmark dataset and classification model on real-world data. In ICCV, 2019.
- [Vaswani et al., 2017] A. Vaswani, N. Shazeer, N. Parmar, J. Uszkoreit, L. Jones, A. Gomez, L. Kaiser, and I. Polo- sukhin. Attention is all you need. In NeurIPS, 2017.
- [Wang and Solomon, 2019a] Y. Wang and J. Solomon. Deep closest point: Learning representations for point cloud reg- istration. In ICCV, 2019.
- [Wang and Solomon, 2019b] Y. Wang and J. Solomon. Prnet: Self-supervised learning for partial-to-partial registration. In NeurIPS, 2019.
- [Wang et al., 2022a] H. Wang, Y. Liu, Z. Dong, and W. Wang. You only hypothesize once: Point cloud registration with rotation-equivariant descriptors. In ACM MM, 2022.
- [Wang et al., 2022b] Y. Wang, C. Yan, Y. Feng, S. Du, Q. Dai, and Y. Gao. Storm: Structure-based overlap matching for partial point cloud registration. IEEE TPAMI, 45(1):1135- 1149, 2022.
- [Wang et al., 2023a] H. Wang, Y. Liu, Z. Dong, Y. Guo, Y. Liu, W. Wang, and B. Yang. Robust multiview point cloud registration with reliable pose graph initialization and history reweighting. In CVPR, 2023.
- [Wang et al., 2023b] H. Wang, Y. Liu, Q. Hu, B. Wang, J. Chen, Z. Dong, Y. Guo, W. Wang, and B. Yang. Roreg: Pairwise point cloud registration with oriented descriptors and local rotations. IEEE TPAMI, 45(8), 2023.
- [Wu et al., 2015] Z. Wu, S. Song, A. Khosla, F. Yu, L. Zhang, and J. Tang, X.and Xiao. 3d shapenets: A deep represen- tation for volumetric shapes. In CVPR, 2015.
- [Wu et al., 2021] B. Wu, J. Ma, G. Chen, and P. An. Feature interactive representation for point cloud registration. In ICCV, 2021.
- [Xu et al., 2021] H. Xu, S. Liu, G. Wang, G. Liu, and B. Zeng. Omnet: Learning overlapping mask for partial-to-partial point cloud registration. In ICCV, 2021.
- [Xu et al., 2022] H. Xu, N. Ye, G. Liu, B. Zeng, and S. Liu. Finet: Dual branches feature interaction for partial-to- partial point cloud registration. In AAAI, 2022.
- [Yang et al., 2022] F. Yang, L. Guo, Z. Chen, and W. Tao. One-inlier is first: Towards efficient position encoding for point cloud registration. In NeurIPS, 2022.
- [Yew and Lee, 2020] Z. Yew and G. Lee. Rpm-net: Robust point matching using learned features. In CVPR, 2020.
- [Yew and Lee, 2022] Z. Yew and G. Lee. Regtr: End-to-end point cloud correspondences with transformers. In CVPR, 2022.
- [Yu et al., 2023a] H. Yu, Z. Qin, J. Hou, M. Saleh, D. Li, B. Busam, and S. Ilic. Rotation-invariant transformer for point cloud matching. In CVPR, 2023.
- [Yu et al., 2023b] J. Yu, L. Ren, Y. Zhang, W. Zhou, L. Lin, and G. Dai. Peal: Prior-embedded explicit attention learn- ing for low-overlap point cloud registration. In CVPR, 2023.
- [Yuan et al., 2020] W. Yuan, B. Eckart, K. Kim, V. Jampani, D. Fox, and J. Kautz. Deepgmr: Learning latent gaussian mixture models for registration. In ECCV, 2020.
- [Zeng et al., 2017] A. Zeng, S. Song, M. Nießner, M. Fisher, J. Xiao, and T. Funkhouser. 3dmatch: Learning local ge- ometric descriptors from rgb-d reconstructions. In CVPR, 2017.
- [Zhang et al., 2020] Z. Zhang, Y. Dai, and J. Sun. Deep learn- ing based point cloud registration: an overview. Virtual Real. Intell. Hardw., 2(3):222-246, 2020.
- [Zhang et al., 2021] Z. Zhang, J. Sun, Y. Dai, D. Zhou, X. Song, and M. He. A representation separation perspec- tive to correspondence-free unsupervised 3-d point cloud registration. IEEE Geosci. Remote Sens. Lett., 19:1-5, 2021.
- [Zhang et al., 2022a] Y. Zhang, Z. Sun, Z. Zeng, and K. Lam. Partial point cloud registration with deep local feature. IEEE TAI, 4(5):1317-1327, 2022.
- [Zhang et al., 2022b] Y. Zhang, Z. Sun, Z. Zeng, and K. Lam. Point cloud registration using multiattention mechanism and deep hybrid features. IEEE Intell. Syst., 38(1):58-68, 2022.
- [Zhang et al., 2022c] Y. Zhang, J. Yu, X. Huang, W. Zhou, and J. Hou. Pcr-cg: Point cloud registration via deep ex- plicit color and geometry. In ECCV, 2022.
- [Zhang et al., 2023a] X. Zhang, J. Yang, S. Zhang, and Y. Zhang. 3d registration with maximal cliques. In CVPR, 2023.
- [Zhang et al., 2023b] Z. Zhang, W. Sun, X. Min, Q. Zhou, J. He, Q. Wang, and G. Zhai. Mm-pcqa: Multi-modal learning for no-reference point cloud quality assessment. In IJCAI, 2023. IJCAI
- [Zhou et al., 2018] L. Zhou, S. Zhu, Z. Luo, T. Shen, R. Zhang, M. Zhen, T. Fang, and L. Quan. Learning and matching multi-view descriptors for registration of point clouds. In ECCV, 2018.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
With the progress of sensor technology, acquiring highprecision point cloud data has become more accessible and prevalent [Zhang et al., 2023b; Uy et al., 2019]. Point cloud registration (PCR), as a pivotal tool in point cloud data processing, aims to align the point cloud data with a common coordinate system, enabling precise three-dimensional (3D) modeling [Qin et al., 2023; Liu et al., 2023]. This registration process establishes a dependable foundation for point cloud analysis and various applications [Huang et al., 2021b].
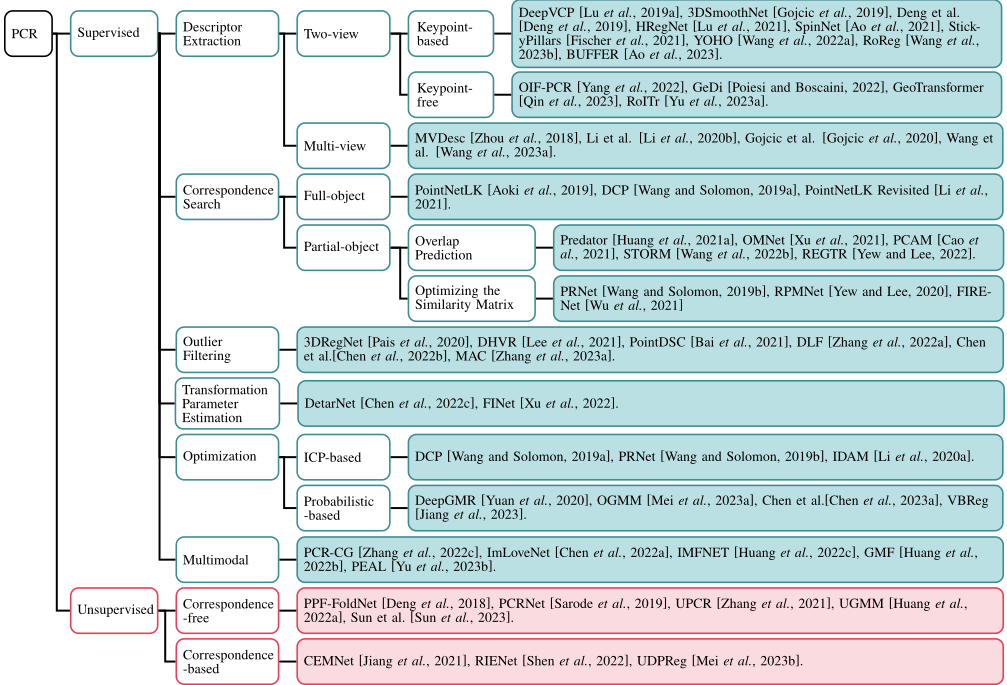
Given the rapid advancements in this field, hundreds of deep learning (DL)-based methods have been proposed. There is an urgent need for thorough investigations to both inspire and steer future research endeavors. To address this necessity, we develop a comprehensive survey and establish a detailed taxonomy of PCR algorithms. This study categorizes these algorithms into two types: supervised and unsupervised. Supervised registration, leveraging labeled data that typically encompasses known transformations between point clouds, orchestrates the training process. In contrast, unsupervised registration hinges on the intrinsic geometric properties of the point clouds, independent of external labels. For supervised algorithms, the taxonomy is segmented into four crucial stages and two overarching concepts. The four stages include descriptor extraction, correspondence search, outlier filtering, and transformation parameter estimation, while the two concepts encompass optimization and multimodal. The supervised algorithms are systematically categorized based on their contributions to every stage or integration of concepts. Furthermore, for unsupervised algorithms, our taxonomy differentiates between two methodologies: the correspondencefree approaches, which align point clouds by minimizing feature discrepancies, and the correspondence-based approaches, which align point clouds by establishing correspondences. Goals of our survey. We aim to (i) classify commonly used datasets and metrics in PCR tasks; (ii) develop a taxonomy for DL-based registration algorithms, introducing core techniques employed across various methods; and (iii) identify open issues that could stimulate further research in PCR tasks. The differences between our survey and others. [Gu et al., 2020] only review traditional PCR methods, DL-based methods are not involved. [Zhang et al., 2020] and [Huang et al., 2021b] conduct a summary of DL-based PCR methods. However, recent advances in unsupervised methods are not elaborated. Additionally, they did not provide a comprehensive overview of the latest research developments in the PCR field. To address these gaps, we conduct a comprehensive survey and taxonomy of DL-based supervised and unsupervised PCR methods. The taxonomy is summarized in Figure 1, providing a clear and structured overview of the PCR.
∗ Corresponding Author
2 RelatedWork
2.1 Definition
The goal of PCR is to find the optimal rotation R∗ and translation t∗ parameters that align source point cloud X ∈ R 𝑁×3 and target point cloud Y ∈ R 𝑀×3 . Here, 𝑁 and 𝑀 represent the number of points in X and Y , respectively. The mathematical objective of the PCR process is formulated by
where x𝑝, y𝑝 ∈ R 1×3 are the p-th points in X and Y , while 𝑃 denotes the number of correspondences between X and Y .
2.2 Datasets
Datasets for PCR can be broadly classified into two categories: artificially synthesized and acquired through real instruments. Each category exhibits unique characteristics and has different levels of applicability in PCR tasks. Synthesized point cloud datasets are typically composed of virtual models created by using computer graphics techniques to replicate real-world environments. These datasets contain the object-level ModelNet40 [Wu et al., 2015] and ShapeNet [Chang et al., 2015], which consist of data generated through computer-aided design, as well as the scene-level dataset ICL-NUIM [Choi et al., 2015] and FlyingShapes [Chen et al., 2023b].
However, while synthetic data are beneficial for certain applications, they often lack the complexity and variability found in real-world scenarios. Consequently, incorporating real-world data into training and validation processes is essential for obtaining robust algorithms. Datasets comprising realistic point cloud data include Stanford [Curless and Levoy, 1996], ETH [Pomerleau et al., 2012], KITTI [Geiger et al., 2012], Apollo-SouthBay [Lu et al., 2019b], ScanObjectNN [Uy et al., 2019], and WHU-TLS [Dong et al., 2020]. Furthermore, there is a 3DMatch [Zeng et al., 2017] dataset that comprises both synthesized and realistic scans. The attributes of various datasets are summarized in Table 1.
2.3 Metrics
Metrics play a pivotal role in evaluating and comparing the results of point cloud registration, aiding in the selection of optimal parameters. Consequently, the choice of an appropriate metric is vital for accurately assessing the quality of a registration algorithm. We categorize evaluation metrics based on their application scenarios. For object-level point clouds, the commonly employed metrics include root mean squared error, mean squared error, mean isotropic error, mean absolute error, Chamfer distance (CD), and coefficient of determination. For scene-level point clouds, the typical metrics are registration recall, inlier ratio, feature matching recall, relative rotation error, and relative translation error.
3 Supervised Point Cloud Registration
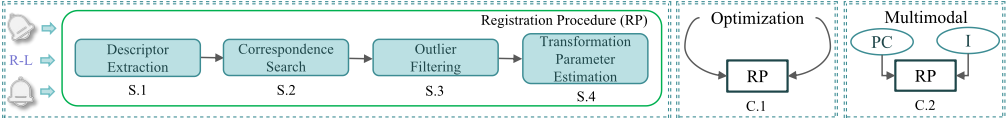
Supervised models for PCR typically rely on various forms of supervisory signals, such as ground-truth labels or transformation parameters, to guide the training process. To facilitate research on DL-based supervised methods, this section provides a structured categorization of the principal contributions made by various supervised algorithms across four key stages and two fundamental concepts. Such a taxonomy not only elucidates valuable technologies but also presents registration methods in a clear and concise manner. The four steps and two concepts of the supervised registration algorithm are shown in Figure 2. It is worth noting that not every algorithm framework contains the four steps and involves these two concepts.
| Dataset | Type | Number | S/O |
|---|---|---|---|
| Stanford [Curless and Levoy, 1996] ETH [Pomerleau et al., 2012] KITTI [Geiger et al., 2012] ModelNet40 [Wu et al., 2015] ShapeNet [Chang et al., 2015] ICL-NUIM [Choi et al., 2015] 3DMatch [Zeng et al., 2017] Apollo-SouthBay [Lu et al., 2019b] ScanObjectNN [Uy et al., 2019] WHU-TLS [Dong et al., 2020] | Real Real Real Syn Syn Syn Real Real Real | 10 36 22 12311 55000+ 8 62 6 15000+ 115 | O S S O S S S S |
| O | |||
| Syn&Real | |||
| O | |||
| FlyingShapes [Chen et al., 2023b] | Syn | 200 | S |
3.1 Descriptor Extraction
In PCR tasks, descriptors are essential, and markedly influence the discriminability of features. Here, we describe the PCR algorithms that mainly contribute to descriptor extraction from two perspectives, which are two-view and multi-view algorithms.
Two-view. The first perspective involves two-view registration, which emerges as the prevalent approach in the field of PCR. We further classify these methods into two categories: keypoint-based and keypoint-free.
Keypoint-based needs to detect significant keypoints to obtain robust feature descriptors. To facilitate comprehension, this category is further segmented based on the type of input data employed, including points, patches, and voxel grids.
Firstly, points, serving as the fundamental elements of point clouds, are discrete and unlinked 3D entities. Consequently, extracting descriptors from points typically necessitates the construction of intricate local relationships. In DeepVCP [Lu et al., 2019a], point weighting is incorporated into an end-toend registration network to estimate point saliency scores, enabling the detection of keypoints. Subsequently, the 𝐾-nearest neighbors method is employed to establish neighborhoods around the keypoints, followed by a permutation-invariant network to extract more detailed descriptors. HRegNet [Lu et al., 2021] is a hierarchical network that leverages geometric features, descriptors, and similarity measures obtained through bilateral consensus and neighborhood consensus to establish correspondence between keypoints. The principles of bilateral consensus and neighborhood consensus suggest that within descriptor space, two correct corresponding points should not only be the nearest neighbors of each other but also exhibit similar neighborhoods. BUFFER [Ao et al., 2023] designs a point-wise learner to enhance computational efficiency and feature representation capabilities by predicting keypoints and estimating point orientations.
Secondly, patches can directly represent the local neighborhood structure. In [Deng et al., 2019], point cloud-FoldNet and point pair features-FoldNet are utilized to extract keypoints from the point cloud patch and obtain permutationinvariant descriptors. Additionally, a new pose estimation method in [Deng et al., 2019] is proposed that achieves faster and more robust results than random sample consensus (RANSAC) [Fischler and Bolles, 1981]. StickyPillars [Fischer et al., 2021] integrates keypoint detection and descriptor extraction by jointly learning pixel-level and pointlevel feature descriptors. YOHO [Wang et al., 2022a] and RoReg [Wang et al., 2023b] employ advanced group equivariant feature learning techniques to achieve rotation invariance, enhancing robustness against variations in point density and noise. Furthermore, the rotation-equivariant component in YOHO and RoReg allows for estimation with just a single correspondence hypothesis, greatly reducing the search space for possible transformations.
Thirdly, voxel grids can achieve uniform sampling of point clouds by adopting grids of different, customizable sizes. 3DSmoothNet [Gojcic et al., 2019] adopts a voxelized smoothed density value technique, incorporating fully convolutional layers to model the local morphology of point clouds. It scrutinizes the local density estimates to accomplish PCR. SpinNet [Ao et al., 2021] eliminates rotational variances by aligning with a reference axis and further reduces them through spherical voxelization and coordinate transformations. It then transforms point clouds into a manageable cylindrical volume and generates representative feature descriptors using cylindrical convolution layers.
Keypoint-free involves considering all potential correspondences rather than detecting critical points. Within this perspective, there exist methods that utilize deep neural networks to directly obtain descriptors that encapsulate vital information. Subsequently, these descriptors are fed into a dedicated module responsible for estimating the transformation parameters. GeDi [Poiesi and Boscaini, 2022] operates by normalizing the local reference frame of the point cloud patch and then encoding it into the descriptors using a deep neural network. These descriptors are invariant to scale and rotation, making them effective for PCR across different application domains.
Other methodologies adopt a coarse-to-refine scheme, in which the matching outcomes are significantly influenced by the descriptors obtained in the initial coarse stage [Qin et al., 2023]. GeoTransformer [Qin et al., 2023] encodes the distance and angle information into the transformation representation, enabling effective capture of the geometric structure within individual point clouds and revealing the geometric consistency among the point clouds to be registered. From the viewpoint of considering point-wise and structure, OIF-PCR [Yang et al., 2022] employs an efficient and precise positional encoding strategy during the coarse stage, leveraging a limited number of correspondences. Simultaneously, a joint optimization approach is utilized to optimize the position encoding, progressively refining the point cloud features and reducing the reliance on initialization. RoITr [Yu et al., 2023a] introduces an aggregation module using a rotation invariant Transformer [Vaswani et al., 2017], which is strategically inserted between the encoder and decoder components. Its purpose is to facilitate the extraction of discriminative descriptors that are pose-agnostic and cross-frame position awareness.
Keypoint-based methods achieve precise matching with keypoint detection but face generalization challenges and are less efficient. Moreover, keypoint-free methods are robust in sparse, low-overlap point clouds but may lack detail accuracy.
Multi-view. The second perspective involves fusing information from multi-view. MVDesc [Zhou et al., 2018] develops a multi-view local descriptor, which is derived from images captured from various viewpoints, specifically for characterizing the 3D keypoints. Subsequently, MVDesc advances a robust matching technique, aimed at rejecting outlier correspondences through efficient belief propagation inference within a defined graphical model. Li et al. [Li et al., 2020b] integrate multi-view rendering into a neural network through a differentiable renderer, allowing the viewpoint to be an optimizable parameter for capturing more informative local context around the interest points. To obtain distinctive descriptors, Li et al. also design a soft view pooling module for fusing convolutional features from different views. Gojcic et al. [Gojcic et al., 2020] utilize iteratively reweighted least squares (IRLS) as a global refinement technique to address the cycle consistency and alleviate the ambiguity of initial alignment in multi-view scanning. However, this approach relies on dense pairwise correspondences, which introduces significant computational overhead and increases the presence of outliers. Consequently, it becomes challenging for IRLS to accurately estimate the correct pose.
To address these limitations, Wang et al. [Wang et al., 2023a] propose a novel approach. They primarily concentrate on learning reliable initialization methods that consider the overlap between multiple point cloud pairs. This enables the construction of sparse yet reliable pose graphs. Furthermore, a history reweighting function is integrated into the IRLS framework, augmenting its generalization and robustness.
3.2 Correspondence Search
Recently, research has emerged for predicting correspondences between point clouds to be registered. These methods follow an end-to-end manner and often utilize existing point cloud feature extraction methods directly. Specifically, we further classify it into two categories according to the registration objects: full-object and partial-object.
Full-object. The initial category involves full-object PCR, where each point is capable of identifying a unique counterpart in another point cloud. To address this problem, PointNetLK [Aoki et al., 2019] and PointNetLK Revisited [Li et al., 2021], leverage the permutation-invariant network PointNet [Qi et al., 2017] as adaptable imaging functions and integrate them into a recurrent Lucas-Kanade [Lucas and Kanade, 1981] framework. DCP [Wang and Solomon, 2019a] employs graph convolutional neural network and Transformer [Vaswani et al., 2017] modeling to obtain feature representations and capture contextual information. Subsequently, the pointer generation mechanism is employed to estimate the correspondences.
Partial-object. The second category involves partial-object PCR, where not every point has a corresponding point in the other point cloud. Given the common scenario where only a subset of the point clouds to be registered exhibits correspondences, numerous noteworthy studies have emerged in the field of partial-to-partial PCR. These studies have a specific focus on overlap prediction and optimizing the similarity matrix accordingly.
Overlap prediction refers to estimating the overlap region between point clouds to be registered, and then directly finding correspondences in this region. To the best of our knowledge, Predator [Huang et al., 2021a] is the pioneering model that introduces the concept of overlapping region prediction. Predator utilizes a joint encoder and decoder architecture, wherein a graph neural network and an overlap attention module are sequentially applied to enhance contextual relationships and predict the overlap score, respectively. Notably, the overlap attention module facilitates early-stage information interaction in the framework, which positively impacts the estimation of overlapping regions.
With reference to the above concept of information interaction, several approaches are proposed. OMNet [Xu et al., 2021] introduces an innovative mask prediction module that possesses the capability to efficiently generate accurate overlapping masks. Moreover, OMNet establishes a direct connection between the intermediate layers of the mask prediction module and the transformation regression. This connection enables the simultaneous optimization of both the generation of overlapping masks and the estimation of transformation parameters. PCAM [Cao et al., 2021] employs cross-attention matrices (CAM) to achieve feature augmentation. The CAM facilitates simultaneous focus on both shallow geometric information and deep contextual information, enabling the generation of more reliable matching features in overlapping regions.
In addition, several methods enhance the prediction of overlapping regions by employing the Transformer for global modeling. STORM [Wang et al., 2022b] incorporates a differential sampling overlapping prediction module into dual Transformer [Vaswani et al., 2017] layers, which facilitates information exchange between the before and after prediction phases. It employs a dedicated layer that iteratively applies the Gumbel-softmax technique, allowing for the independent sampling of points situated within overlapping regions. REGTR [Yew and Lee, 2022] leverages a main architecture composed of Transformer layers, which incorporate both selfattention and cross-attention mechanisms. These layers are proficient in facilitating the extraction of meaningful and enhanced features. Such an architectural selection empowers the network to accurately predict the probability of each point's presence in overlapping regions and determine their corresponding positions in another point cloud.
Optimizing the similarity matrix is a crucial aspect of finegrained correspondence searching. The elements of the similarity matrix indicate the probability of correspondence between individual point pairs. Typically, a probability function is employed to compute the similarity matrix, followed by selecting the maximum value in each row or column to determine the most probable point pairs [Wang and Solomon, 2019a]. While softmax is frequently used as the probability function, it tends to produce a blurry correspondence map. To address this issue, numerous studies have emerged to mitigate the ambiguity. PRNet [Wang and Solomon, 2019b] applies the Gumbel-softmax technique to obtain the similarity matrix, a method that finds hard correspondences and alleviates the ambiguity in correspondence search. In addition, to enhance the sharpness of the resultant similarity matrix, a temperature parameter is introduced into the Gumbel-softmax, which can be iteratively adjusted. RPMNet [Yew and Lee, 2020] incorporates the optimal transport layer and annealing to learn a similarity matrix from a hybrid feature composed of spatial coordinates and geometric properties. FIRE-Net [Wu et al., 2021] facilitates feature interactions across various hierarchical levels of point clouds. Initially, FIRE-Net extracts structural features from the point cloud and fosters the interchange of feature information. This process permits points with high feature similarity to effectively perceive each other.
Notably, full-object registration methods are impractical in real-world scenarios, as the point clouds subject to registration typically represent subset matches. The introduction of partial-object registration algorithms addresses this limitation, aligning more closely with practical requirements.
3.3 Outlier Filtering
In PCR, outliers are defined as points lacking a corresponding counterpart. The principal objective of outlier filtering is to meticulously remove these outliers. Given their substantial influence on the outcomes of registration processes, the effective elimination of outliers is imperative to guarantee both robustness and accuracy. To identify outliers, 3DRegNet [Pais et al., 2020] utilizes a deep neural network to estimate the probability of a point being classified as an outlier, which effectively minimizes the influence of hypothetical outliers during the registration procedure. DHVR [Lee et al., 2021] places the initially predicted correspondences into a Hough voting module. This module casts votes in a deliberately sparse transformation parameter space, enhancing the accurate identification of inliers. Moreover, DLF [Zhang et al., 2022a] utilizes a classifier that combines the stacked orderaware modules to evaluate hypothesized outliers and determine the compatibility of hypothesized inliers.
The above methods directly estimate outliers after extracting features. However, during the feature extraction phase, they predominantly rely on methods like multilayer perceptron, inadvertently overlooking the critical aspect of the 3D spatial information. Furthermore, in classifying these features, each pair is assessed separately, ignoring the important consistency of inliers [Bai et al., 2021]. Based on the above thinking, PointDSC [Bai et al., 2021] is proposed, which explicitly exploits the spatial compatibility inherently constructed by distance. It argues that not only should the relative distances of inliers between the point clouds to be registered remain consistent, but there also exists an inherent relationship among inliers within the single point cloud. Based on spatial compatibility, a second order spatial compatibility [Chen et al., 2022b] is proposed, which begins by converting the spatial compatibility matrix into a binary form and then calculates the similarity between two corresponding points based on the count of their mutually compatible points. This approach focusing on global rather than local compatibility, enhances early-stage differentiation between inliers and outliers. MAC [Zhang et al., 2023a] loosens the maximum clique constraint and mines more local consistency information in the compatibility graph for accurate pose hypothesis generation.
3.4 Transformation Parameter Estimation
The calculation of transformation parameters serves as the final step in PCR, with the widely adopted methods including RANSAC [Fischler and Bolles, 1981] and singular value decomposition (SVD) [Arun et al., 1987]. RANSAC is commonly employed during the coarse registration stage to mitigate the impact of outliers, and it requires a predetermined number of iterations to solve. Unlike RANSAC, SVD does not necessitate an iterative solution. It estimates the transformation parameters directly based on the pose difference between the two point clouds, thus requiring a reliable feature extraction network for accurate results [Zhang et al., 2022b]. The process of solving SVD reveals that the rotation matrix is computed prior to the calculation of the translation vector.
With the development of DL, some approaches strive to solve both rotation matrix and translation vector simultaneously using convolutional neural network [Deng et al., 2018; Pais et al., 2020]. The effectiveness of this idea is examined across multiple models. However, simultaneous resolution of transformation parameters can lead to mutual interference [Chen et al., 2022c]. To address this issue, DetarNet [Chen et al., 2022c] employs Siamese networks to independently decouple transformation parameters in a two-step process. Initially, a regression network computes the translation vector, followed by the utilization of SVD to determine the rotation matrix. FINet [Xu et al., 2022] leverages point-wise and global features to enhance information association between point clouds to be registered at multiple stages. At the same time, a dual-branch structure containing a rotation regression branch and a translation regression branch is designed to predict the rotation matrix and translation vector, respectively.
3.5 Optimization
Approaches to PCR optimization focus on enhancing the entire process. Based on the principles of their optimization, we divide them into two main categories: iterative closest point (ICP)-based methods and probability-based methods.
ICP-based. While the classical ICP algorithmmay be less effective than DL-based algorithms for PCR tasks, it still offers valuable advantages worth exploring. One such advantage is its iterative optimization thought, which has been widely adopted in various methods to refine estimation transformation parameters. In DCP [Wang and Solomon, 2019a] and PRNet [Wang and Solomon, 2019b], the entire network follows an iterative process to enhance the initial prediction of the rotation matrix and translation vector, progressively refining them from a coarse to a fine level. More specifically, before each iteration, the point cloud to be registered is updated with the transformation parameters estimated in the previous iteration. This incremental refinement process allows for the gradual improvement of the predicted transformation parameters. Contrasting with the previously discussed algorithms that iterate through the entire network, IDAM [Li et al., 2020a] distinctively positions the feature extraction component outside the iterative loop, which reduces the computational burden to a certain extent. Furthermore, it integrates distance information into the iterative network and incorporates a two-stage point elimination module. This design effectively filters out points that are detrimental to the registration process.
Probabilistic-based. Probability-based PCR algorithms integrate probabilistic knowledge within the registration framework to enhance the optimization process. These algorithms typically utilize probabilistic models to depict the matching relationship and inherent uncertainty between point clouds to be registered.
As a commonly used probability model, the Gaussian mixture model (GMM) finds optimal alignments by integrating an expectation-maximization (EM) method into a maximum likelihood framework [Eckart et al., 2018]. However, the EM process can be computationally intensive and potentially lead to incorrect data associations, especially in registrations with significant angular disparities [Yuan et al., 2020]. To address the aforementioned challenges, a technique called deep Gaussian mixture registration (DeepGMR) [Yuan et al., 2020] is proposed, which leverages a neural network to search correspondences between points and GMM parameters. Furthermore, two differentiable modules are employed to estimate the optimal transformation parameters. OGMM [Mei et al., 2023a] utilizes predictions of the overlapping area between two input point clouds for GMM estimation, framing the registration task as minimizing the variance between the two GMMs. In [Chen et al., 2023a], GMM is formulated as a distribution that encompasses comprehensive representation capabilities, incorporating both global and local information.
In addition to GMM, the Bayesian probabilistic model is also utilized for PCR. VBReg [Jiang et al., 2023] introduces a variable non-local network architecture, which employs variational Bayesian inference for non-local feature learning. This approach enables the modeling of Bayesian-driven long-range dependencies and facilitates the acquisition of discriminative feature representations for inlier/outlier.
3.6 Multimodal
The original point cloud inherently possesses valuable structural information, which is crucial for accurate representation and analysis. The primary objective of current multimodal algorithms is to augment this structural data by incorporating texture information derived from images.
PCR-CG [Zhang et al., 2022c] and PEAL [Yu et al., 2023b] employ a two-dimensional (2D) image matching technique to establish 2D correspondences, which are then projected onto point clouds using a 2D to 3D projection module, facilitating the identification of overlapping regions. ImLoveNet [Chen et al., 2022a] also utilizes images to enhance predictions in overlapping regions, directly employing cross-fusion technology to amalgamate the 3D features extracted directly from point clouds with the 3D features simulated from two-dimensional features derived from images. IMFNET [Huang et al., 2022c] proposes an interpretable module to explain the contribution of the original points to the final descriptor. This approach significantly enhances both the transparency and effectiveness of the descriptor. GMF [Huang et al., 2022b] integrates texture and structural information through a cross-attention fusion layer. Additionally, it incorporates a convolutional position encoding layer, which is instrumental in accentuating distinctions and focusing on neighboring information. Consequently, these enhancements contribute to improving correspondence quality and standard accuracy in the model.
4 Unsupervised Point Cloud Registration
While supervised PCR algorithms demonstrate favorable outcomes, their success heavily depends on an extensive set of ground-truth transformations or correspondences as supervision signals during the model training process. Needless to say, acquiring such annotated data in real-world settings is often both challenging and costly, which limits the practical application scope of these supervised registration algorithms. Consequently, unsupervised PCR algorithms are explored. In this section, we divide unsupervised algorithms into two categories: correspondence-free and correspondence-based.
4.1 Correspondence-free
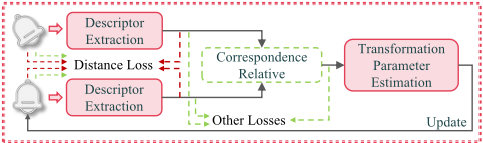
In general, correspondence-based unsupervised methods first extract global features from the source and target point clouds and then minimize the difference between them to regress the transformation parameters. As depicted in Figure 3, these algorithms utilize the calculation of the distance between point clouds to define the loss function, termed distance loss. Typically, distance loss in the unsupervised methods uses CD, which measures the distance or feature differences between point pairs in two point clouds bidirectionally, formulated as
In the field of correspondence-free unsupervised methods, an early significant contribution is PPF-FoldNet [Deng et al., 2018], which starts by constructing four-dimensional (4D) point-pair features. These features are subsequently fed into an end-to-end architecture resembling a folded network, utilizing an encoder-decoder structure for reconstruction. The loss function involves comparing the CD between the 4D point pair features before and after reconstruction. Sun et al. [Sun et al., 2023] have further developed the PointNetLK algorithm for use in cross-source PCR, employing global features for CD calculation. UGMM [Huang et al., 2022a] presents a novel approach, redefining the PCR challenge as a clustering problem and estimating posterior probabilities through unsupervised learning. This method uses the CD between Gaussian mixtures derived from the point clouds as the loss function. UPCR [Zhang et al., 2021] introduces dual point cloud representations: pose-invariant and pose-related. The pose-related representations are leveraged to learn relative poses, which are essential for deriving transformation parameters. Moreover, the CD is also integrated into the loss function to evaluate the discrepancy between the source point cloud and the target point cloud. PCRNet [Sarode et al., 2019], while following a similar approach as UPCR in designing its loss function, distinguishes itself by utilizing the earth mover's distance.
4.2 Correspondence-based
Compared with the correspondence-free unsupervised method, the correspondence-based unsupervised method first extracts features, and then uses the correspondence relative step in Figure 3 (including correspondence search or outlier filtering) to establish point-level, distribution-level, or clusterlevel correspondences. Finally, the rigid transformation parameters are estimated from these correspondences. CEMNet [Jiang et al., 2021] integrates the scaling estimator into the function that measures the registration error to weaken the negative impact of outliers on registration accuracy. CEMNet also uses CD as the loss function.
In addition to CD, correspondence-based unsupervised algorithms also designed various other losses to refine aligned point clouds. RIENet [Shen et al., 2022] proposes a reliable inlier estimation module and designs the neighborhood consensus loss and spatial consistency loss to reduce the local differences and global differences of the point cloud to be registered. UDPReg [Mei et al., 2023b] finds correspondences from cluster-level and point-level, and designs selfconsistency loss, cross-consistency loss, and local contrastive loss to enable unsupervised learning.
5 Challenges and Opportunities
Impressive outcomes have been yielded by the existing DLbased PCR algorithms. Here, we attempt to highlight the existing issues and identify open questions that may serve as a catalyst for future research.
- Towards realistic data generation: A major challenge is bridging the gap between synthetic and real-world data. Most methods often rely on Gaussian noise to mimic realistic data, which fails to capture the complexity of actual data. Chen et al. [Chen et al., 2023c] propose a new perspective that introduces the diffusion model to generate noisy data. Future research can focus on integrating other generative models to simulate noise and occlusions, or developing data generation methods that can simulate realistic data independently of external networks.
- Abundant multimodal information: Current multimodal PCR algorithms enhance feature representation by fusing image textures, which contributes to more accurate and detailed mapping. Future research could further enrich registration algorithms by integrating additional modalities information such as (i) topologically informed meshes, which offer advanced structural data, and (ii) semantic-level text labels embedded in large models, which provide contextual insights.
- Designing new metrics: [Chen et al., 2023d] designed a new metric that effectively achieves dual optimization in processing speed and registration accuracy. This advancement not only enhances the performance of existing registration networks but also opens new perspectives for PCR tasks. Future research can explore innovative evaluation metrics that comprehensively consider factors such as runtime speed, model size, and registration quality.
- Exploiting pre-trained models: Many PCR algorithms are oriented towards the registration process to enhance the performance of registration. However, the integration of pre-trained models remains largely unexplored. Future research can (i) adapt existing pre-trained models for point cloud data, which could considerably reduce the data volume and computational resources needed for training models from scratch, and (ii) leverage features from pre-trained models, originally developed for other tasks, and apply them to PCR tasks, potentially leading to significant advancements and high efficiency.
6 Conclusion
This paper provides a comprehensive survey and taxonomy of theDL-basedPCRalgorithms. First, commonly used datasets and metrics are classified. Then, supervised and unsupervised registration algorithms are organized and analyzed from different technical perspectives. Finally, the issues worthy of attention in the future research of PCR are pointed out.
Acknowledgments
This work was supported in part by the grant of the National Science Foundation of China under Grant 62172090. We thank the Big Data Computing Center of Southeast University for providing the facility support in this paper.
@inproceedings{ijcai2024p922,
  title     = {A Comprehensive Survey and Taxonomy on Point Cloud Registration Based on Deep Learning},
  author    = {Zhang, Yu-Xin and Gui, Jie and Cong, Xiaofeng and Gong, Xin and Tao, Wenbing},
  booktitle = {Proceedings of the Thirty-Third International Joint Conference on
               Artificial Intelligence, {IJCAI-24}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Kate Larson},
  pages     = {8344--8353},
  year      = {2024},
  month     = {8},
  note      = {Survey Track},
  doi       = {10.24963/ijcai.2024/922},
  url       = {https://doi.org/10.24963/ijcai.2024/922},
}
TY - CPAPER TI - A Comprehensive Survey and Taxonomy on Point Cloud Registration Based on Deep Learning AU - Zhang, Yu-Xin AU - Gui, Jie AU - Cong, Xiaofeng AU - Gong, Xin AU - Tao, Wenbing T2 - Proceedings of the Thirty-Third International Joint Conference on Artificial Intelligence, IJCAI-24 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2024 SP - 8344 EP - 8353 DO - 10.24963/ijcai.2024/922 UR - https://doi.org/10.24963/ijcai.2024/922 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





