
RoboVineSim: A Simulation Tool for Human-Robot Collaboration in Vineyard Harvesting
Proceedings of the Thirty-Fifth International Joint Conference on Artificial Intelligence. Demo Track. Pages 8543-8546.
https://doi.org/10.24963/ijcai.2026/999
Keywords
- AI: Agent-based and Multi-agent Systems
- AI: Multidisciplinary Topics and Applications
- AI: Constraint Satisfaction and Optimization
Abstract
In agricultural tasks, manual grape harvesting remains a labor-intensive activity facing challenges of efficiency, labor shortages, and sustainability. To this end, tailor-made robotic systems have been designed with the capabilities to transfer heavy boxes, navigate vineyard terrains, communicate, accurately locate, and safely interact with humans. The introduction of collaborative robotic fleets alongside human workers in large-scale vineyard harvesting effectively presents a Multi-Robot Task Allocation (MRTA) problem, where the real-world domain possesses characteristics that, when combined, pose a challenging research endeavor and align with open issues in MRTA research. Here, we present RoboVineSim, a simulation tool that can capture any vineyard area using geographical data and model the behavior of humans and robots in the environment. In addition, we have established the necessary mechanisms to facilitate the development of novel MRTA methods in this domain.
- [Adamides and Edan, 2023] George Adamides and Yael Edan. Human-robot collaboration systems in agricultural tasks: A review and roadmap. Computers and Electronics in Agriculture, 204:107541, 2023.
- [Agüero et al., 2015] Carlos E. Agüero, Nate Koenig, Ian Chen, Hugo Boyer, Steven Peters, John Hsu, Brian Gerkey, Steffi Paepcke, Jose L. Rivero, Justin Manzo, Eric Krotkov, and Gill Pratt. Inside the virtual robotics challenge: Simulating real-time robotic disaster response. IEEE Transactions on Automation Science and Engineer- ing, 12(2):494-506, 2015.
- [Asadayoobi et al., 2023] Negin Asadayoobi, Sharareh Taghipour, and Mohamad Y. Jaber. Optimising stochastic task allocation and scheduling plans for mission workers subject to learning-forgetting, fatigue-recovery, and stress-recovery effects. Expert Systems with Applications, 229:120524, 2023.
- [Bechar and Vigneault, 2017] Avital Bechar and Clément Vigneault. Agricultural robots for field operations. part 2: Operations and systems. Biosystems Engineering, 153:110-128, 2017.
- [Chakraa et al., 2023] Hamza Chakraa, Franc ¸ois Guérin, Edouard Leclercq, and Dimitri Lefebvre. Optimization techniques for multi-robot task allocation problems: Re- view on the state-of-the-art. Robotics and Autonomous Systems, 168:104492, 2023.
- [Choi et al., 2009] Han-Lim Choi, Luc Brunet, and Jonathan P How. Consensus-based decentralized auctions for robust task allocation. IEEE transactions on robotics, 25(4):912-926, 2009.
- [Conejero et al., 2025] Maria Nuria Conejero, Hector Montes, Jose Maria Bengochea-Guevara, Laura Garrido- Rey, Dionisio Andújar, and Angela Ribeiro. A collab- orative robotic fleet for yield mapping and manual fruit harvesting assistance. Computers and Electronics in Agriculture, 235:110351, 2025.
- [Dias et al., 2006] M. Bernardine Dias, Robert Zlot, Nidhi Kalra, and Anthony Stentz. Market-based multirobot coor- dination: A survey and analysis. Proceedings of the IEEE, 94(7):1257-1270, 2006.
- [Duckett et al., 2018] Tom Duckett, Simon Pearson, Simon Blackmore, and Bruce Grieve. Agricultural Robotics: The Future of Robotic Agriculture. EPSRC UK Robotics and Autonomous Systems (RAS) Network, United Kingdom, June 2018.
- [Khamis et al., 2015] Alaa Khamis, Ahmed Hussein, and Ahmed Elmogy. Multi-robot Task Allocation: A Review of the State-of-the-Art, pages 31-51. Springer, 2015.
- [Macenski et al., 2022] Steven Macenski, Tully Foote, Brian Gerkey, Chris Lalancette, and William Woodall. Robot operating system 2: Design, architecture, and uses in the wild. Science Robotics, 7(66):eabm6074, 2022.
- [Peng et al., 2022] Chen Peng, Stavros Vougioukas, David Slaughter, Zhenghao Fei, and Rajkishan Arikapudi. A strawberry harvest-aiding system with crop-transport col- laborative robots: Design, development, and field evalua- tion. Journal of Field Robotics, 39(8):1231-1257, 2022.
- [QGIS Development Team, 2026] QGIS Development Team. QGIS Geographic Information System. QGIS Association, 2026.
- [Quinton et al., 2023] Félix Quinton, Christophe Grand, and Charles Lesire. Market approaches to the multi-robot task allocation problem: a survey. Journal of Intelligent & Robotic Systems, 107(2):29, 2023.
- [Seyyedhasani et al., 2020] Hasan Seyyedhasani, Chen Peng, Wei jiunn Jang, and Stavros G. Vougioukas. Collaboration of human pickers and crop-transporting robots during harvesting -part i: Model and simulator development. Computers and Electronics in Agriculture, 172:105324, 2020.
- [Shen et al., 2018] Liji Shen, Stéphane Dauzère-Pérès, and Janis S. Neufeld. Solving the flexible job shop scheduling problem with sequence-dependent setup times. European Journal of Operational Research, 265(2):503-516, 2018.
- [Yao et al., 2024] Bitao Yao, Xinyu Li, Zhenrui Ji, Kun Xiao, and Wenjun Xu. Task reallocation of human-robot collaborative production workshop based on a dynamic human fatigue model. Computers & Industrial Engineer- ing, 189:109855, 2024.
- [Yerebakan and Hu, 2024] Mustafa Ozkan Yerebakan and Boyi Hu. Human-robot collaboration in modern agricul- ture: A review of the current research landscape. Ad- vanced Intelligent Systems, 6(7):2300823, 2024.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Agricultural Robotics [Duckett et al., 2018] present new opportunities that already transform the landscape of agricultural operations. The technological capabilities of robotic platforms are harnessed in a wide range of field applications [Bechar and Vigneault, 2017]. Such platforms may require human monitoring and intervention, while others are targeted for Human-Robot Collaboration (HRC) environments where human workers coexist and collaborate with robots [Yerebakan and Hu, 2024]. In the context of harvesting applications, the current roadmap for HRC research calls for principled designs that tackle safety, functionality, and interface design (in that order) [Adamides and Edan, 2023]. In particular, the functionality aspect aligns with the task allocation mechanism for the robotic fleet. For HRC in vineyard harvesting, we are interested in expanding the capabilities of a flexible robotic platform [Conejero et al., 2025] that helps humans harvest grapes by undertaking the transportation task.
The robotic fleet consists of four-wheeled mobile robots designed to transport boxes. Each robot is equipped with the necessary hardware and software to safely detect, track, and follow a human worker along a vineyard row, while maintaining reliable communication with a centralized system.
However, scheduling this multi-robot system efficiently presents a challenge, as we need to account for humanimposed uncertainty about timings and heterogeneity between them, e.g., depending on their expertise, as shown from field tests [Conejero et al., 2025]. To advance the capabilities of the technology, this HRC environment can be formulated as a Multi-Robot Task Allocation (MRTA) problem [Khamis et al., 2015]. The development and evaluation of solution methods require a capable and flexible simulation environment, and, to the best of our knowledge, existing work on related problems [Seyyedhasani et al., 2020; Peng et al., 2022] relies on ad hoc simulators with limited extensibility and limited open-source availability.
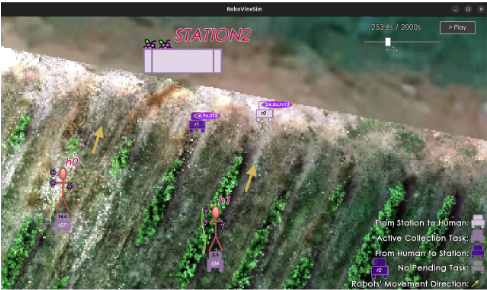
To this end, we propose RoboVineSim 1 (ROBOtic VINEyard SIMulator), a novel simulation tool that models key components of a real-world vineyard setting-including humans, robots, and the environment-and translates them into an MRTA problem. What distinguishes it from related work is that it: a) incorporates Geographical Information System (GIS) data capturing any arbitrary vineyard layout; b) supports configurable assumptions regarding robots and humans, by specifying robots' kinematics and task-specific characteristics, and how humans' performance evolves over time according to their fatigue levels [Yao et al., 2024]; and c) is compatible with any task allocation algorithm that can operate in an online manner, receiving and allocating new tasks. Robots navigate the environment autonomously, conforming to its topological layout and following their task sequence, with routes updated automatically as new tasks arrive. Figure 1 shows the simulator's graphical user interface.
From a research perspective, RoboVineSim offers substantial benefits that extend the specific agricultural application for robotics. Our simulator can be used as a benchmark environment for MRTA research, as the setting poses well-known challenges, including scalability (controlling large robotic fleets across vast areas), flexibility (operating in open environments that adapt to sudden changes), incorporation of uncertainty, and need for dynamic task allocation. Benchmarks in the literature that encompass a combination of the aforementioned elements are scarce [Quinton et al., 2023]. Furthermore, by modeling a challenging real-world environment and with the field-testing opportunities presented by the existing robotic platform [Conejero et al., 2025], this endeavor is also geared towards novel MRTA methods that bridge the gap between simulation-based evaluation and field deployment.
2 ProblemDescription
We model our MRTA problem as one consisting of parallel rows of grapes, and we consider each human hi, i ∈ [0,H - 1] of the harvesting team to be located in a different row, harvesting grapes with a rate of fi(t) weight unit per time unit at each discrete time-step t. This element introduces: (a) the heterogeneity of humans in terms of performance (function is unique to each human), along with uncertainty in the case fi(t) follows some probability distribution. Harvesting sessions typically span many hours, during which human fatigue builds. This aspect is investigated in manufacturing processing research [Yao et al., 2024; Asadayoobi et al., 2023], which shares conceptual similarities with our domain of interest, and should affect the form of fi(t).
To make efficient use of an available robotic fleet, we formulate an MRTA problem to determine robots' behavior by assigning tasks to them. A robot rk, k ∈ [0,R- 1] assigned for a task τij of human hi performs the following consecutive actions in order to execute it:
- start from a station sl and navigate the vineyard to reach hi (r4 in Figure 2);
- follow hi until a certain amount of weight is collected; (r1, r5, r8 in Figure 2); and
- return to the closest station and unload the full box. (r7 in Figure 2)
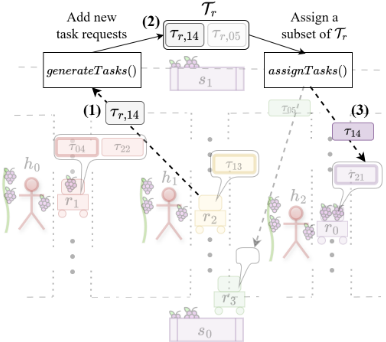
Afterwards, robot rk is available for a new task. If there are no pending tasks, it remains at the station (r0, r2, r3, r6 in Figure 2). Each robot maintains a sequence of tasks (illustrated in Figure 3) that is updated online based on a task allocation mechanism.
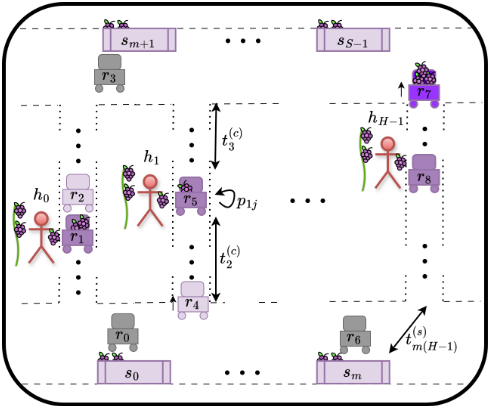
Reflecting our current objective, successive tasks τi(j-1), τij of human hi should be ideally executed without any intervening delay. As robots handle transportation tasks, humans can concentrate solely on grape collection without interruptions caused by robot delays. 2 Essentially, when the robot assigned with τi(j-1) is about to leave human hi and exit, a second robot assigned with task τij should be there already to replace it. Since vineyard rows are narrow, we do not allow robots to cross paths within a row to prevent collisions or deadlocks. This means that we have constraints regarding how robots should navigate the vineyard, which are also part of the MRTA formulation. In Figure 2, we see additional timing information that is needed to accurately represent this problem. These involve various travel (time to navigate between key locations) and processing (time human hi needs to fill up the box to capacity) times.
Humans work with different rates, and fatigue is expected to gradually increase their processing times over extended operations. At a given time-step, over a long planning horizon, a set of tasks need to be assigned, each with distinct processing time, and time precedence constraints on successive tasks τi(j-1), τij. Based on the established taxonomy of MRTA problems [Quinton et al., 2023], we can classify our problem as SR-ST-TA:SP, XD (Single-task Robot, Single-robot Task, Time-extended Assignment with Synchronization and Precedence constraints and Cross-Schedule Dependencies). The environment is also dynamic, and we have uncertainty about how it evolves, an element that stems from the collection rate fi(t) of humans, which in turn can be modeled by human fatigue models [Yao et al., 2024]. Moreover, tasks gradually appear online according to adjustable conditions. Based on the robotic platform's capabilities [Conejero et al., 2025], we can assume global connectivity without communication issues. However, our simulation environment does not restrict the development of decentralized methods, assuming only local communication (fully distributed based on proximity or any type of hierarchical structure) among robots. In addition, we can also draw similarities with Flexible Job-Shop Scheduling Problems with Sequence-Dependent Setup Times [Shen et al., 2018]. Based on the notation of such problems, each human acts as a job with successive operations (tasks) and each robot as a machine.
2 Instead of the typical makespan objective in scheduling problems. Naturally, more elaborate criteria involving multiple goals (e.g., energy efficiency) and soft constraints (e.g. respecting human fatigue limits) can be examined.
3 Assigning Tasks to Robots
In our simulation environment, we have a discretized time-step length. At each time-step, two main methods generateTasks(), assignTasks() are called with access to a data structure containing each robot's online information and current schedule. Thereby, we assume a centralized system that communicates with all robots and has access to their information, as indicated in Figure 3. More specifically, we have a set of task requests Tr, where generateTasks() can append new tasks τr,ij according to user-defined conditions. Each entry is a tuple with the following information: τr,ij = ⟨hi, j, tij,e, pij⟩, where hi: human associated with the task; j: the jth task of hi; tij,e: earliest start time of task; and pij: duration of task (estimate in the case of uncertainty). Then, assignTasks() needs to allocate each element to a robot. Notably, task requests can remain unallocated until a deadline (according to the earliest start time tij,e of τr,ij).
Inside assignTasks(), we implement a Sequential SingleItem (SSI) auction [Dias et al., 2006] to exemplify our tool, and form a simple bidding function bk(τr,ij) based on the time robot rk expects to finish τr,ij. Naturally, other classic methods based on Mixed-Integer Linear Programming (MILP) or Metaheuristics [Chakraa et al., 2023], could also be considered by appropriately processing the set Tr and
(re-)scheduling tasks online according to a frequency term. Decentralized methods, such as the Consensus-based Auction Algorithm [Choi et al., 2009] and its extensions, could also be adopted. This can be accomplished by implementing assignTasks() with restricted information access and communication among robots based on a decentralized scheme.
4 Additional Aspects
CaptureVineyardAreas withGIS Software. We can prepare an appropriate input file based on any vineyard's geographical data. By prescribing key points of interest (row entries, station and intermediate point positions wherever needed), we can directly construct a topological map for our problem and, assuming GPS-enabled robots, command them accordingly. QGIS software [QGIS Development Team, 2026] is used for this procedure. With UTM coordinates and certain assumptions, we can then measure distances accordingly. Another useful feature of working with geographical data is that we can parse satellite and aerial landscape views to our visualizer, as illustrated in Figure 1, and display robots' and humans' online behavior.
Robot Navigation in the Vineyard. Robots navigate the constructed vineyard network using assumed kinematics and projected UTM coordinates, enabling us to estimate travel time data for each robot. To prevent deadlocks in vineyard rows, robots maintain the same direction alongside a row. A direction change can only be triggered when a robot enters the row, provided the row contains at most one robot at that time. In such cases, the robot already inside is notified and adjusts its exit direction and the nearest station accordingly. As a result, a robot attempting to enter an occupied row from the wrong direction may be forced to wait at the entry point. This highlights the importance of efficient and informed task allocation, as robots may end up waiting in queues.
Configuration File. A main configuration file prescribes the human and robotic fleet along with their characteristics and initializes the environment according to the GIS data.
5 Conclusions and FutureWork
We presented the development of RoboVineSim, a researchfocused simulator designed as an expansive tool that supports research on MRTA methods for tackling HRC in similar environments. Furthermore, by calibrating our assumptions regarding the robots, e.g. the hardware being part of a specific robotic platform as the one developed in [Conejero et al., 2025], along with how humans operate and how their fatigue evolves in this environment [Yao et al., 2024], we can provide a complete framework for sustainable agriculture in HRC, advancing the capabilities of robotic infrastructure in terms of coordination and online adaptation.
Future work endeavors involve operating alongside ROS2 [Macenski et al., 2022] and Gazebo [Ag¨uero et al., 2015] to gain insight into the actual hardware characteristics of the robotic fleet, assessing aspects such as communication delays and robot kinematic calibration, ultimately resulting in a proper end-to-end platform. Furthermore, we are working to model and understand the impact of human fatigue on the design of MRTA methods.
Acknowledgments
Dimitrios Troullinos was supported by the the ALLIES Cofund project, which has received funding from the European Union's Horizon-MSCA-2022-COFUND-01 research and innovation program under the Marie Skłodowska-Curie grant agreement No 101126626. This work was also supported by the EU-funded VALAWAI (Id. 101070930) project, the ACISUD (PID2022-136787NB-I00) project, and it was carried out within the framework of the PIE-CSIC project "Artificial intelligence and collaborative robotics in precision agriculture" (AGROBOTS, 202450E209), and the iRoboCity2030-CM project (TEC-2024/TEC-62), which was funded by the Comunidad de Madrid.
@inproceedings{ijcai2026p999,
  title     = {RoboVineSim: A Simulation Tool for Human-Robot Collaboration in Vineyard Harvesting},
  author    = {Troullinos, Dimitrios and Conejero, Maria Nuria and Bistaffa, Filippo and Bengochea-Guevara, Jose M. and Ribeiro, Ángela and Rodriguez Aguilar, Juan A.},
  booktitle = {Proceedings of the Thirty-Fifth International Joint Conference on
               Artificial Intelligence, {IJCAI-26}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Diego Calvanese},
  pages     = {8543--8546},
  year      = {2026},
  month     = {8},
  note      = {Demo Track},
  doi       = {10.24963/ijcai.2026/999},
  url       = {https://doi.org/10.24963/ijcai.2026/999},
}
TY - CPAPER TI - RoboVineSim: A Simulation Tool for Human-Robot Collaboration in Vineyard Harvesting AU - Troullinos, Dimitrios AU - Conejero, Maria Nuria AU - Bistaffa, Filippo AU - Bengochea-Guevara, Jose M. AU - Ribeiro, Ángela AU - Rodriguez Aguilar, Juan A. T2 - Proceedings of the Thirty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-26 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2026 SP - 8543 EP - 8546 DO - 10.24963/ijcai.2026/999 UR - https://doi.org/10.24963/ijcai.2026/999 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





