
Contact2Grasp: 3D Grasp Synthesis via Hand-Object Contact Constraint
Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence. Main Track. Pages 1053-1061.
https://doi.org/10.24963/ijcai.2023/117
Keywords
- Computer Vision: CV: 3D computer vision
- Computer Vision: CV: Applications
Abstract
3D grasp synthesis generates grasping poses given an input object. Existing works tackle the problem by learning a direct mapping from objects to the distributions of grasping poses. However, because the physical contact is sensitive to small changes in pose, the high-nonlinear mapping between 3D object representation to valid poses is considerably non-smooth, leading to poor generation efficiency and restricted generality. To tackle the challenge, we introduce an intermediate variable for grasp contact areas to constrain the grasp generation; in other words, we factorize the mapping into two sequential stages by assuming that grasping poses are fully constrained given contact maps: 1) we first learn contact map distributions to generate the potential contact maps for grasps; 2) then learn a mapping from the contact maps to the grasping poses. Further, we propose a penetration-aware optimization with the generated contacts as a consistency constraint for grasp refinement. Extensive validations on two public datasets show that our method outperforms state-of-the-art methods regarding grasp generation on various metrics.
- [Achlioptas et al., 2018] Panos Achlioptas, Olga Diamanti, Ioannis Mitliagkas, and Leonidas Guibas. Learning rep- resentations and generative models for 3d point clouds. In International Conference on Machine Learning, pages 40- 49, 2018.
- [Arjovsky et al., 2017] Martin Arjovsky, Soumith Chintala, and Léon Bottou. Wasserstein generative adversarial net- works. In International conference on machine learning, pages 214-223, 2017.
- [Brahmbhatt et al., 2019a] Samarth Brahmbhatt, Cusuh Ham, Charles C Kemp, and James Hays. Contactdb: An- alyzing and predicting grasp contact via thermal imaging. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 8709-8719, 2019.
- [Brahmbhatt et al., 2019b] Samarth Brahmbhatt, Ankur Handa, James Hays, and Dieter Fox. Contactgrasp: Functional multi-finger grasp synthesis from contact. In IEEE/RSJ International Conference on Intelligent Robots and Systems, pages 2386-2393, 2019.
- [Brahmbhatt et al., 2020] Samarth Brahmbhatt, Chengcheng Tang, Christopher D Twigg, Charles C Kemp, and James Hays. Contactpose: A dataset of grasps with object con- tact and hand pose. In European Conference on Computer Vision, pages 361-378, 2020.
- [Chang et al., 2015] Angel X Chang, Thomas Funkhouser, Leonidas Guibas, Pat Hanrahan, Qixing Huang, Zimo Li, Silvio Savarese, Manolis Savva, Shuran Song, Hao Su, et al. Shapenet: An information-rich 3d model repository. arXiv preprint arXiv:1512.03012, 2015.
- [Corona et al., 2020] Enric Corona, Albert Pumarola, Guillem Alenya, Francesc Moreno-Noguer, and Grégory Rogez. Ganhand: Predicting human grasp affordances in multi-object scenes. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 5031-5041, 2020.
- [Deng et al., 2021] Shengheng Deng, Xun Xu, Chaozheng Wu, Ke Chen, and Kui Jia. 3d affordancenet: A bench- mark for visual object affordance understanding. In Pro- ceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 1778-1787, 2021.
- [Grady et al., 2021] Patrick Grady, Chengcheng Tang, Christopher D Twigg, Minh Vo, Samarth Brahmbhatt, and Charles C Kemp. Contactopt: Optimizing contact to improve grasps. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 1471-1481, 2021.
- [Hasson et al., 2019] Yana Hasson, Gul Varol, Dimitrios Tzionas, Igor Kalevatykh, Michael J Black, Ivan Laptev, and Cordelia Schmid. Learning joint reconstruction of hands and manipulated objects. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 11807-11816, 2019.
- [Jiang et al., 2021] Hanwen Jiang, Shaowei Liu, Jiashun Wang, and Xiaolong Wang. Hand-object contact consis- tency reasoning for human grasps generation. In Proceed- ings of the IEEE/CVF International Conference on Com- puter Vision, pages 11107-11116, 2021.
- [Karunratanakul et al., 2020] Korrawe Karunratanakul, Jin- long Yang, Yan Zhang, Michael J Black, Krikamol Muan- det, and Siyu Tang. Grasping field: Learning implicit rep- resentations for human grasps. In 2020 International Con- ference on 3D Vision, pages 333-344, 2020.
- [Mahendran et al., 2017] Siddharth Mahendran, Haider Ali, and René Vidal. 3d pose regression using convolutional neural networks. In Proceedings of the IEEE International Conference on Computer Vision Workshops, pages 2174- 2182, 2017.
- [Mandikal and Grauman, 2021] Priyanka Mandikal and Kristen Grauman. Learning dexterous grasping with object-centric visual affordances. In IEEE Interna- tional Conference on Robotics and Automation, pages 6169-6176, 2021.
- [Mandikal and Grauman, 2022] Priyanka Mandikal and Kristen Grauman. Dexvip: Learning dexterous grasping with human hand pose priors from video. In Conference on Robot Learning, pages 651-661, 2022.
- [Miller and Allen, 2004] Andrew T Miller and Peter K Allen. Graspit! a versatile simulator for robotic grasping. IEEE Robotics & Automation Magazine, pages 110-122, 2004.
- [Milletari et al., 2016] Fausto Milletari, Nassir Navab, and Seyed-Ahmad Ahmadi. V-net: Fully convolutional neu- ral networks for volumetric medical image segmentation. In International Conference on 3D Vision, pages 565-571, 2016.
- [Mo et al., 2021] Kaichun Mo, Leonidas J Guibas, Mustafa Mukadam, Abhinav Gupta, and Shubham Tulsiani. Where2act: From pixels to actions for articulated 3d ob- jects. In Proceedings of the IEEE/CVF International Con- ference on Computer Vision, pages 6813-6823, 2021.
- [Qi et al., 2017] Charles R Qi, Hao Su, Kaichun Mo, and Leonidas J Guibas. Pointnet: Deep learning on point sets for 3d classification and segmentation. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition, pages 652-660, 2017.
- [Romero et al., 2017] Javier Romero, Dimitris Tzionas, and Michael J Black. Embodied hands: Modeling and cap- turing hands and bodies together. ACM Transactions on Graphics, 2017.
- [Roy and Todorovic, 2016] Anirban Roy and Sinisa Todor- ovic. A multi-scale cnn for affordance segmentation in rgb images. In European conference on computer vision, pages 186-201, 2016.
- [Sohn et al., 2015] Kihyuk Sohn, Honglak Lee, and Xinchen Yan. Learning structured output representation using deep conditional generative models. Advances in neural infor- mation processing systems, 28, 2015.
- [Taheri et al., 2020] Omid Taheri, Nima Ghorbani, Michael J Black, and Dimitrios Tzionas. Grab: A dataset of whole-body human grasping of objects. In European conference on computer vision, pages 581-600, 2020.
- [Taheri et al., 2021] Omid Taheri, Vasileios Choutas, Michael J Black, and Dimitrios Tzionas. Goal: Gener- ating 4d whole-body motion for hand-object grasping. arXiv preprint arXiv:2112.11454, 2021.
- [Wu et al., 2021] Ruihai Wu, Yan Zhao, Kaichun Mo, Zizheng Guo, Yian Wang, Tianhao Wu, Qingnan Fan, Xuelin Chen, Leonidas Guibas, and Hao Dong. Vat- mart: Learning visual action trajectory proposals for manipulating 3d articulated objects. arXiv preprint arXiv:2106.14440, 2021.
- [Xing et al., 2022] Fangyuan Xing, Shibo He, Victor CM Leung, and Hongxi Yin. Energy efficiency optimization for rate-splitting multiple access-based indoor visible light communication networks. IEEE Journal on Selected Areas in Communications, 40(5):1706-1720, 2022.
- [Zhang et al., 2021] He Zhang, Yuting Ye, Takaaki Shiratori, and Taku Komura. Manipnet: neural manipulation synthe- sis with a hand-object spatial representation. ACM Trans- actions on Graphics, pages 1-14, 2021.
- [Zhu et al., 2015] Yixin Zhu, Yibiao Zhao, and Song Chun Zhu. Understanding tools: Task-oriented object modeling, learning and recognition. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pat- tern Recognition, pages 2855-2864, 2015.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
3D grasp synthesis studies the problem of generating grasping poses given an input object. It has wide applications ranging from animation, human-computer interaction to robotic grasping. Though it has been researched for many years, only a limited number of works about 3D grasp generation using deep learning have been proposed due to the lack of large grasping data [Corona et al., 2020; Taheri et al., 2020; Jiang et al., 2021; Karunratanakul et al., 2020; Zhang et al., 2021; Taheri et al., 2021]. Recently, a dataset for human grasping objects with annotations of full body meshes and objects meshes have been collected by a multi-view capture rig, and a coarse-to-fine hand pose generation network based on a conditional autoencoder (CVAE) is proposed [Taheri et al., 2020]. In [Karunratanakul et al., 2020], a new implicit representation is proposed for hand and object interactions, and a similar CVAE method is used for static grasps generation. Taheri et al. [Taheri et al., 2021] take a step further to learn dynamic grasping sequences including the whole body motion given an object, instead of static grasping poses.
∗Corresponding author (qi.ye@zju.edu.cn).
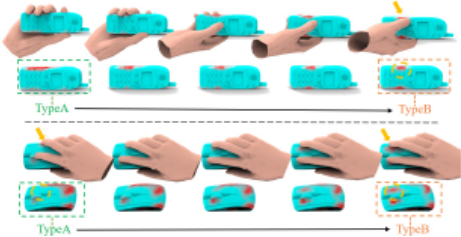
Existing methods treat the generation as a black box mapping from an object to its grasp pose distribution. However, this formulation has its defects. On one hand, the mapping from the 3D object space to the pose space represented by rotations is highly non-linear. On the other hand, physical contact is sensitive to small changes in pose, e.g., less than a millimeter change in the pose of a fingertip normal to the surface of an object can make the difference between the object being held or dropped on the floor [Grady et al., 2021]. Therefore, the mapping between 3D object representation to valid poses is non-smooth, as a small change in the pose could make a valid pose invalid. These defects raise a challenge for the network to learn the sparse mapping and generalize to unseen valid poses in the highly non-linear space.
In robotics, contact areas between agents and objects are found to be important [Deng et al., 2021; Roy and Todorovic, 2016; Zhu et al., 2015] because localizing the position of possible grasps can greatly help the planning of actions for robotic hands [Mo et al., 2021; Wu et al., 2021; Mandikal and Grauman, 2021; Mandikal and Grauman, 2022]. For example, [Mo et al., 2021] and [Wu et al., 2021] first estimate the contact points for parallel-jaw grippers and plan paths to grasp the target objects. The common assumption in the literature is that the contact area is a point and the contact point generation is treated as a per-point (or pixel voxel) detection problem, i.e. classifying each 3D object point to be a contact or not, which cannot be applied to dexterous hand grasps demonstrating much more complex contact. For dexterous robotic hand grasping, recent work [Mandikal and Grauman, 2021] finds that leveraging contact areas from human grasp can improve the grasping success rate in a reinforcement learning framework. However, it assumes an object only affords one grasp, which contradicts the real case and limits its application.
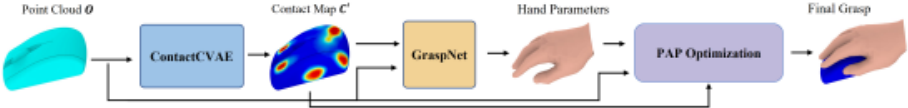
To tackle the limitations, we propose to leverage contact maps to constrain the grasp synthesis. Specifically, we factorize the learning task into two sequential stages, rather than taking a black-box hand pose generative network that directly maps an object to the possible grasping poses in previous work. In the first stage, we generate multiple hypotheses of the grasping contact areas, represented by binary 3D segmentation maps. In the second stage, we learn a mapping from the contact to the grasping pose by assuming the grasping pose is fully constrained given a contact map.
The intermediate segmentation contact maps align with the smooth manifold of the object surface: for example, a small change in a valid contact map would likely produce another valid solution (as illustrated in Figure 1), then the corresponding pose can be deterministically established by the following GraspNet and PAP optimization. This manner reduces the challenging pose generation to an easier map generation problem in a low-dimension and smooth manifold, benefiting generation efficiency and generality.
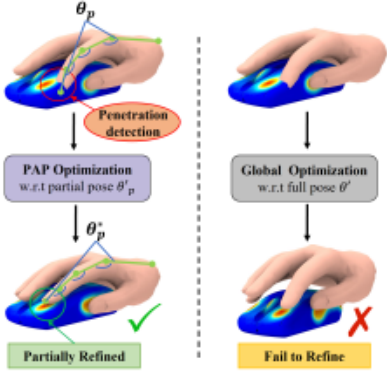
The other benefit of the intermediate contact representation is enabling the optimization from the contacts. Different from the optimization for the full grasps from scratch [Brahmbhatt et al., 2019b; Xing et al., 2022], we propose a penetrationaware partial (PAP) optimization with the intermediate contacts. It detects partial poses causing penetration and leverages the generated contact maps as a consistency constraint for the refinement of the partial poses. The PAP optimization constrains gradients from wrong partial poses to affect these poses requiring adjustment only, which results in better grasp quality than a global optimization method.
In summary, our key contributions are: 1) we tackle the high non-linearity problem of the 3D generation problem by introducing the contact map constraint and factorizing the generation in two stages: contact map generation and mapping from contact maps to grasps; 2) we propose a PAP optimization with the intermediate contacts for the grasp refinement; 3) benefiting from the two decomposed learning stages and partial optimization, our method outperforms existing methods both quantitatively and qualitatively.
2 RelatedWorks
Human grasp generation is a challenging task due to the higher degrees of freedom of human hands and the requirement of the generated hands to interact with objects in a physically reasonable manner. Most methods use models such as MANO [Romero et al., 2017] to parameterize hand poses, aiming to directly learn a latent conditional distribution of the hand parameters given objects via large datasets. The distribution is usually learned by generative network models such as Conditional Variational Auto-Encoder [Sohn et al., 2015], or Adversarial Generative Networks [Arjovsky et al., 2017]. To get finer poses, many existing works adopt a coarse-to-fine strategy by learning the residuals of the grasping poses in the refinement stage. [Corona et al., 2020] uses a generative adversarial network to obtain an initial grasp, and then an extra network to refine it. [Taheri et al., 2020] follows a similar strategy but uses a CVAE model to output an initial grasp.
In recent works, contact maps are exploited to improve robotic grasping, hand object reconstruction, and 3D grasp synthesis. [Brahmbhatt et al., 2019b] introduces a loss for robotic grasping optimization using contact maps captured from thermal cameras [Brahmbhatt et al., 2019a; Brahmbhatt et al., 2020] to filter and rank random grasps sampled by GraspIt! [Miller and Allen, 2004]. It concludes that synthesized grasping poses optimized directly from the contact demonstrate superior quality to other approaches which kinematically re-target observed human grasps to the target hand model. In the reconstruction of the hand-object interaction, [Grady et al., 2021] propose a differentiable contact optimization to refine the hand pose reconstructed from an image. In the 3D grasp synthesis, [Jiang et al., 2021] also exploits contact maps but they only use them to refine generated grasps during inference. Our work differs from these works using contact maps in three aspects: 1) these works use contact maps as a loss for the grasp optimization or post-processing for further grasp refinement while our work exploits the contact maps as an intermediate constraint for the learning of the grasp distribution; 2) in contrast to the learning-based works with contact maps which treat objects-to-grasps as a black box, our work factorizes the grasp synthesis into objects-tocontact maps and contact maps-to-grasps; 3) moreover, these works refine the whole grasps with global optimization methods using contact maps while our penetration-aware partial optimization detects the partial poses causing the penetration and leverages the contact map constraint to optimize the partial poses only rather than the whole poses.
3 Method
Figure 2 shows our method pipeline. It generates maps for contact areas by a network naming ContactCVAE, maps the contact maps to grasping poses by the other network naming GraspNet, and refines the generated grasp by a penetration-aware optimization module. In the work, we adopt MANO [Romero et al., 2017] to represent grasps. The MANO model M parameterizes the hand mesh M = (V, F ) (V ∈ R778×3 , F ∈ R1538 denotes the mesh vertices and faces) by the shape parameters β ∈ R10 and pose parameters θ ∈ R51 , i.e. M = M(θ, β). In the work, we use the mean shape and use M = M(θ) for brevity.
In the first stage, ContactCVAE aims to learn a contact map distribution represented by a latent vector z given an input object using a conditional variational autoencoder. The network takes an object point cloud O ∈ RN×3 and the contact map C ∈ RN×1 as the input and learns to make the output contact map C ′ ∈ RN×1 as close to the input contact map as possible. N is the number of points in O. Each point in the point cloud is represented by its normalized 3D positions. Each point in the contact map takes a value in [0, 1] representing the contact score. During inference, given an object, a contact map C ′ can be generated by sampling from z. In the second stage, GraspNet learns a mapping from the contact map C ′ to the hand mesh M constrained by the map. The pose θ′ of the predicted mesh M ′ from GraspNet is refined with PAP optimization in the third stage.
3.1 ContactCVAE
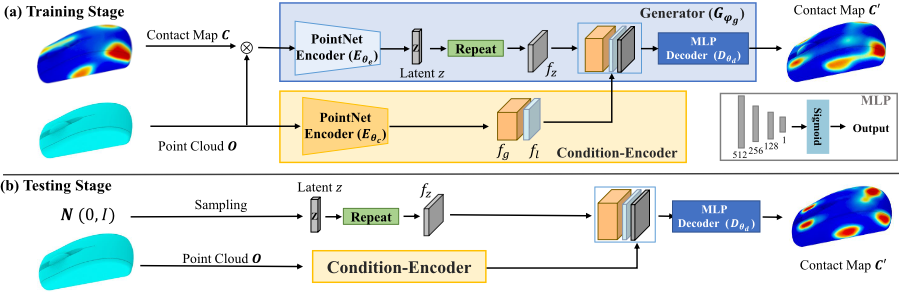
Figure 3 demonstrates the architecture of the ContactCVAE network, which is a generative model based on CVAE [Sohn et al., 2015]. It consists of two blocks: a Condition-Encoder and a Generator.
Condition-Encoder. TheCondition-Encoder Eθc is built on PointNet [Qi et al., 2017]. It takes a point cloud as input to extract local features fl ∈ RN×64 and global featuresfg ∈
R1×1024 . fg are then duplicated N times to make a feature map fg ∈ RN×1024 for matching the shape of fl. These two features are then concatenated as flg for the conditional inputs for the generator below.
Generator. The generator Gϕg follows an encoder-decoder architecture. As shown on the top of Figure 3, the encoder, Eθe : (C,O) ↣ z, is based on PointNet [Qi et al., 2017] architecture which takes both an object point cloud O and a contact map C as inputs and outputs the latent code z ∈ R64 . The encoder is only employed in training and is discarded in inference. The latent code z represents a sample of the learned distribution Q(z|µ, σ2 ) and is used to generate the contact map, where µ, σ2 denotes the mean and variance of the distribution. We then duplicate the latent code z N times to make the latent feature fz for all the points. The decoder Dθd :(f i z , f i lg ) ↣ C ′i is a classifier for a point i which merges three different features (global f i g , local f i l and latent f i z ) to classify whether the point belongs to a contact map or not. The decoder Dθd uses the MLP architecture and the weights are shared for all points.
Testing Stage. During inference, as shown in the bottom of Figure 3, we only employ the Conditional-Encoder and decoder Dθd . A latent code z is randomly sampled from a Gaussian distribution and forms the latent feature fz. At the same time, the Condition-Encoder takes an object point cloud to output the global and local features. With these features (fz, fg, fl), Dθd outputs the grasp contact C ′ for the object.
Contact Loss. The goal of training the model is to optimize θe, θd in order to reconstruct the contact map well. We simplify the goal as a binary classification task. Thus, we adopt the binary cross-entropy loss for the model over all the points, named as Lc1. However, some samples have small contact regions and it is hard for the model to learn those samples well by simply adopting the BCE loss. To address this problem, we additionally introduce the dice loss [Milletari et al., 2016] to train the model. It can assist the model in paying attention to small target regions. In our work, we adopt the dice loss for the same purpose and name as Lc2. the formulation of the two loss is defined as:
where ˆ yi and yi represent the predicted contact and ground truth of a point i, respectively.
Following the training of CVAE [Sohn et al., 2015], we use the KL-Divergence loss regularizing the latent distribution to be close to a standard Gaussian distribution. The loss term is named as Lkl. The overall loss function of the ContactCVAE network, Lcontact, is represented as:
where the γ0 = 0.5, γ1 = 0.5 and γ2 = 1e - 3 are constants for balancing the loss terms.
3.2 GraspNet
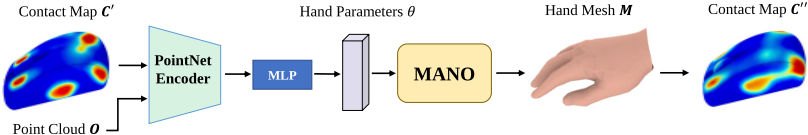
With the assumption of hands full constrained by a contact map, we adopt a mapping function to get the grasping pose from the generated contact from the first stage. As shown in Figure 4, the model takes an object point cloud O and its generated (or reconstructed) contact C ′ as the input to predict the hand mesh for the grasping pose, which is represented by the MANO model [Romero et al., 2017]. Specifically, we employ a PointNet [Qi et al., 2017] to extract the feature and then use an MLP with four hidden layers to regress the MANO parameters. Given the parameters, the MANO model forms a differentiable layer that outputs the hand mesh M.
During the training period, we use both ground truth and reconstructed contact maps to train the GraspNet. During inference, we only use the generated contact map to predict the grasp mesh. Both reconstructed and generated contact maps are from the ContactCVAE model in the first stage.
Reconstruction Loss. We simply adopt the reconstruction loss (L2 distance) for the predicted vertices, named as Lv. The loss on MANO parameters is divided into two parts. We use the L1 loss for the translation parameter and the geodesic loss [Mahendran et al., 2017] for the pose parameter, named as Lt and Lp respectively. The final reconstruction error can be represented as LR = λvLv + λtLt + λpLp, where λv=35, λt=0.1 and λp=0.1 are constants balancing the losses. We also use the penetration loss Lptr = 1 |Oh in | ∑o∈Oh in mini ∥o - Vi∥2 which punishes penetrations between the hand and object. Oh in denotes the object point subset that is inside the hand.
Consistency Loss. Similar to the previous work [Jiang et al., 2021], we introduce the contact consistency loss Lcst = ∥C ′ - C ′′ ∥2 . Based on the distance between the object and the grasp mesh M, the contact map C ′′ can be inferred by normalizing the distance between O and their nearest hand prior vertice. If the grasp mesh M is predicted correctly from the GraspNet, the input contact map C ′ should be consistent with the contact map C ′′ .
The overall loss of GraspNet, Lgrasp, is the weighted sum of all the above loss terms:
where λptr=5 and λcst=0.05 denote the corresponding loss weights.
3.3 Penetration-Aware Partial Optimization
Though GraspNet gives plausible grasps for most cases, physically feasible grasps are sensitive to small errors in poses. For example, small penetration of a fingertip to the surface of an object can make the object drop to the floor. Hence, we propose the penetration-aware partial (PAP) optimization with generated contact maps to provide further constraints for small-scale partial pose refinement. PAP aims to detect the penetration and refine the partial poses causing it while keeping other partial poses of good quality unchanged. To this end, the full hand mesh is divided into six parts: five fingers and the palm. If penetration is detected in the palm area, all the poses are adjusted. If penetration is detected in a finger part and no penetration happens in the palm area, only the partial poses of the finger are adjusted. The loss for the PAP optimization is formulated as:
| Dataset | Methods | Ptr (↓) | SD (↓) | CR (↑) | Div (↑) | GSR (↑) | ||
|---|---|---|---|---|---|---|---|---|
| Dep | Vol | Mean | Var | |||||
| GrabNet [Taheri et al., 2020] | 0.61 | 8.31 | 1.78 | ±2.71 | 98.25 | 7.93 | 27.60 | |
| GraspField [Karunratanakul et al., 2020] | 0.56 | 6.05 | 2.07 | ±2.81 | 89.40 | - | - | |
| Obman GraspTTA [Jiang et al., 2021] | 0.45 | 5.14 | 1.62 | ±2.18 | 99.05 | 8.07 | 47.88 | |
| Ours | 0.44 | 3.94 | 1.60 | ±2.28 | 100.00 | 10.14 | 61.37 | |
| GT | 0.01 | 1.70 | 1.66 | ±2.44 | 100.00 | 7.86 | 87.12 | |
| GrabNet [Taheri et al., 2020] | 0.92 | 16.74 | 1.04 | ±1.60 | 97.42 | 5.92 | 16.89 | |
| ContactPose GraspTTA [Jiang et al., 2021] | 0.79 | 6.01 | 1.52 | ±1.41 | 97.67 | 7.32 | 42.31 | |
| Ours | 0.36 | 4.15 | 1.40 | ±1.98 | 98.85 | 7.91 | 58.97 | |
| GT | 0.51 | 5.91 | 1.06 | ±1.13 | 99.65 | 7.03 | 41.78 | |
Lcst, similar to the contact consistency loss defined above, is the difference between the generated contact map C ′ and the contact map C ′′ . C ′′ is obtained by normalizing the distance between the O and their nearest point inM(θ′p ). Lptr penalizes the penetration between the hand M(θ′p ) and object O as similar in [Jiang et al., 2021] and [Karunratanakul et al., 2020], defined above. Lh = ∥θp - θ′p ∥ regularizes the pose hypothesis θ′p to stay close to the generated pose θp. We set ω0=0.1, ω1=2 and ω2=0.2.
Figure 5 (Left) shows an example of our partial optimization for the poses θp of the finger. During the optimization, as the loss mainly results from local wrong partial poses, the global optimization shown on the right side of Figure 5 has two issues 1) the gradient from local wrong partial poses affects other good poses, 2) the gradient cannot take full effect on the refinement for the wrong partial poses, which together results in many failures of small scale refinement. In contrast, our PAP only optimizes the poses causing the errors to get rid of these issues.
4 Experiment
4.1 Implementation Details
We sample N = 2048 points on an object mesh as the input object point cloud. Our method is trained using a batch size of 32 examples, and an Adam optimizer with a constant learning rate of 1e-4. The training dataset is randomly augmented with [-1, 1]cm translation and rotation at three (XYZ) dimensions. All the experiments were implemented in PyTorch, in which our models ran 130 epochs in a single RTX 3090 GPU with 24GB memory. In the Obman dataset [Hasson et al., 2019], all the ground truth contact map is derived by normalizing the distance between the ground truth of the hand and the object. For the inference refinement (both PAP and global optimization), the Adam optimizer with a learning rate of 2.0 × 10⁻⁴ is used. In the refinement process, each input is optimized for 200 steps.
4.2 Datasets
Obman. We first validate our framework on the Obman dataset [Hasson et al., 2019], which is a large-scale synthetic dataset, including 3D hand interacting with objects. The hands are generated by a physical-based optimization engine GraspIt! [Miller and Allen, 2004], and are parameterized by the MANO model [Romero et al., 2017]. The dataset contains 8 categories of everyday objects selected from ShapeNet [Chang et al., 2015] with a total of 2772 meshes. The model trained on this dataset will benefit from the diversified object models. The object contact map is derived as [Taheri et al., 2020] by thresholding the normalized distance between the object points and their nearest hand vertices. Points with the distance smaller than a threshold are marked as contact points.
ContactPose. The ContactPose dataset [Brahmbhatt et al., 2020] is a real dataset for studying hand-object interaction, which captures both ground-truth thermal contact maps and hand-object poses. Though the dataset contains only 25 household objects and 2306 grasp contacts, it captures more real interactions. For example, the contact in ContactPose spreads across large sections of the hand, as opposed to that at the fingertips for most cases in Obman. We manually split the dataset into a training and test group according to the object type. Specifically, we use 4 objects (cup, toothpaste, stapler, and flashlight) with 336 grasp contacts as a test set, and the rest for training the model. ContactPose uses the thermal camera-based method to capture the contact region.
4.3 EvaluationMetrics
A good generated pose should be physically stable and should be in contact with the object without penetration. In this work, we adopt three metrics to evaluate the quality of generated grasp poses: (1) Penetration (Ptr) The penetration is measured by the depth (Dep, cm) and the volume (Vol, cm3 ) between the objects and generated hand meshes. The depth is the maximum or mean of the distances from the hand mesh vertices to the surface of the object if penetration occurs. Following [Jiang et al., 2021; Karunratanakul et al., 2020], the volume is measured by voxelizing the hand-object mesh with voxel size 0.5cm. (2) Simulation Displacement (SD) The simulation displacement is adopted to measure the stability of the generated grasp. We report the average (Mean, cm) and variance (Var, cm) of the simulation displacement as measured by a physics-based simulator following the same settings as [Jiang et al., 2021; Karunratanakul et al., 2020]. The displacement is the Euclidean distance between the object centers before and after applying a grasp on the object. Though used in the existing work, the results of previous work [Karunratanakul et al., 2020] indicate that a high penetration might correspond to a low simulation value and therefore we suggest readers use it for a rough reference only. (3) Contact Rate (CR, %) A physically plausible hand-object interaction requires contact between the hand and the object. We define a sample as positive if the hand-object contact exists, which means that there exists at least a point on the hand surface is on or inside the surface of the object. The contact rate is the percentage of those positive samples over all the test samples.
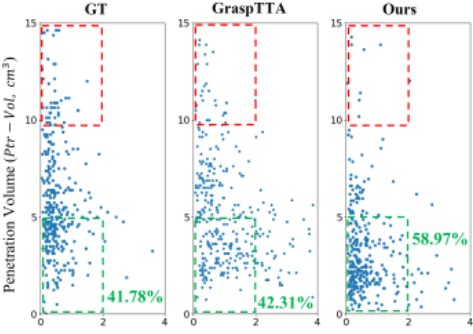
In addition to the metrics used in the hand generation work, we introduce two more metrics to evaluate the quality of the grasping pose distributions. (4) Grasp Success Rate (GSR, %) The grasp success rate aims to evaluate the rate of grasp success. Specifically, we define the positive sample as the one with Ptr-Vol< 5cm3 and SD-Mean < 2cm. The success rate is the percentage of those positive samples over all the test samples. (5) Diversity (Div, cm) It is also significant to evaluate the diversity for the generation task. In this work, we use MAE to measure the diversity of generated results. Specifically, we measure the divergence between each generated sample and all other samples and then average them. The formulation of the metrics mentioned above can be found in the supplementary material (Section B).
4.4 Comparison with State-of-Arts
To illustrate the advantages of the proposed method, we compared our method with three state-of-art methods: GrabNet [Taheri et al., 2020], GraspField [Karunratanakul et al., 2020] and GraspTTA [Jiang et al., 2021]. We train the stateof-art methods on ContactPose using their public code, as they do not provide the results or metrics on this dataset. As for Obman, only the results of GraspField are quoted from [Jiang et al., 2021].
The results on Obman and ContactPose dataset in Table 1 show that our proposed method achieves the best performance on all the metrics. Specifically, our method yields the best penetration depth (0.44cm and 0.36cm) and volume (3.94cm3 and 4.15cm3 ). More importantly, our method achieves the best performance on diversity (10.14cm and 7.91cm) and GSR (61.37% and 58.97%), indicating the robustness and variety of the results generated from our method.
Note that due to the limitation of simulation, grasps with large penetration in many cases can still hold objects while a reasonable grasp pose should embody both low penetration and simulation displacement. Thus the GSR is a more comprehensive metric considering both of them. To verify this, Figure 6 plots penetration volume and simulation displacement of the GT grasps, sampled grasps from GraspTTA [Jiang et al., 2021] and our method for the objects in the testing set of ContactPose. We can see that grasps in the red box of Figure 6 exhibiting larger penetration volume still demonstrate good grasp stability (small simulation displacement). Considering both metrics, the generated grasps from our method are closer to the origin, indicating the results have better stability with smaller penetration (see the comparisons of the green box).
| Methods | Ptr(↓) | SD (↓) | CR (↑)Div (↑)GSR (↑) | ||||
|---|---|---|---|---|---|---|---|
| Dep | Vol | Mean | Var | ||||
| Param2Mesh | 1.0217.18 | 1.14 | ±1.80 | 88.81 | 6.31 | 21.19 | |
| Ours w/o PAP | 0.60 | 7.31 | 1.08 | ±1.18 | 98.85 | 7.40 | 35.71 |
| Ours global opt | 0.58 | 6.67 | 1.58 | ±1.79 | 96.23 | 7.56 | 39.27 |
| Ours | 0.36 | 4.15 | 1.40 | ±1.98 | 98.85 | 7.91 | 58.97 |
| Ours w/o PAP | (GT)0.56 | 6.73 | 0.98 | ±0.97 | 100.00 | 6.79 | 39.94 |
| Ours (GT) | 0.40 | 3.98 | 1.06 | ±1.13 | 99.65 | 7.03 | 65.37 |
4.5 Ablation Study
To verify the effectiveness of our proposed factorization and PAP optimization, we construct three variants of our method and a baseline, comparing their performances on ContactPose test set. The results are shown in Table 2. Param2Mesh: A baseline for grasp generations learning an end-to-end grasp generation model. It learns the latent distribution of MANO parameter directly. Specifically, we use the same architecture of our ContactCVAE to make a fair comparison but replace the encoder Eθe with fully connected layers to take the MANO parameters as inputs. Given a 3D object point cloud and a random sample for the distribution, the decoder Dθd generates MANO parameters directly, which is similar to the previous work [Taheri et al., 2020]. Ours w/o PAP: A variant of our method removing the PAP optimization at the third stage. Ours global opt: A variant of our method simply adopting global refinement at the third stage. Ours (GT) skips ContactCVAE stage, training and testing GraspNet with GT contact maps directly, and Ours w/o PAP (GT) without the PAP optimization.
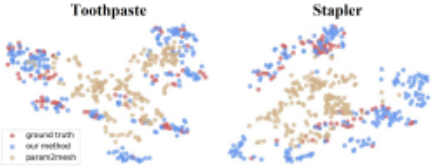
Effectiveness of Factorization. By comparing between Param2Mesh and Ours w/o PAP, we can see that our method achieves significant improvement on all metrics, indicating the effectiveness of the two-stage factorization. Especially, the penetration volume, depth and GSR are improved by 57%, 38% and 68% respectively. In addition, the improvement on diversity (Div) indicates that our method generates more diverse samples. To further demonstrate the diversity and generalization performance of our method, we select two test objects (toothpaste and stapler) of ContactPose and visualize the distribution of generated grasp poses for each of them. As shown in Figure 7, we generate 200 grasp poses with small Ptr-Vol (< 5cm3 ) and SD (< 2cm) for each object, and adopt the t-SNE technique to visualize the distribution of the pose parameters θ. The sample distribution of our method is closer to the distribution of ground truth grasps, indicating better generalization performance. More results are shown in the supplementary material.
Effectiveness of PAP Optimization. By comparing between Ours and Ours (global opt), we can see that our PAP optimization strategy achieves better performance than global refinement over all the metrics, which presents the effectiveness of our PAP optimization.
Quality of Generated Contact Maps. When compared with Our (GT) and Our w/o PAP (GT), the metrics for penetration of our methods (Ours and Our w/o PAP) are worse but the margin of corresponding improvement is relatively small. For example, the penetration depth of our methods are 0.36mm and 0.60mm while those of Our (GT) and Our w/o PAP (GT) are 0.40mm and 0.56mm. The comparison indicates the generated maps in the first stage are of high quality.
The examples in Figure 8 also show that the generated contacts convey meaningful information for grasping. We can observe that the generated contact map is reasonable, corresponding to the grasp pose. Although there are some failure examples (including unstable grasps and serious penetration), the hand pose is substantially natural as human behavior.
Semantic Analysis of Latent Contact Map Space. Using the generated object contacts to formulate the hand grasp is one of the contributions and here we show whether our ContactCVAE model can learn the latent distribution for contact well. In point generation work [Achlioptas et al., 2018], it demonstrates the quality of the generation model by showing that the learned representation is amenable to intuitive and semantically rich operations. Inspired by the work, we conduct the semantic analysis of the latent space learned from our ContactCVAE model. The detail of the procedure can be found in the supplementary material (Section D).
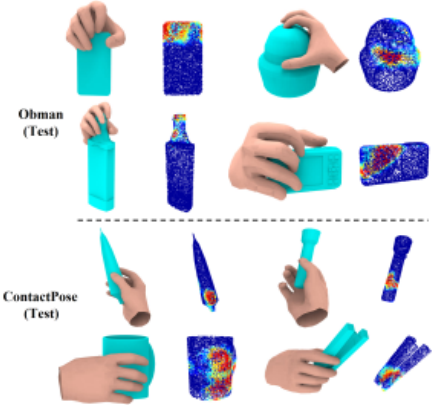
Figure 1 exemplifies the contact maps and grasping poses generated by interpolating the latent z of the contact maps for TypeA and TypeB. Notice that the grasps change gradually in alignment with the contact maps between Type A and Type B. For example, in Figure 1 (bottom), the yellow arrow and circle on the mouse, denote small differences between the contact maps and the grasp poses. As the contact region gradually appears, the middle finger moves to the corresponding position smoothly. Similar interesting observation can be found for manipulating the phone in Figure 1 (top) where the hand poses change from holding to pressing gradually.
5 Conclusion
In this paper, we propose a novel framework for human grasps generation, which holds the potential for different deep architectures. The highlight of this work is exploiting the object affordance represented by the contact map, to formulate a functionality-oriented grasp pose and using penetrationaware partial optimization to refine partial-penetrated poses without hurting good-quality ones. The proposed method is extensively validated on two public datasets. In terms of diversity and stability, both quantitative and qualitative evaluations support that, our method has clear advantages over other strong competitors in generating high-quality human grasps.
Although our method achieves great performance over all the metrics, limitations still exist. In some cases, the generated contact maps are ambiguous, resulting in more than one plausible grasping pose. Therefore, our assumption of the grasp is fully constrained by the contact map does not hold. Contact maps with more detailed hand-part segmentation can provide stronger constraints and help to reduce ambiguity.
Acknowledgments
This work was supported in part by NSFC under Grants (No. 62103372, 62088101, and 62233013), PI funding of Zhejiang Lab (No. 121005-PI2101), Key Research Project of Zhejiang Lab (No. K2022PG1BB01), and OPPO Research Fund.
@inproceedings{ijcai2023p117,
  title     = {Contact2Grasp: 3D Grasp Synthesis via Hand-Object Contact Constraint},
  author    = {Li, Haoming and Lin, Xinzhuo and Zhou, Yang and Li, Xiang and Huo, Yuchi and Chen, Jiming and Ye, Qi},
  booktitle = {Proceedings of the Thirty-Second International Joint Conference on
               Artificial Intelligence, {IJCAI-23}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Edith Elkind},
  pages     = {1053--1061},
  year      = {2023},
  month     = {8},
  note      = {Main Track},
  doi       = {10.24963/ijcai.2023/117},
  url       = {https://doi.org/10.24963/ijcai.2023/117},
}
TY - CPAPER TI - Contact2Grasp: 3D Grasp Synthesis via Hand-Object Contact Constraint AU - Li, Haoming AU - Lin, Xinzhuo AU - Zhou, Yang AU - Li, Xiang AU - Huo, Yuchi AU - Chen, Jiming AU - Ye, Qi T2 - Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence, IJCAI-23 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2023 SP - 1053 EP - 1061 DO - 10.24963/ijcai.2023/117 UR - https://doi.org/10.24963/ijcai.2023/117 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





