
Scalable Anytime Planning for Multi-Agent MDPs (Extended Abstract)
Proceedings of the Thirty-First International Joint Conference on Artificial Intelligence. Sister Conferences Best Papers. Pages 5279-5283.
https://doi.org/10.24963/ijcai.2022/735
Keywords
- Artificial Intelligence: General
Abstract
We present a scalable planning algorithm for multi-agent sequential decision problems that require dynamic collaboration.
Teams of agents need to coordinate decisions in many domains,
but naive approaches fail due to the exponential growth of the joint action space with the number of agents.
We circumvent this complexity through an anytime approach that allows us to trade computation for
approximation quality and also dynamically coordinate actions.
Our algorithm comprises three elements: online planning with Monte Carlo
Tree Search (MCTS), factorizing local agent interactions with coordination graphs, and
selecting optimal joint actions with the Max-Plus method.
On the benchmark SysAdmin domain with static coordination graphs, our approach achieves comparable performance with much lower computation cost than the MCTS baselines.
We also introduce a multi-drone delivery domain with dynamic, i.e., state-dependent coordination graphs, and demonstrate how our approach scales to large problems on this domain that are intractable for other MCTS methods.
- [Amato and Oliehoek, 2014] Christopher Amato and Frans A Oliehoek. Scalable Planning and Learning for Mul- tiagent POMDPs: Extended version. arXiv preprint arXiv:1404.1140, 2014.
- [Bertsekas, 2005] Dimitri P Bertsekas. Dynamic Program- ming and Optimal Control, volume 1. Athena Scientific Belmont, MA, 2005.
- [Bezanson et al., 2017] Jeff Bezanson, Alan Edelman, Stefan Karpinski, and Viral B Shah. Julia: A Fresh Approach to Numerical Computing. SIAM Review, 59(1):65-98, 2017.
- [Boutilier, 1996] Craig Boutilier. Planning, Learning and Co- ordination in Multi-Agent Decision Processes. In Pro- ceedings of the Sixth Conference on Theoretical Aspects of Rationality and Knowledge, pages 195-210.
- [Browne et al., 2012] Cameron Browne, Edward Jack Pow- ley, Daniel Whitehouse, Simon M. Lucas, Peter I. Cowl- ing, Philipp Rohlfshagen, Stephen Tavener, Diego Perez Liebana, Spyridon Samothrakis, and Simon Colton. A Survey of Monte Carlo Tree Search Methods. IEEE Trans- actions on Computational Intelligence and AI in games, 4(1):1-43, 2012.
- [Chaslot et al., 2008] Guillaume M J-B Chaslot, Mark HM Winands, H Jaap van den Herik, Jos WHM Uiterwijk, and Bruno Bouzy. Progressive Strategies for Monte-Carlo Tree Search. New Mathematics and Natural Computation, 4(3):343-357, 2008.
- [Choudhury et al., 2020] Shushman Choudhury, Kiril Solovey, Mykel J. Kochenderfer, and Marco Pavone. Efficient Large-Scale Multi-Drone Delivery using Transit Networks. In IEEE International Conference on Robotics and Automation (ICRA), 2020.
- [Choudhury et al., 2021] Shushman Choudhury, Jayesh K Gupta, Peter Morales, and Mykel J Kochenderfer. Scalable Anytime Planning for Multi-Agent MDPs. arXiv preprint arXiv:2101.04788, 2021.
- [Guestrin et al., 2002] Carlos Guestrin, Daphne Koller, and Ronald Parr. Multiagent Planning with Factored MDPs. In T G Dietterich, S Becker, and Z Ghahramani, editors, Advances in Neural Information Processing Systems, pages 1523-1530. MIT Press, 2002.
- [Guestrin et al., 2003] C. Guestrin, D. Koller, R. Parr, and S. Venkataraman. Efficient Solution Algorithms for Fac- tored MDPs. Journal of Artificial Intelligence Research, 19:399-468, October 2003.
- [Gupta et al., 2017] Jayesh K Gupta, Maxim Egorov, and Mykel J. Kochenderfer. Cooperative Multi-Agent Con- trol using Deep Reinforcement Learning. In International Conference on Autonomous Agents and Multiagent Systems (AAMAS), pages 66-83. Springer, 2017.
- [Kochenderfer, 2015] Mykel J. Kochenderfer. Decision Mak- ing under Uncertainty: Theory and Application. MIT Press, 2015.
- [Kocsis and Szepesvári, 2006] Levente Kocsis and Csaba Szepesvári. Bandit based monte-carlo planning. In Eu- ropean Conference on Machine Learning (ECML), volume 4212, pages 282-293. Springer, 2006.
- [Kok and Vlassis, 2004] Jelle R Kok and Nikos Vlassis. Sparse Cooperative Q-Learning. In International Confer- ence on Machine Learning (ICML), page 61. ACM, 2004.
- [Kok and Vlassis, 2005] Jelle R. Kok and Nikos A. Vlassis. Using the Max-Plus Algorithm for Multi-Agent Decision Making in Coordination Graphs. In Proceedings of the Seventeenth Belgium-Netherlands Conference on Artificial Intelligence (BNAIC), pages 359-360, 2005.
- [Matignon et al., 2012] Laetitia Matignon, Guillaume J. Lau- rent, and Nadine Le Fort-Piat. Independent Reinforcement Learners in Cooperative Markov Games: a Survey Regard- ing Coordination Problems. The Knowledge Engineering Review, 27(1):1-31, 2012.
- [Nijssen and Winands, 2011] J. A. M. Nijssen and Mark H. M. Winands. Enhancements for Multi-Player Monte- Carlo Tree Search. In Computers and Games, 2011.
- [Oh et al., 2015] Kwang-Kyo Oh, Myoung-Chul Park, and Hyo-Sung Ahn. A Survey of Multi-Agent Formation Con- trol. Automatica, 53:424-440, 2015.
- [Oliehoek et al., 2008] Frans A. Oliehoek, Matthijs T. J. Spaan, et al. Exploiting Locality of Interaction in Fac- tored Dec-POMDPs. In International Conference on Au- tonomous Agents and Multiagent Systems (AAMAS), pages 517-524. International Foundation for Autonomous Agents and Multiagent Systems, 2008.
- [Pearl, 1989] Judea Pearl. Probabilistic Reasoning in Intel- ligent Systems: Networks of Plausible Inference. Morgan Kaufmann, 1989.
- [Rashid et al., 2018] Tabish Rashid, Mikayel Samvelyan, Christian Schroeder, Gregory Farquhar, Jakob Foerster, and Shimon Whiteson. QMIX: Monotonic Value Function Fac- torisation for Deep Multi-Agent Reinforcement Learning. In International Conference on Machine Learning (ICML), pages 4295-4304, 2018.
- [Silver and Veness, 2010] David Silver and Joel Veness. Monte-Carlo Planning in Large POMDPs. In Advances in Neural Information Processing Systems (NeurIPS), pages 2164-2172.
- Curran Associates, Inc., 2010.
- [Sunehag et al., 2018] Peter Sunehag, Guy Lever, Audrunas Gruslys, Wojciech Marian Czarnecki, et al. Value- Decomposition Networks for Cooperative Multi-Agent Learning based on Team Reward. In International Con- ference on Autonomous Agents and Multiagent Systems (AAMAS), pages 2085-2087, 2018.
- [Vlassis et al., 2004] N Vlassis, R Elhorst, and J R Kok. Any- time Algorithms for Multiagent Decision Making using Coordination Graphs. In IEEE International Conference on Systems, Man and Cybernetics (IEEE Cat. No.04CH37583), volume 1, pages 953-957 vol.1, October 2004.
- [Zerbel and Yliniemi, 2019] Nicholas Zerbel and Logan Yliniemi. Multiagent Monte Carlo Tree Search. In Interna- tional Conference on Autonomous Agents and Multiagent Systems (AAMAS), pages 2309-2311, 2019.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Coordination is crucial for decision-making in multi-agent systems with a shared objective. Real-world problems like formation control [Oh et al., 2015], package delivery [Choudhury et al., 2020], and firefighting [Oliehoek et al., 2008] require a team of autonomous agents to perform a common task. Such cooperative sequential settings can be modeled as a Multi-Agent Markov Decision Process (MMDP) [Boutilier, 1996], an extension of the Markov Decision Process (MDP) [Kochenderfer, 2015]. MMDPs can be reduced to centralized single-agent MDPs with a joint action space for all agents. Such reductions often make large problems intractable because the action space grows exponentially with the number of agents. Solving independent MDPs for all agents, however, can yield arbitrarily sub-optimal behavior in problems that need coordination [Matignon et al., 2012].
∗This paper is an extended abstract of the Best Paper at Autonomous Agents and Multi-Agent Systems (AAMAS) 2022.
Many previous MMDP approaches have tried to balance these extremes of optimality and efficiency. In the offline setting, these include ad hoc function decomposition approaches, such as Value Decomposition Networks [Sunehag et al., 2018] and QMIX [Rashid et al., 2018], or parameter sharing in decentralized policy optimization [Gupta et al., 2017]. [Guestrin et al., 2002] introduced the concept of a coordination graph to reason about joint value estimates from a factored representation, while [Kok and Vlassis, 2004] used approximations to scale these ideas to larger problems. Monte Carlo Tree Search (MCTS) [Browne et al., 2012], a common approach to online planning, has been combined with coordination graphs in Factored Value MCTS [Amato and Oliehoek, 2014]. However, Factored Value MCTS coordinates actions with an exact Variable Elimination (Var-El) step, which conflicts with the anytime nature of MCTS planning.
The key idea of this paper is to recover the anytime nature of MCTS planning for MMDPs requiring coordination and also scale to larger teams of agents. To that end, we propose combining Max-Plus action selection, introduced by [Vlassis et al., 2004], with the factored value MCTS of [Amato and Oliehoek, 2014]. We do so for many reasons. Unlike Var-El, which is exact, Max-Plus is an iterative procedure and allows for truly anytime behavior that can trade computation for approximation quality. The representation of Max-Plus is much more efficient than that of Var-El for using dynamic, i.e., state-dependent, coordination graphs (state-dependent datastructures are a key benefit of online planning for MDPs). Finally, Max-Plus can scale to much larger and denser coordination graphs than Var-El, and it can be distributed for additional scalability [Kok and Vlassis, 2005].
We present a scalable anytime MMDP planning algorithm called Factored Value MCTS with Max-Plus. On the standard SysAdmin benchmark domain [Guestrin et al., 2002], with static coordination graphs, we demonstrate that our approach performs as well as or better than Factored Value MCTS with Var-El [Amato and Oliehoek, 2014] and is much faster for the same tree search hyperparameters. We also introduce a new MMDP domain, Multi-Drone Delivery, with dynamic coordination graphs. On the second domain, we show how our approach scales to problem sizes that are entirely intractable for other MCTS variants, while also achieving better performance on smaller problem sizes. The extended version (with code) is available at https://sites.google.com/stanford.edu/fvmcts/.
2 Background: Online MMDP Planning
The goal of MDP planning is to obtain a policy, π : S → A that specifies what action a the agent should take from its current state s to maximize its value, i.e. its expected cumulative reward. We consider decision-making settings where multiple agents cooperate under a shared reward function [Boutilier, 1996], i.e., Multi-Agent MDPs or MMDPs. Here, each agent takes an individual action and the planning algorithm observes states of all agents. Both offline and online methods exist for computing policies for MMDPs [Bertsekas, 2005].
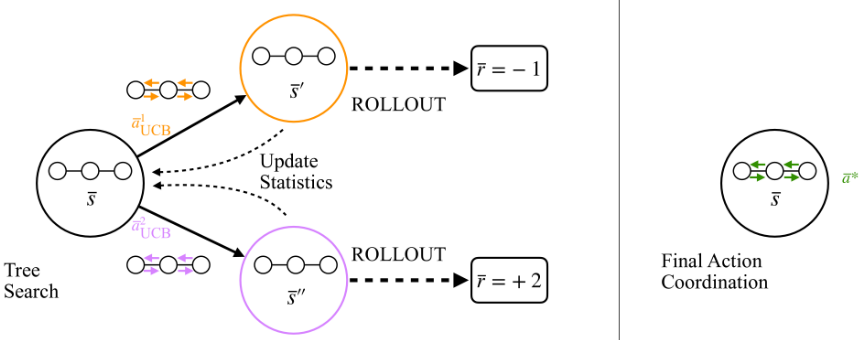
Online methods (the focus of our work) interleave planning and execution by focusing only on states that are reachable for the current state, while computing the next action to take. Monte Carlo Tree Search (MCTS) is the predominant framework for online planning and has succeeded in a variety of domains [Browne et al., 2012], including in multi-agent contexts [Nijssen and Winands, 2011; Zerbel and Yliniemi, 2019]. The anytime nature of MCTS (search depth and number of simulations) allows us to trade computation time for approximation quality. However, the exponentially large action space of MMDPs can still be a bottleneck for the naive application of MCTS techniques [Chaslot et al., 2008].
Several real-world multi-agent systems demonstrate locality of interaction, i.e. the outcome of an agent's action depends only on a subset of other agents. The coordination graph (CG) structure is often used to encode such interactions [Guestrin et al., 2002]. A CG for a multi-agent system has one node per agent, and edges connect agents if their payoffs depend on each other. The CG structure induces a set of payoff components, where each component is associated with a clique, i.e., a subset of agents that are all mutually connected.
For CGs in multi-agent settings, we assume that we can factor the global payoff for a joint action as the sum of local component payoffs, i.e., Q(a) = ∑c Qc(ac), where a is the global joint action, and ac is the local component action (the projection of a corresponding to component c). Given this factored representation and the local component payoffs, we can compute the best joint action, argmaxa Q(a), with the Variable Elimination (Var-El) algorithm originating from the probabilistic inference literature [Guestrin et al., 2003]. The optimal joint action in a CG is equivalent to the maximum a posteriori configuration in an undirected probabilistic graphical model [Vlassis et al., 2004].
We build upon an online MMDP planning algorithm that combines the idea of coordination graphs and factored values with MCTS [Amato and Oliehoek, 2014]. Monte Carlo planning estimates quantities by exploring from the current state and gathering relevant statistics through interactions with a simulated generative model of the environment [Silver and Veness, 2010]. These statistics typically track the average simulated reward obtained for trying an individual or joint action, the frequency of action attempts for Upper Confidence Bound or UCB exploration [Kocsis and Szepesv´ari, 2006], and the number of occurences of the individual or joint state.
[Amato and Oliehoek, 2014] maintain local component statistics, i.e. the mean payoff of a local component action ae and the number of times it was attempted in that component; they call this mixture of experts optimization, albeit with a simple maximum likelihood estimator expert. Given these statistics, their approach computes the best joint action at the next time-step through Variable Elimination over the CG. Consequently, it loses the anytime property of MCTS because exact variable elimination cannot be stopped at an intermediate step. Although [Vlassis et al., 2004] explored various anytime algorithms for action selection with coordination graphs, they did not investigate their interaction with online planning algorithms like MCTS.
3 Factored-Value MCTS withMax-Plus
We now discuss our method for anytime multi-agent MDP planning with coordination graphs, Factored-Value Monte Carlo Tree Search with Max-Plus. To apply the mixture of experts optimization (discussed previously) to each node of the search tree, we must define the factored statistics to maintain for each node. Given a potentially state-dependent undirected coordination graph (CG), G = ⟨V, E⟩, we factor the CGinduced global payoff at the current state, s, as follows:
Here, Qij is a local payoff function for agents i and j connected by edge (i, j), while Qi is an individual utility function for agent i, if applicable to the domain. All state-dependent quantities in this section's equations are implicitly for the current joint state s.
Exploiting the duality between computing the maximum a posteriori configuration in a probabilistic graphical model and the optimal joint action in a CG, [Vlassis et al., 2004] introduced the Max-Plus algorithm for computing the joint action via message passing. Each node, i.e., agent, iteratively dispatches messages to its neighbours j ∈ Γ(i) in the CG. A message from agent i is a scalar-valued function of the action space of receiving agent j, i.e.,
where Γ(i) is the set of neighbors of i. Agents exchange messages until convergence or for some number of rounds. Finally, each agent computes its optimal action individually,
Max-Plus is equivalent to belief propagation in graphical models [Pearl, 1989] and its time complexity scales linearly with the CG size (the number of edges); it is more suitable for realtime systems and more tractable for large numbers of agents than Var-El.
3.1 UCB Exploration withMax-Plus
The key implementation issue for extending MCTS to factored value functions and coordination graphs is that of action exploration as per the Upper Confidence Bound (UCB) strategy. In the Var-El case, [Amato and Oliehoek, 2014] added the exploration bonus using component-wise statistics during each elimination step. We cannot apply this strategy with Max-Plus as it does not use components. In contrast, it has two distinct phases of computation. The first is message passing per edge in Equation (2), followed by action selection per node in Equation (1). We use these two phases to define how our algorithm explores the action space.
Edge Exploration: Analogous to the edge payoff statistics Qij , we keep track of corresponding frequency statistics Nai,aj (for pairwise actions). The natural exploration strategy over edges is to add the bonus to Equation (2) as follows:
Adding this bonus during the message passing rounds can cause divergence for cyclic graphs with any cycle of length less than the number of rounds. The bonuses accumulate in successive rounds for messages in either direction along the cycle, making the effective bonus proportional to the total number of rounds (divided by cycle length). Therefore, we only augment each message once after the final round of message passing.
Node Exploration: We maintain individual action frequency statistics Nai and modify Equation (1) to add a node exploration bonus during the action selection:
Note that the joint-action payoff Q(a) can be factorized over the CG nodes and edges as in Equation (1), but the jointaction exploration bonus c√ logN(s) N(s,a) cannot. Therefore, the node and edge exploration strategies we have defined here are heuristic choices that we make and evaluate empirically through an ablation. Our exploration strategies differ from the component-wise exploration in the previous work that uses Var-El, because we do not consider cliques/components in the CG, only nodes and edges.
4 Experiments and Results
We used cumulative discounted return as the primary metric to evaluate our approach, Factored Value MCTS with Max-Plus (FV-MCTS-MP). Our most relevant baseline is Factored Value MCTS with Variable Elimination (FV-MCTS-Var-El). We also compared against standard MCTS (with no factorization), independent Q-learning (IQL), and a random policy. Besides performance, we also measured the MCTS computation time with increasing problem size. The extended conference version [Choudhury et al., 2021] examines the effect of different hyperparameters on both variants of FV-MCTS and of different action exploration schemes on FV-MCTS-MP. Both of our experimental domains represent a range of MMDP problems and underlying CGs. All implementations and simulations are in Julia [Bezanson et al., 2017].
4.1 SysAdmin Domain
Our first domain is a standard MMDP benchmark: SysAdmin [Guestrin et al., 2003]. Each agent i represents a machine in a network with two state variables: Status Si ∈ {GOOD, FAULTY, DEAD}, and Load Li ∈ {IDLE, LOADED, SUCCESS}. A DEAD machine increases the probability that its neighbor also dies. The system gets a reward of 1 if a process terminates successfully, processes take longer when status is FAULTY, and a DEAD machine loses the process. Each agent must decide whether to reboot its machine, in which case the Status becomes GOOD and any running process is lost. The discount factor, γ used in all the experiments is 0.9. All evaluations have been averaged over 40 runs.
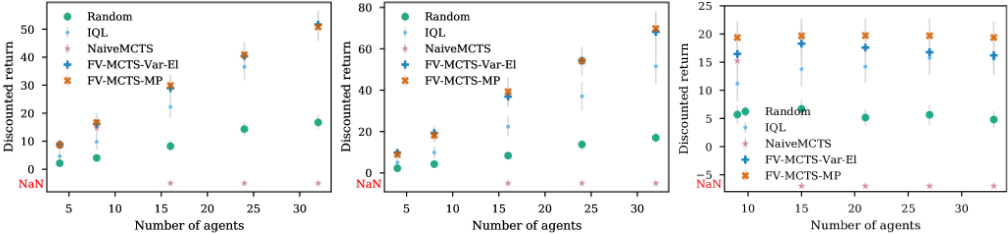
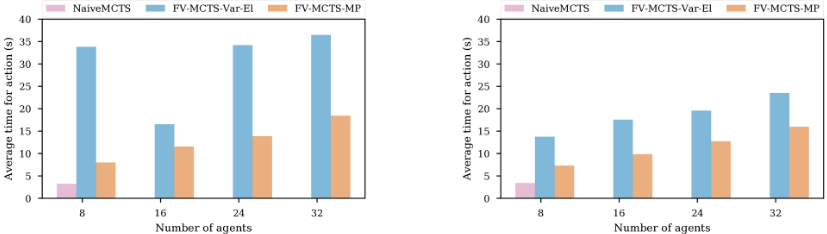
For all SysAdmin topologies, we varied the number of machines (agents) and compared the performance of all methods in Figure 2. With fewer agents, all MCTS methods perform similarly to each other. However, Factored Value MCTS methods are able to scale with increasing number of agents. Both FV-MCTS variants perform comparably on larger problems with a slight edge for MaxPlus variant on ring-of-ring topology. However, as shown in Figure 3, FV-MCTS-Var-El is consistently much slower than FV-MCTS-MP, e.g., taking approximately 35s versus 16s for 32 agents on a single-threaded implementation in the ring topology.
4.2 Multi-Drone Delivery Domain
We introduce an MMDP domain that simulates a team of delivery drones navigating a shared operation space to reach their specified goal regions. Our domain requires multiple drones assigned to the same goal to arrive within a short time window of each other. The MMDP is episodic and terminates only when all drones have reached their goal locations. Unlike typical MMDP domains used in prior work, Multi-Drone Delivery encode dynamic or state-dependent coordination graphs; any two drones benefit from coordination only when they are close to each other, . Therefore, at the current joint state, we assign a CG edge between any two drones whose mutual distance is lower than a resolution-dependent threshold.
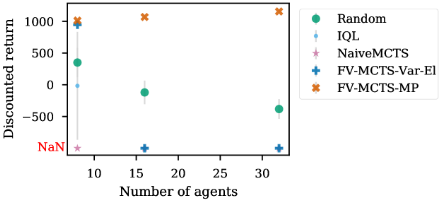
As with SysAdmin, we varied the number of drones (agents) and compared against all baselines in Figure 4. Given the large action space per-agent, neither naive MCTS nor FV-MCTSVar-El was able to scale to larger number of agents. Var-El's restriction to static CGs leads to slightly worse performance with 8 agents while FV-MCTS-MP is able to successfully solve tasks even with 32 agents. Moreover, even on the 8 agent problem, FV-MCTS-MP is much faster, taking on average approximately 1s instead of 40s for FV-MCTS-Var-EL for the same tree search hyperparameters.
5 Conclusion
We introduced a scalable online planning algorithm for MultiAgent MDPs with dynamic coordination graphs. Our approach uses Max-Plus for action coordination, in contrast to the previous approach that used Variable Elimination. Over the SysAdmin and Multi-Drone Delivery domains, we demonstrated that our approach performs as well as baselines on static CGs, outperforms them significantly on dynamic CGs, and is far more computationally efficient (enabling online MMDP planning on previously intractable problems).
@inproceedings{ijcai2022p735,
  title     = {Scalable Anytime Planning for Multi-Agent MDPs (Extended Abstract)},
  author    = {Choudhury, Shushman and Gupta, Jayesh K. and Kochenderfer, Mykel J.},
  booktitle = {Proceedings of the Thirty-First International Joint Conference on
               Artificial Intelligence, {IJCAI-22}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Luc De Raedt},
  pages     = {5279--5283},
  year      = {2022},
  month     = {7},
  note      = {Sister Conferences Best Papers},
  doi       = {10.24963/ijcai.2022/735},
  url       = {https://doi.org/10.24963/ijcai.2022/735},
}
TY - CPAPER TI - Scalable Anytime Planning for Multi-Agent MDPs (Extended Abstract) AU - Choudhury, Shushman AU - Gupta, Jayesh K. AU - Kochenderfer, Mykel J. T2 - Proceedings of the Thirty-First International Joint Conference on Artificial Intelligence, IJCAI-22 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2022 SP - 5279 EP - 5283 DO - 10.24963/ijcai.2022/735 UR - https://doi.org/10.24963/ijcai.2022/735 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





