
Algorithmic Motion Planning Meets Minimially-Invasive Robotic Surgery
Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence. Early Career. Pages 7039-7044.
https://doi.org/10.24963/ijcai.2023/804
Keywords
- EC: Robot Motion Planning
Abstract
Robots for minimally-invasive surgery such as steerable needles and concentric-tube robots have the potential to dramatically alter the way common medical procedures are performed. They can decrease patient-recovery time, speed healing and reduce scarring. However, manually controlling such devices is highly un-intuitive and automatic planning methods are in need. For the automation of such medical procedures to be clinically accepted, it is critical from a patient care, safety, and regulatory perspective to certify the correctness and effectiveness of the motion-planning algorithms involved in procedure automation. In this paper, I survey recent and ongoing work where we develop efficient and effective planning capabilities for medical robots that provide provable guarantees on various planner attributes as well as introduce new and exciting research opportunities in the field.
- [Abolhassani et al., 2007] Niki Abolhassani, Rajni Patel, and Mehrdad Moallem. Needle insertion into soft tissue: A survey. Medical Engineering & Physics, 29(4):413- 431, 2007.
- [Almadhoun et al., 2016] Randa Almadhoun, Tarek Taha, Lakmal Seneviratne, Jorge Dias, and Guowei Cai. A sur- vey on inspecting structures using robotic systems. In- ternational Journal of Advanced Robotic Systems, 13(6), 2016.
- [Alterovitz and Goldberg, 2008] Ron Alterovitz and Ken- neth Y. Goldberg. Motion Planning in Medicine: Op- timization and Simulation Algorithms for Image-Guided Procedures, volume 50 of Springer Tracts in Advanced Robotics. Springer, 2008.
- [Alterovitz et al., 2003] Ron Alterovitz, Kenneth Y. Gold- berg, Jean Pouliot, Richard Tascherau, and I-Chow Hsu. Needle insertion and radioactive seed implantation in hu- man tissues: simulation and sensitivity analysis. In ICRA, pages 1793-1799, 2003.
- [Anderson et al., 2017] Patrick L Anderson, Arthur W Ma- honey, and Robert J Webster III. Continuum reconfig- urable parallel robots for surgery: Shape sensing and state estimation with uncertainty. IEEE Robot. Autom. Lett., 2(3):1617-1624, 2017.
- [Ashraf et al., 2018] Omar Ashraf, Nitesh V. Patel, Simon Hanft, and Shabbar F. Danish. Laser-Induced Thermal Therapy in Neuro-Oncology: A Review. World Neuro- surgery, 112:166-177, April 2018.
- [Barraquand and Latombe, 1993] Jérôme Barraquand and Jean-Claude Latombe. Nonholonomic multibody mobile robots: Controllability and motion planning in the pres- ence of obstacles. Algorithmica, 10(2):121-155, 1993.
- [Bentley et al., 2021] Michael Bentley, D. Caleb Rucker, Chakravarthy Reddy, Oren Salzman, and Alan Kuntz. A novel shaft-to-tissue force model for safer motion planning of steerable needles. CoRR, abs/2101.02246, 2021.
- [Berenson et al., 2009] D. Berenson, S.S. Srinivasa, D. Fer- guson, and J. Kuffner. Manipulation planning on con- straint manifolds. In ICRA, pages 625-632, 2009.
- [Bircher et al., 2015] Andreas Bircher, Kostas Alexis, Michael Burri, Philipp Oettershagen, Sammy Omari, Thomas Mantel, and Roland Siegwart. Structural inspec- tion path planning via iterative viewpoint resampling with application to aerial robotics. In ICRA, pages 6423-6430. IEEE, 2015.
- [Bircher et al., 2017] Andreas Bircher, Kostas Alexis, Ulrich Schwesinger, Sammy Omari, Michael Burri, and Roland Siegwart. An incremental sampling-based approach to in- spection planning: The rapidly-exploring random tree of trees. Robotica, 35(6):1327-1340, 2017.
- [Bogaerts et al., 2018] Boris Bogaerts, Seppe Sels, Steve Vanlanduit, and Rudi Penne. A gradient-based inspection path optimization approach. IEEE Robot. Autom. Lett., 3(3):2646-2653, 2018.
- [Burgner-Kahrs et al., 2015] Jessica Burgner-Kahrs, D. Caleb Rucker, and Howie Choset. Continuum robots for medical applications: A survey. IEEE Trans. Rob., 31(6):1261-1280, 2015.
- [Dayan et al., 2021] Dror Dayan, Kiril Solovey, Marco Pavone, and Dan Halperin. Near-optimal multi-robot mo- tion planning with finite sampling. In ICRA, pages 9190- 9196, 2021.
- [Englot and Hover, 2011] Brendan J Englot and Franz S Hover. Planning complex inspection tasks using redundant roadmaps. In ISRR, pages 327-343, 2011.
- [Favaro et al., 2018] Alberto Favaro, Leonardo Cerri, Ste- fano Galvan, Ferdinando Rodriguez Y Baena, and Elena De Momi. Automatic optimized 3D path planner for steer- able catheters with heuristic search and uncertainty toler- ance. In ICRA, pages 9-16. IEEE, 2018.
- [Favaro et al., 2021] Alberto Favaro, Alice Segato, Federico Muretti, and Elena De Momi. An evolutionary-optimized surgical path planner for a programmable bevel-tip needle. IEEE Trans. Rob., 37(4):1039-1050, 2021.
- [Fu et al., 2018] Mengyu Fu, Alan Kuntz, Robert J Web- ster III, and Ron Alterovitz. Safe motion planning for steerable needles using cost maps automatically extracted from pulmonary images. In IROS, pages 4942-4949. IEEE, 2018.
- [Fu et al., 2019] Mengyu Fu, Alan Kuntz, Oren Salzman, and Ron Alterovitz. Toward asymptotically-optimal in- spection planning via efficient near-optimal graph search. In RSS, 2019.
- [Fu et al., 2021a] Mengyu Fu, Oren Salzman, and Ron Al- terovitz. Computationally-efficient roadmap-based inspec- tion planning via incremental lazy search. In ICRA, pages 7449-7456, 2021.
- [Fu et al., 2021b] Mengyu Fu, Oren Salzman, and Ron Al- terovitz. Toward certifiable motion planning for medical steerable needles. In RSS, 2021.
- [Fu et al., 2022] Mengyu Fu, Kiril Solovey, Oren Salzman, and Ron Alterovitz. Resolution-optimal motion planning for steerable needles. In ICRA, pages 9652-9659, 2022.
- [Galceran and Carreras, 2013] Enric Galceran and Marc Carreras. A survey on coverage path planning for robotics. Robotics and Autonomous Systems, 61(12):1258-1276, 2013.
- [Gilbert et al., 2013] H. Gilbert, D. Rucker, and R. J. Web- ster III. Concentric tube robots: The state of the art and future directions. In ISRR, pages 253-269, 2013.
- [Holladay et al., 2019] Rachel M. Holladay, Oren Salzman, and Siddhartha S. Srinivasa. Minimizing task-space fréchet error via efficient incremental graph search. IEEE Robot. Autom. Lett., 4(2):1999-2006, 2019.
- [Kafka et al., 2016] Přemysl Kafka, Jan Faigl, and Petr Váňa. Random inspection tree algorithm in visual inspec- tion with a realistic sensing model and differential con- straints. In ICRA, pages 2782-2787, 2016.
- [Karaman and Frazzoli, 2011] Sertac Karaman and Emilio Frazzoli. Sampling-based algorithms for optimal motion planning. Int. J. of Rob. Res. , 30(7):846-894, 2011.
- [Kleinbort et al., 2020] Michal Kleinbort, Edgar Granados, Kiril Solovey, Riccardo Bonalli, Kostas E Bekris, and Dan Halperin. Refined analysis of asymptotically-optimal kin- odynamic planning in the state-cost space. In ICRA, pages 6344-6350. IEEE, 2020.
- [Knavel and Brace, 2013] Erica M. Knavel and Christo- pher L. Brace. Tumor ablation: Common modalities and general practices. Techniques in Vascular and Interven- tional Radiology, 16(4):192-200, December 2013.
- [Kuntz et al., 2015] Alan Kuntz, Luis G Torres, Richard H Feins, Robert J Webster III, and Ron Alterovitz. Motion planning for a three-stage multilumen transoral lung ac- cess system. In IROS, pages 3255-3261. IEEE, 2015.
- [Kuntz et al., 2018] Alan Kuntz, Chris Bowen, Cenk Baykal, Arthur W Mahoney, Patrick L Anderson, Fabien Maldon- ado, Robert J Webster III, and Ron Alterovitz. Kinematic design optimization of a parallel surgical robot to maxi- mize anatomical visibility via motion planning. In ICRA, pages 926-933, 2018.
- [LaValle, 2006] Steven M LaValle. Planning algorithms. Cambridge university press, 2006.
- [Liu et al., 2016] Fangde Liu, Arnau Garriga-Casanovas, Riccardo Secoli, and Ferdinando Rodriguez y Baena. Fast and adaptive fractal tree-based path planning for pro- grammable bevel tip steerable needles. IEEE Robot. Au- tom. Lett., 1(2):601-608, 2016.
- [Lonser et al., 2020] Russell R. Lonser, Asad S. Akhter, Mirosław Zabek, J. Bradley Elder, and Krystof S. Bankiewicz. Direct convective delivery of adeno- associated virus gene therapy for treatment of neurologi- cal disorders. Journal of Neurosurgery, pages 1-13, July 2020.
- [Mahoney et al., 2016] Arthur W Mahoney, Patrick L An- derson, Philip J Swaney, Fabien Maldonado, and Robert J Webster III. Reconfigurable parallel continuum robots for incisionless surgery. In IROS, pages 4330-4336, 2016.
- [Niyaz et al., 2018] S. Niyaz, A. Kuntz, O. Salzman, R. Al- terovitz, and S. S. Srinivasa. Following surgical trajecto- ries with concentric tube robots. In ISER, 2018.
- [Niyaz et al., 2019] S. Niyaz, A. Kuntz, O. Salzman, R. Al- terovitz, and S. S. Srinivasa. Optimizing motion-planning problem setup via bounded evaluation with application to following surgical trajectories. In IROS, 2019.
- [Patil et al., 2014] Sachin Patil, Jessica Burgner, Robert J Webster III, and Ron Alterovitz. Needle steering in 3D via rapid replanning. IEEE Trans. Rob., 30(4):853-864, 2014.
- [Pinzi et al., 2019] Marlene Pinzi, Stefano Galvan, and Fer- dinando Rodriguez y Baena. The adaptive hermite frac- tal tree (AHFT): a novel surgical 3D path planning ap- proach with curvature and heading constraints. Inter- national Journal of Computer Assisted Radiology and Surgery, 14(4):659-670, 2019.
- [Pinzi et al., 2021] Marlene Pinzi, Thomas Watts, Riccardo Secoli, Stefano Galvan, and Ferdinando Rodriguez y Baena. Path replanning for orientation-constrained needle steering. IEEE Transactions on Biomedical Engineering, 68(5):1459-1466, 2021.
- [Pivtoraiko et al., 2009] Mihail Pivtoraiko, Ross A Knepper, and Alonzo Kelly. Differentially constrained mobile robot motion planning in state lattices. J. of Field Robotics, 26(3):308-333, 2009.
- [Reed et al., 2011] Kyle B. Reed, Ann Majewicz, Vinutha Kallem, Ron Alterovitz, Kenneth Y. Goldberg, Noah J. Cowan, and Allison M. Okamura. Robot-assisted needle steering. IEEE Robotics Autom. Mag., 18(4):35-46, 2011.
- [Robin and Lacroix, 2016] Cyril Robin and Simon Lacroix. Multi-robot target detection and tracking: taxonomy and survey. Autonomous Robots, 40:729-760, 2016.
- [Salzman et al., 2023] Oren Salzman, Ariel Felner, Carlos Hernandez, Han Zhang, Shao-Hung Chan, and Sven Koenig. Heuristic-search approaches for the multi- objective shortest-path problem: Progress and research op- portunities. In IJCAI, 2023.
- [Salzman, 2019] Oren Salzman. Sampling-based robot mo- tion planning. Commun. ACM, 62(10):54-63, 2019.
- [Shimamoto et al., 2019] Shoichi Shimamoto, Chengyuan Wu, and Michael R. Sperling. Laser interstitial thermal therapy in drug-resistant epilepsy. Current Opinion in Neurology, 32(2):237-245, April 2019.
- [Solovey, 2020] Kiril Solovey. Complexity of planning. arXiv preprint arXiv:2003.03632v2 [cs.RO], 2020.
- [Torres et al., 2015] L. Torres, A. Kuntz, H. Gilbert, P. Swaney, R. Hendrick, R. J. Webster III, and R. Al- terovitz. A motion planning approach to automatic obsta- cle avoidance during concentric tube robot teleoperation. In ICRA, pages 2361-2367, 2015.
- [Tsao et al., 2020] Matthew Tsao, Kiril Solovey, and Marco Pavone. Sample complexity of probabilistic roadmaps via ϵ-nets. In ICRA, pages 2196-2202. IEEE, 2020.
- [Vogelbaum and Aghi, 2015] Michael A. Vogelbaum and Manish K. Aghi. Convection-enhanced delivery for the treatment of glioblastoma. Neuro-Oncology, 17 Suppl 2:ii3-ii8, March 2015.
- [Voges et al., 2018] J. Voges, L. Büntjen, and F. C. Schmitt. Radiofrequency-thermoablation: General principle, his- torical overview and modern applications for epilepsy. Epilepsy Research, 142:113-116, May 2018.
- [Xu et al., 2008] Jijie Xu, Vincent Duindam, Ron Alterovitz, and Ken Goldberg. Motion planning for steerable needles in 3D environments with obstacles using rapidly-exploring random trees and backchaining. pages 41-46. IEEE, 2008.
- [Zhang et al., 2019] Rui Zhang, Shuicai Wu, Weiwei Wu, Hongjian Gao, and Zhuhuang Zhou. Computer-assisted needle trajectory planning and mathematical modeling for liver tumor thermal ablation: A review. Mathematical Bio- sciences and Engineering, 16(5):4846-4872, 2019.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Continuum robots are biologically inspired systems composed of flexible, elastic, or soft materials that allow for complex bending motions. Examples include steerable needles (needles that have the ability to change their direction while inside tissue) [Reed et al., 2011; Alterovitz et al., 2003], and concentric tube robots (robotic systems consisting of multiple flexible tubes of different lengths and curvatures arranged concentrically that are controlled by actuating the relative movements of the tubes) [Gilbert et al., 2013]. Their ability to follow 3D curvilinear trajectories make them excellent candidates for medical applications that require reaching clinically significant targets while safely avoiding critical anatomical structures [Alterovitz and Goldberg, 2008; Burgner-Kahrs et al., 2015]. In contrast to conventional rigid medical instruments, medical continuum robots can minimize a patient's discomfort and enhance safety, providing minimally invasive access to previously unreachable targets. They have shown potential for various diagnostic and treatment procedures such as biopsy, drug delivery, and radioactive seed implantation for cancer therapy [Abolhassani et al., 2007].
Manual control of such devices is highly unintuitive for human operators because of kinematic constraints on their 3D
motion and the fact that the anatomical environment is highly cluttered. Therefore, automation is crucial to fully exploit their capabilities. Indeed, many planners have been proposed for different tasks and different continuum robots. However for the automation of such medical procedures to be clinically accepted, it is critical from a patient care, safety, and regulatory perspective to certify the correctness and effectiveness of the planning algorithms involved in procedure automation, a guarantee that is typically lacking from existing planners. To this end, in this paper, I survey recent and ongoing work where we develop efficient and effective planning capabilities for medical robots that provide provable guarantees on various planner attributes as well as introduce new and exciting research opportunities in the field.
2 Motion Planning for Steerable Needles
Steerable needles can be used to reach clinical targets for biopsy purposes while safely avoiding obstacles such as blood vessels. This clinical application can be modelled as a motion-planning problem which is the problem of determining a collision-free path or trajectory for a robot to move from its initial position to a desired goal position while avoiding obstacles in its environment. Ideally, a motion-planning algorithm should first guarantee that it will compute a solution, when one exists, in finite time, or notify the user that no solution exists. Moreover, the computed solution should strive to maximize some objective which in our setting is patient safety. This can be quantified using metrics such as minimizing trajectory length [Favaro et al., 2018], maximizing clearance from obstacles [Kuntz et al., 2015], and minimizing damage to sensitive tissue [Fu et al., 2018; Bentley et al., 2021].
Thus, a motion planner should be complete, i.e., find a solution plan in a finite number of steps, if one exists, and ideally should be optimal, i.e., ensure that the returned plan has a cost (for a given cost metric) that equals the global optimum. Unfortunately, no previously developed planner for steerable needles (see, e.g., [Xu et al., 2008; Patil et al., 2014; Pinzi et al., 2021]) offers a formal guarantee on completeness, let alone optimality.
Some prior motion planners for steerable needles do aim to optimize motion plan cost but they lack global optimality guarantees [Liu et al., 2016; Favaro et al., 2018; Pinzi et al., 2019; Favaro et al., 2021]. Indeed, providing completeness and optimality guarantees for a steerable needle motion planner is challenging in part because motion planning for steerable needles in 3D with curvature constraints is at least NP-hard [Solovey, 2020]. Some sampling-based planners are known to be both complete and optimal, albeit those properties are usually proven only for an asymptotic regime where the number of samples tends to infinity [LaValle, 2006; Salzman, 2019; Kleinbort et al., 2020]. Interestingly, recent work has developed optimality guarantees for finite sampling, although those results cannot be currently applied to steerable needles as they deal with holonomic systems [Tsao et al., 2020; Dayan et al., 2021].
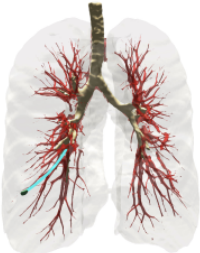
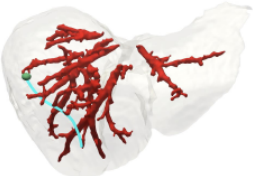
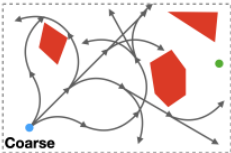
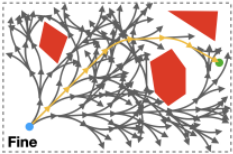
The aforementioned challenges inspired us to consider variants of completeness or optimality relevant to medical applications. Specifically, in a series of recent papers [Fu et al., 2021b; Fu et al., 2022], we focus on specific types of guarantees relevant to real-world medical applications: resolution completeness [LaValle, 2006] and resolution optimality [Barraquand and Latombe, 1993; Pivtoraiko et al., 2009]. Generally speaking, a resolution characterizes the discretization of some space (e.g., state space, configuration space, action space, and time). An algorithm is resolution complete if there exists a fine-enough resolution with which the algorithm finds a plan in finite time when a qualified solution exists, and otherwise correctly returns that no such plan exists. An algorithm is resolution optimal if it is resolution complete and if, when it does return a motion plan, the plan's cost is guaranteed to be within a desired approximation factor of the cost of a globally optimal qualified motion plan. We illustrate at the bottom of Fig. 1 an example showing searches with different resolutions for needle steering.
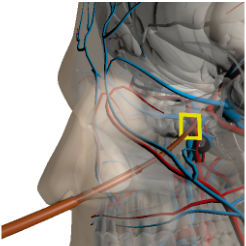
We first presented Resolution-Complete Search (RCS), an efficient, resolution-complete motion planner for steerable needles based on a novel adaptation of multi-resolution planning [Fu et al., 2021b]. Under some mild assumptions on the system and the solution, the planner, in finite time, is guaranteed to find a plan as long as the problem admits a qualified solution. We then extended RCS to develop RCS*, that achieves resolution optimality [Fu et al., 2022].
We demonstrated the performance of our planners in two clinically realistic scenarios where the needle should reach a target while safely avoiding obstacles (e.g., blood vessels). In the setting of (i) lung biopsy, where the needle is deployed through a bronchoscope and must steer through the lung parenchyma (the tissue of the lung outside the bronchial tubes) and in the setting of (ii) liver biopsy, where the needle is deployed into the liver through its anterior surface and must steer through the liver tissue. We compared in simulation our planner with several other steerable needle planners and demonstrated experimentally that RCS and RCS* outperform the state-of-the-art in terms of computation time, success rate, and plan quality.
3 Path Following for Concentric Tube Robots
The dexterity and small diameter of Concentric tube robots, or CTRs [Gilbert et al., 2013] enable minimally-invasive surgery in constrained areas, such as accessing the pituitary gland via the sinuses. For example, they can be used to cut away a window of tissue during a procedure where the tissue to be cut is expected to be provided by a surgeon as a path that the CTR's end effector should trace or follow. This can be modelled as a path-following problem where we are given an entire path R for the robot's tip and are tasked with computing a robot plan such that when following this plan, it's end effector traces R "as closely as possible" (this is formally defined by Holladay et al. [2019]).
Although existing planners [Torres et al., 2015] enable CTRs to reach specified points in task-space (space of a robot's end-effector positions), this is often insufficientexisting path-following algorithms [Berenson et al., 2009;
Holladay et al., 2019] have difficulty planning robustly in the cluttered environments that arise in our medical domains (e.g., cutting a window in the skull during brain surgery as depicted in Fig. 2). To this end, we introduce the NNF (NearestNeighbor Fr´echet) motion planner-the first planner in this domain able to compute a trajectory that closely follows such a task-space path [Niyaz et al., 2018].
However, our key insight is that truly performing our task optimally requires not only robust planning but also optimizing the robot placement (namely, where the fixed based of the robot is placed prior to the surgery). This is a critical choice in a highly-constrained environment, given that certain placements will allow the robot a greater range of motion within the already-limited space, and thus better enable it to follow the path with its end-effector.
Our final approach [Niyaz et al., 2019] therefore uses the output of the NNF planner to inform a gradient-free optimizer over the robot's placement, and thus simultaneously plans both the motions to execute and the placement to execute them from. In order to make this approach as efficient as possible, we also enable tight integration between the motion planner and optimizer to bound unnecessary computation. Our experiments confirm both that (i) incorporating the choice of placement dramatically improves the ability to follow a given path and (ii) tightly integrating the planner and optimizer in this way affords our approach a significant reduction in compute time.
4 Inspection Planning for CRISP Robot
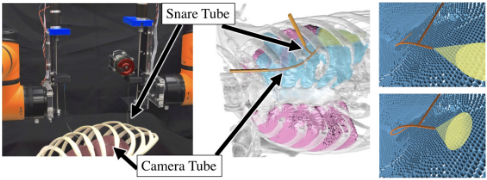
In certain medical applications, physicians may want to inspect some region of interest for diagnostic purposes completing the procedure as fast as is safely possible to reduce costs and improve patient outcomes, especially if the patient is under anesthesia during the procedure. For example, the needle-diameter Continuum Reconfigurable Incisionless Surgical Parallel (CRISP) robot [Anderson et al., 2017; Mahoney et al., 2016] was suggested to assist in the diagnosis of the cause of a pleural effusion (a serious medical condition that can cause the collapse of a patient's lung) by visually inspecting the surface of the collapsed lung and chest wall inside the body (see Fig. 3) [Kuntz et al., 2018]. This can modelled as an inspection-planning problem [Almadhoun et al., 2016; Galceran and Carreras, 2013] where we are given a robot equipped with a sensor and a set of points of interest (POI) in the environment to be inspected by the sensor. The problem calls for computing a minimal-length motion plan for the robot that maximizes the number of POI inspected.
Na¨ıvely computed inspection plans may enable inspection of only a subset of the POI and may require motion plans significantly longer than an optimal plan, and hence may be undesirable or infeasible due to time constraints. Our goal is to compute kinematically feasible collision-free inspection plans that maximize the number of POI inspected, and of the plans that inspect those POI we compute a shortest one.
Inspection planning is computationally challenging because we need to simultaneously reason both about motion planning in a high-dimensional configuration space X (the space of all parameters that determine the shape of the robot) [LaValle, 2006] as well as about maximizing the number of POI inspected.
There are multiple approaches to computing inspection plans. Optimization-based methods locally search over the space of all inspection plans [Bircher et al., 2015; Bogaerts et al., 2018]. Decoupled approaches first independently select suitable viewpoints and then determine a visiting sequence, i.e., a motion plan for the robot that realizes this sequence [Englot and Hover, 2011]. Finally, recent progress in motion planning [Karaman and Frazzoli, 2011] has enabled methods to exhaustively search over the space of all motion plans [Bircher et al., 2017; Kafka et al., 2016] thus guaranteeing asymptotic optimality. Roughly speaking, asymptotic optimality for inspection planning means these methods produce inspection plans whose length and the number of points inspected will asymptotically converge to those of an optimal inspection plan, given enough planning time.
Of all the aforementioned methods, only algorithms in the latter group provide any formal guarantees on the quality of the solution. This guarantee is achieved by attempting to exhaustively compute the set of Pareto-optimal inspection plans embedded in X for which full coverage has not been obtained. Namely, for every configuration x ∈ X, they (asymptotically) compute the set of paths Πx starting from a given start configuration xs such that ∀π1, π2 ∈ Πx, either π1 is shorter than π2 and π2 covers POI not covered by π1 or vice versa. Once Πx contains a path π∗x that covers all POI, this path is considered as a candidate solution. In our setting, the set of Pareto-optimal inspection plans is the minimal set of inspection plans such that each plan is either shorter or has better coverage of the POI than any other inspection plan. 1
1 More formally, an inspection plan P connecting two configurations q, q′ ∈ X is said to be Pareto optimal in our setting if any other plan connecting q to q′ is either longer or does not inspect a point visible to P .
Unfortunately, this comes at the price of very long computation times as the size of the search space is exponential in the number of POI.
To this end, we introduce Incremental Random Inspection-roadmap Search (IRIS), an asymptotically optimal inspection-planning algorithm [Fu et al., 2019; Fu et al., 2021a]. IRIS incrementally constructs a sequence of increasingly dense roadmaps-graphs embedded in X wherein each vertex represents a collision-free configuration and each edge a collision-free transition between configurations-and computes an inspection plan on the roadmaps as they are constructed.
Unfortunately, even the problem of computing an optimal inspection plan on a graph (and not in the configuration space) is computationally hard. To this end, our key insight is to compute a near-optimal inspection plan on each roadmap. Namely, we compute an inspection plan that is at most 1 + ε the length of an optimal plan while covering at least p-percent of the number of POI (for any ε ≥ 0 and p ∈ (0, 1]). This additional flexibility allows us to improve the quality of our inspection plan in an anytime manner, i.e., the algorithm can be stopped at any time and return the best inspection plan found up until that point. We achieve this by incrementally densifying the roadmap and then searching over the densified roadmap for a near-optimal inspection plan-a process that is repeated as time allows. By reducing the approximation factor between iterations, we ensure that our method is asymptotically optimal.
The key contribution of this work is a computationally efficient algorithm to compute provably near-optimal inspection plans on graphs. Coupled with our method for generating this graph, this algorithmic building block enables us to dramatically outperform Rapidly-exploring Random Tree Of Trees (RRTOT) [Bircher et al., 2017]-a state-of-the-art asymptotically optimal inspection planner. Specifically, we demonstrated the efficacy of our approach in simulation for several complex robotic systems (Fig. 3).
5 Summary and FutureWork
In this paper we reviewed several algorithmic planning problems (motion planning, path following and inspection planning) and demonstrated their applicability and dedicated solutions for minimally invasive robot surgery that come with some guarantees. We continue to briefly introduce new and exciting research opportunities in the field.
Task Inspection Planning In semi-autonomous minimally-invasive robotic surgery we have one robot tele-operated by a surgeon who is tasked with suturing or removing a tumor while a second, fully autonomous robot, is in charge of autonomously providing the surgeon with visual feedback on the progress of the task. This can be modelled as a task inspection planning where we are given two robots: one, which we call the task robot, that is in charge of performing a given task, and the second, which we call the inspection robot, is in charge of inspecting the task as performed by the task robot using on-board sensors.
This problem is not new [Robin and Lacroix, 2016] however it is typically considered in the adversarial setting where the inspection robot is required to avoid being observed by the inspection robot. Our version bares resemblance to the path following and inspection-planning problems we mentioned and we anticipate that the algorithmic building blocks developed for these problems will serve as foundations to solving the task-inspection planning problem. However, a unique challenge we foresee in addressing this problem is robustness-computing a path that is robust to execution uncertainty of both robots while guaranteeing that the task is indeed inspected.
Therapy Planning As steerable medical devices become more capable of taking expressive paths, they unlock the door for therapy delivery in ways not previously possible. This may include drug-based therapies such as gene therapy compounds [Lonser et al., 2020] and cellucidal compounds [Vogelbaum and Aghi, 2015], or energy-based therapy such as laser/radiofrequency ablation [Ashraf et al., 2018; Shimamoto et al., 2019; Voges et al., 2018]. Automating the planning of such therapy for straight-line paths of medical devices is itself a challenging problem [Zhang et al., 2019], and considering non-straight paths only adds complexity.
We believe that these are fundamentally coupled problems: Planning how to deliver therapy (e.g., pose and volume of liquid drug delivery, or pose, intensity, and duration of energy delivery) and planning how the steerable device moves to those locations must be considered in concert. We deem this problem the therapy planning problem.
Preliminary, we are abstracting the therapy planning problem as a multi-criteria optimization problem in which we must simultaneously consider objectives that incorporate the delivery of therapy to the intended tissue, the delivery of therapy to unintended tissue, some cost associated with moving the robot to the therapy delivery poses, and potentially other medical objectives (e.g., total time under anesthesia, etc.).
This is an extremely complex problem. Modeling the therapy involves potentially non-uniform dispersion of drug or diffusion of energy [Knavel and Brace, 2013]. Modeling the motion of the robot itself is complex for the reasons listed above, and multi-criteria optimization is inherently complex itself as well (see, e.g., [Salzman et al., 2023]).
Acknowledgements
This research was supported by the United States-Israel Binational Science Foundation (BSF) grants no. 2019703 and 2021643 and by the Israeli Ministry of Science & Technology grants No. 3-16079 and 3-17385. I am greatly indebted to all my coauthors. Specifically, this research was and is carried out in collaboration with Ron Alterovitz, Mengyu Fu, Alan Kuntz, Michael Bentley, Caleb Rucker, Chakravarthy Reddy Siddhartha Srinivasa, Sherdil Niyaz, and Kiril Solovey.
@inproceedings{ijcai2023p804,
  title     = {Algorithmic Motion Planning Meets Minimially-Invasive Robotic Surgery},
  author    = {Salzman, Oren},
  booktitle = {Proceedings of the Thirty-Second International Joint Conference on
               Artificial Intelligence, {IJCAI-23}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Edith Elkind},
  pages     = {7039--7044},
  year      = {2023},
  month     = {8},
  note      = {Early Career},
  doi       = {10.24963/ijcai.2023/804},
  url       = {https://doi.org/10.24963/ijcai.2023/804},
}
TY - CPAPER TI - Algorithmic Motion Planning Meets Minimially-Invasive Robotic Surgery AU - Salzman, Oren T2 - Proceedings of the Thirty-Second International Joint Conference on Artificial Intelligence, IJCAI-23 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2023 SP - 7039 EP - 7044 DO - 10.24963/ijcai.2023/804 UR - https://doi.org/10.24963/ijcai.2023/804 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





